I’ve not been on the radio much over the last few weeks as I’ve had my head down other radio related rabbit holes.
One of the rabbit holes is a Node-Red project to make my online logs a little more interactive. For sometime now my logs have been displayed on my website as nicely formatted, searchable HTML pages however, they don’t really allow the viewer (myself included) to see the global coverage of all the contacts so, I decided to write a Node-Red flow that would do just that.
M0AWS Interactive Log Flow
The flow itself isn’t too complicated and basically consists of reading in the individual ADIF formatted log files, processing the data and then sending the data in the correct format to the map node for display.
I’ve had to write a few functions to handle the processing of the ADIF formatted data but, these aren’t particularly complex and are fairly easy to understand even if like me, you’re not a Javascript programmer.
The flow is working perfectly however, I’m in the process of reworking the format generic payload function to reduce the amount of code and make it more efficient.
M0AWS SSB / CW / FreeDV Interactive Log World Map
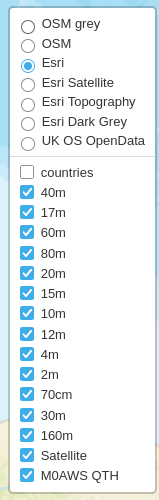
M0AWS Interactive Log Map Layers Menu
The flow generates two maps, one for voice / CW /Satellite contacts and the other for WSJT-X FT4/8 contacts. Every pin on the map is colour coded by band with satellite contacts being denoted by a satellite icon.
Each pin / icon on the map is clickable and reveals the data of the QSO being displayed.
In the top right-hand corner of the map there is a drop down layermenu that allows the viewer to filter by band thus reducing the number of icons on the screen at any one time.
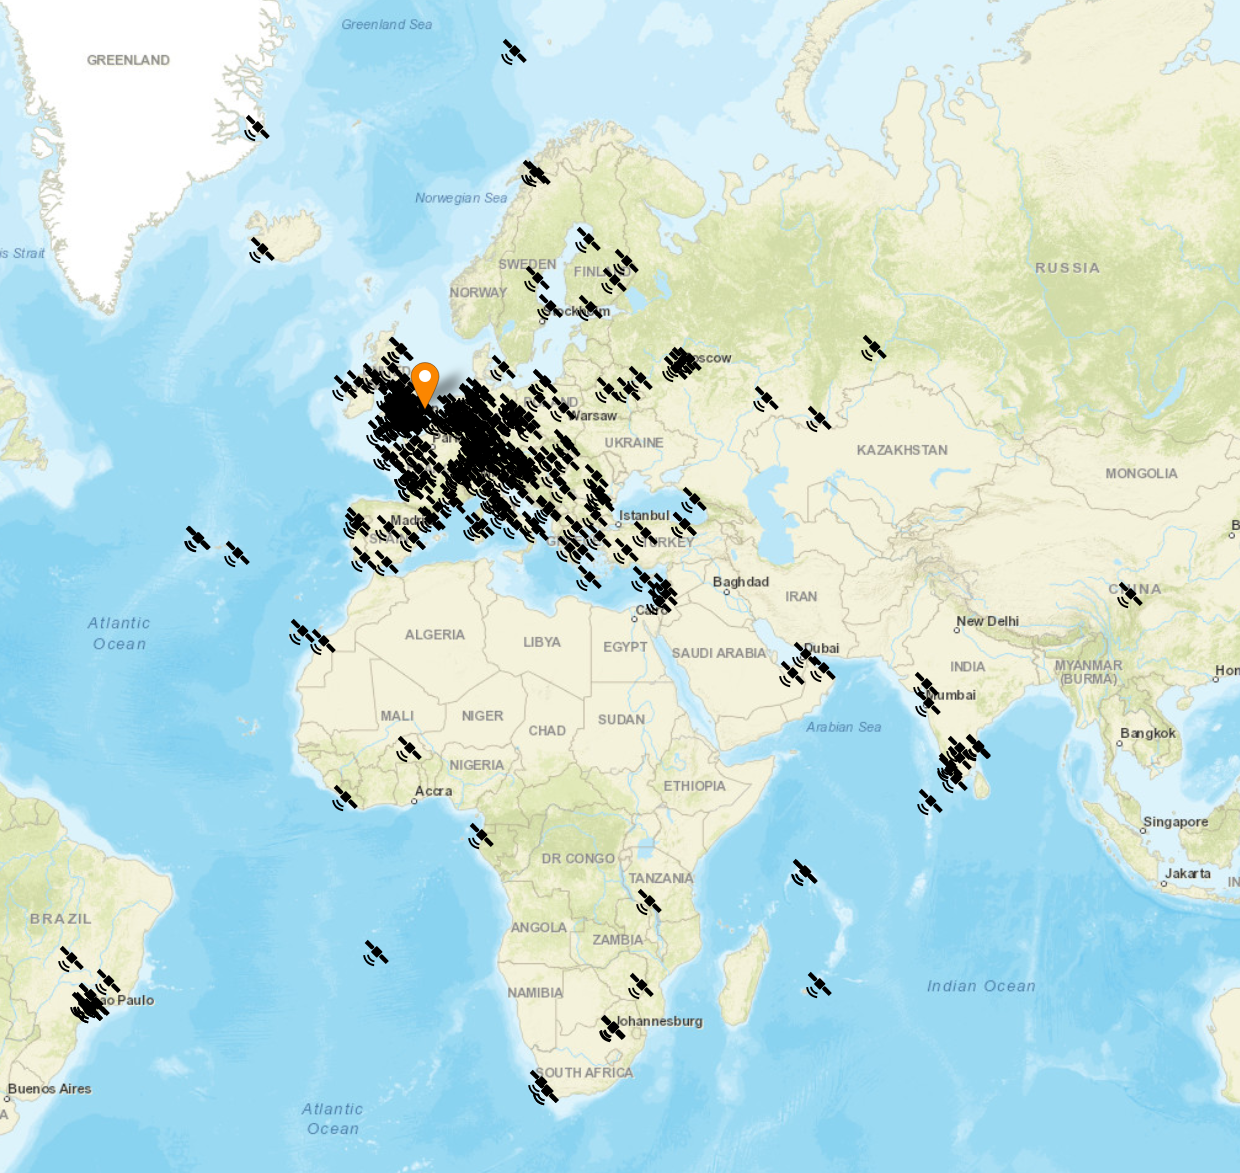
Seeing the data presented on a map really brings my logs alive. An example of this is that I had no idea I’d worked so many stations in India on the QO-100 Satellite.
The small icons in the pins show a microphone for SSB/FM/FreeDV contacts and a downwards pointing triangle in a box for CW contacts. Sadly I couldn’t find a Morse key icon in the collection available.
M0AWS filtered view of QO-100 Satellite contacts
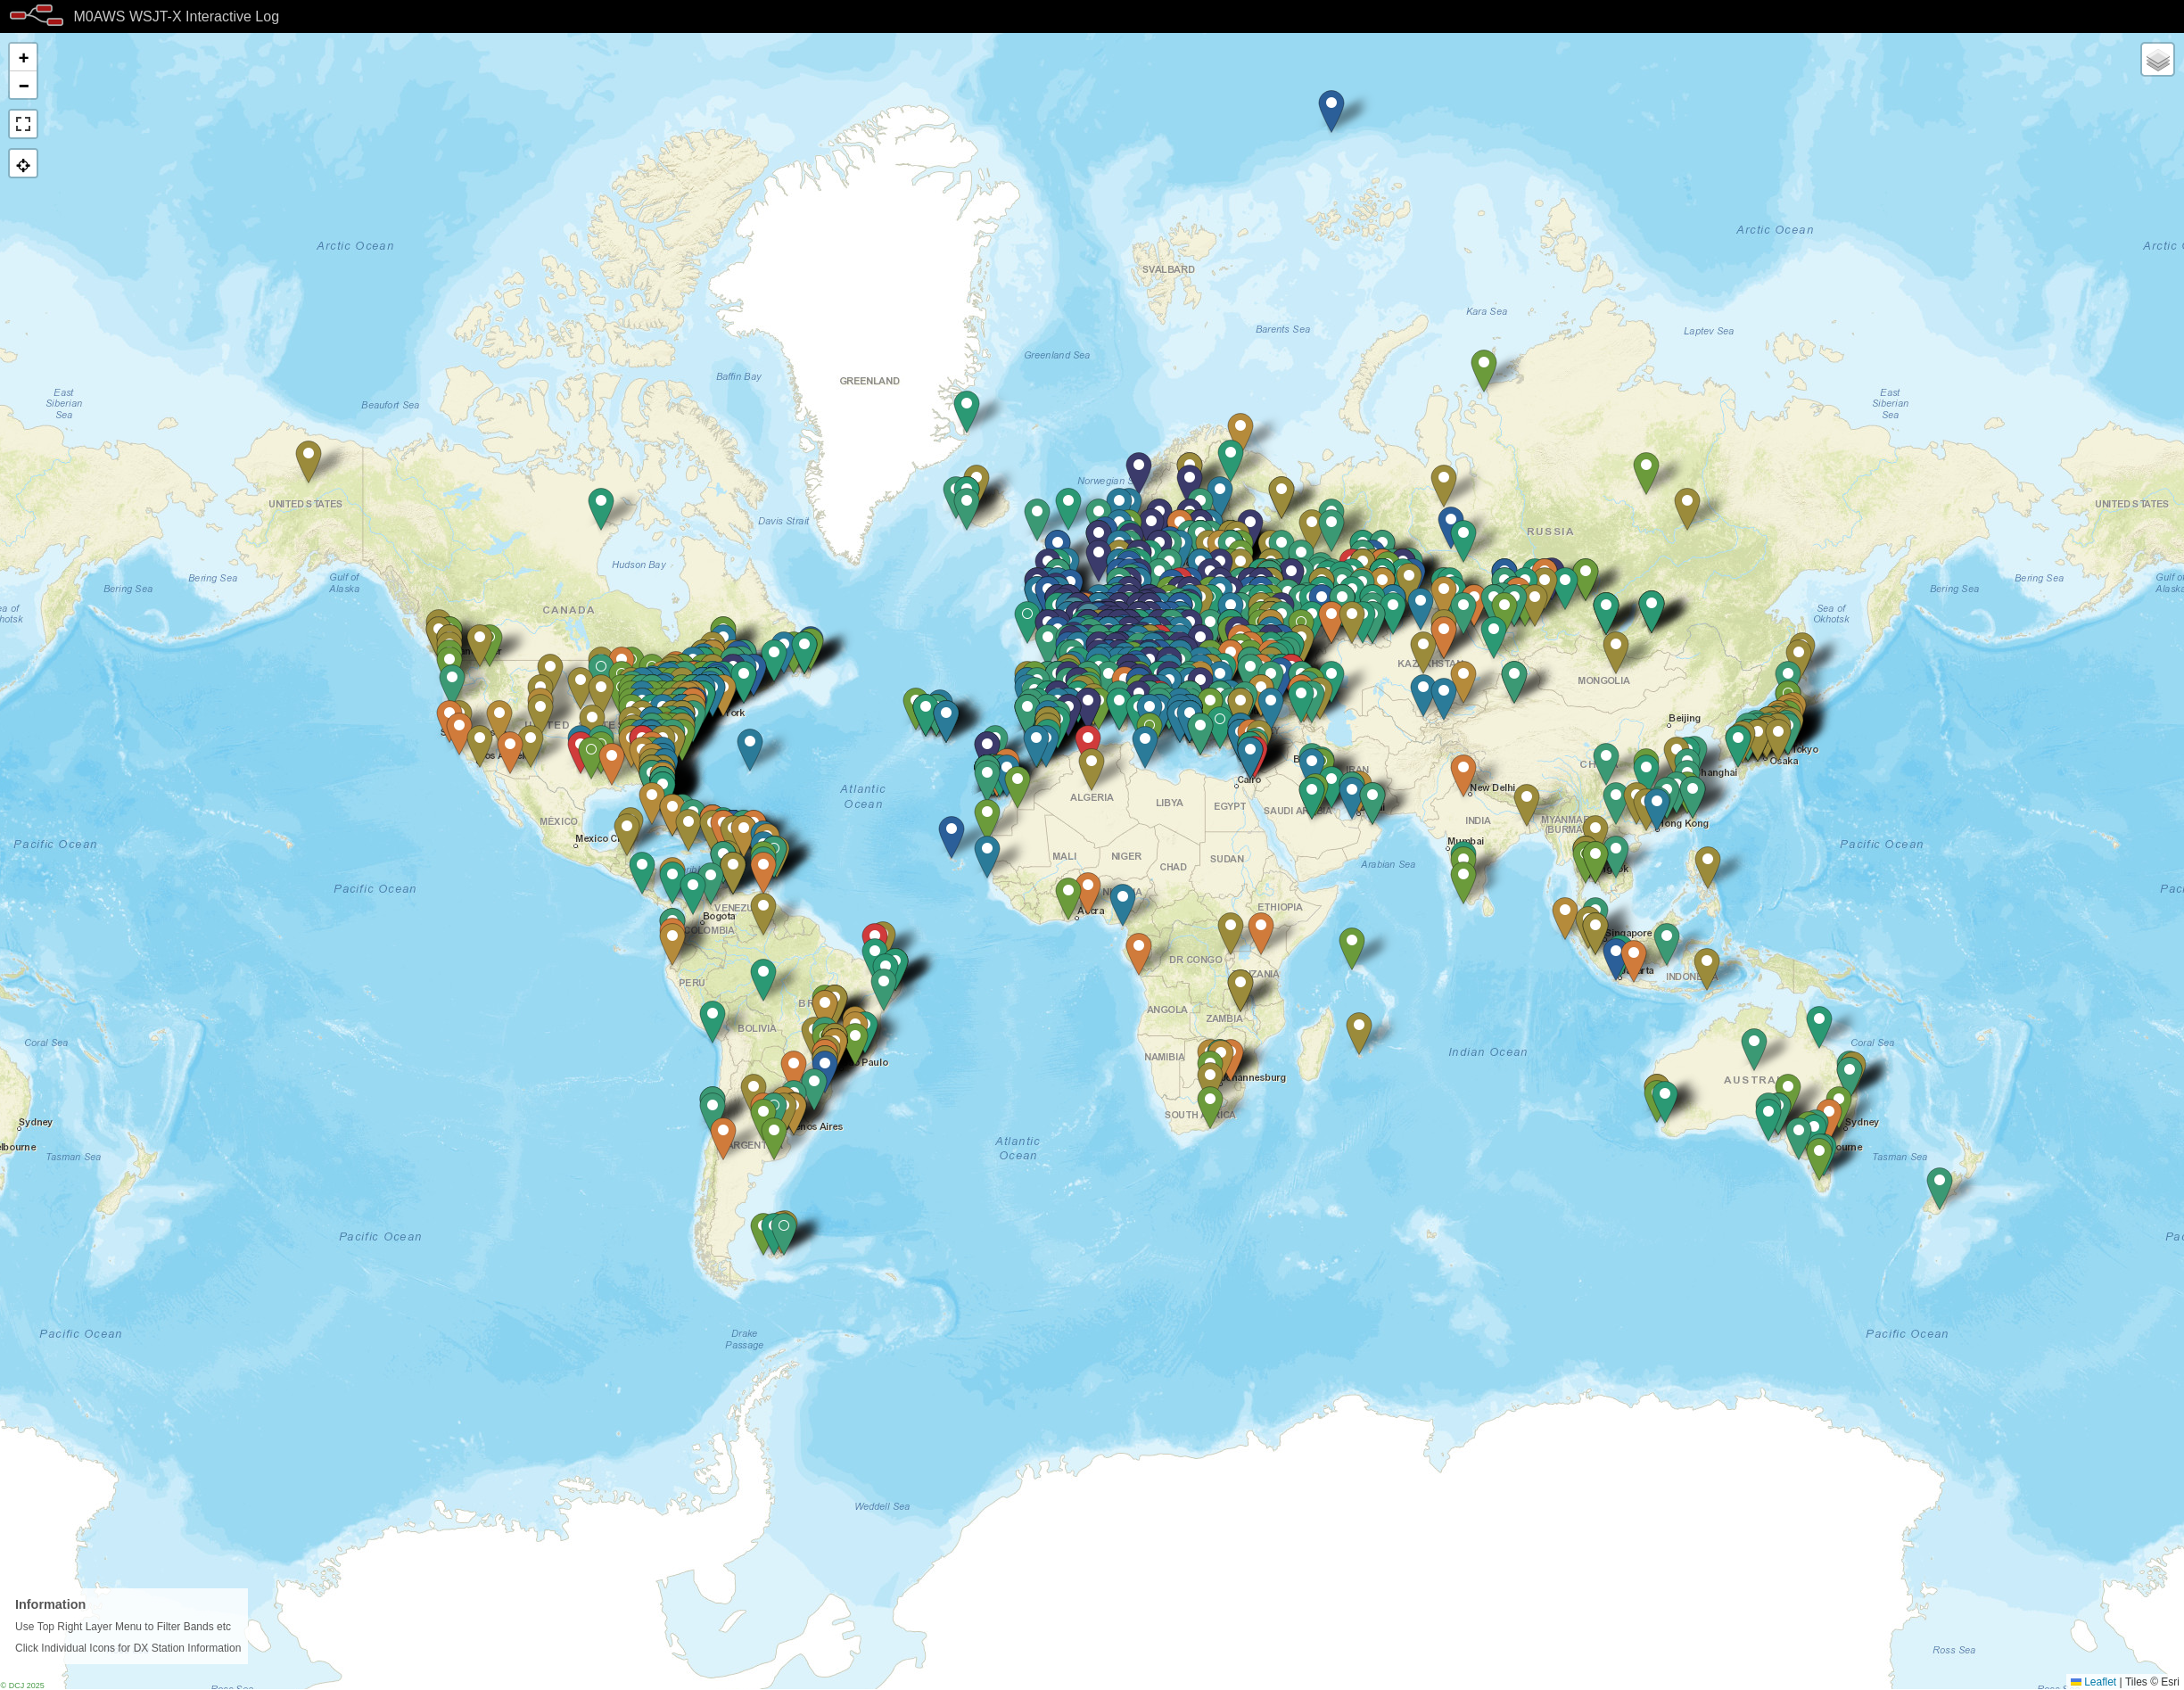
I only use FT4/8 for testing new antenna designs however, it’s interesting to see the global coverage accomplished with this weak signal mode.
M0AWS WSJT-X FT4/8 Interactive Log World Map
Once I’ve finished rewriting the format generic payload function I will make the flow available for download here so that others can also create an interactive view of their radio logs.
If you want to have a look at the maps and try them out for yourself, they are available under the Logs menu above.
This Node-Red instance is running in a virtual machine (VM) on a 16GB RAM RaspberryPi 5 that is also running a number of other VMs at the same time so, it’s safe to say it’s not heavy on CPU and will run on the older Pi4 as well.
RaspberryPi computers are now moving into the realm of being powerful enough to replace the traditional desktop PC. My most recent purchase, a RaspberryPi 500+ is proof of this as it has been my daily desktop PC since it’s arrival.
One of the things I use heavily are virtual machines. They’re great for developing, prototyping and running new services. With the ability to snapshot, rollback and backup in an instant, virtualisation helps to reduce the development and test time for many of the programs and services that I’m playing with.
With RaspberryPi computers now supporting 16GB of RAM and M.2 SSD drives there is no reason for not taking advantage of virtualisation.
To this end I decided to test running some virtualised loads on my new 500+ with the plan to deploy to 16GB Pi5’s with SSD drives in place of more expensive Intel based computers.
On my Intel based machines I use QEMU, KVM and Virt-Manager to manage the multitude of virtual machines (VMs) I have running here. Since this is a solid, high performance platform for running VMs I decided to take the same route on the 500+
Installing the necessary packages is extremely simple, just one simple apt command:
# Main ethernet
# Setup Bridge called br1 on eth0
allow-hotplug eth0
iface eth0 inet manual
auto br1
iface br1 inet static
address 192.168.0.100
network 192.168.0.0
netmask 255.255.255.0
broadcast 192.168.0.255
gateway 192.168.0.1
dns-nameservers 192.168.0.5
bridge_ports eth0
bridge_stp off
#
#
Once this is done reboot your RaspberryPi and check you have access to your local LAN and of course the internet. You will now also inherit the two new groups that you added yourself to above.
Note: If you are using NetworkManager open the network settings app and create a bridge on eth0. You can also use the nmtui copmmandline app if you prefer.
At this point you’re ready to create your first virtual machine.
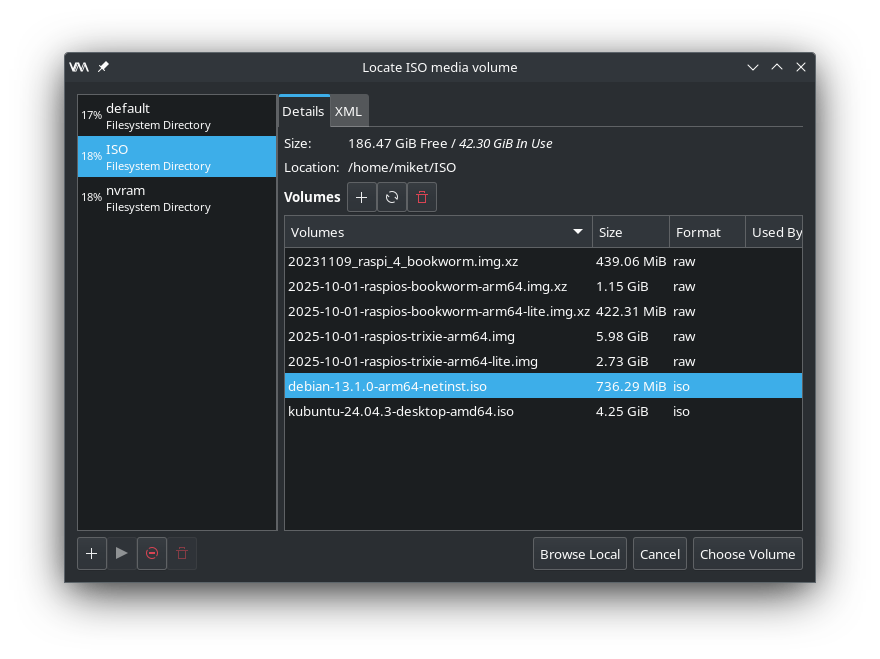
It’s important to have an arm64 version of Linux in ISO format that you can use to install into your VM. My preferred distro is Debian and so I downloaded the Debian 13 Arm64 netinst ISO from the debian.org website.
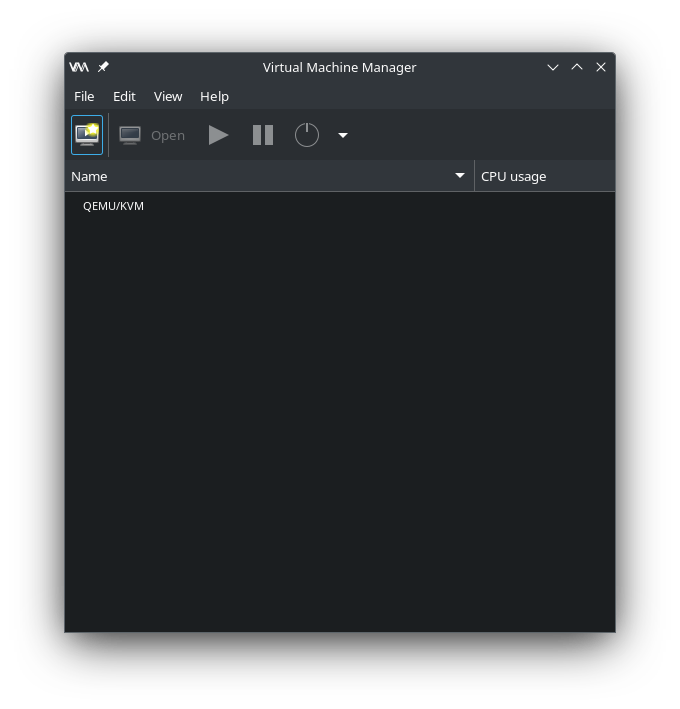
From the main menu start “Virtual machine Manager” or on the commandline type:
virt-manager
QEMU Virtual Machine Manager
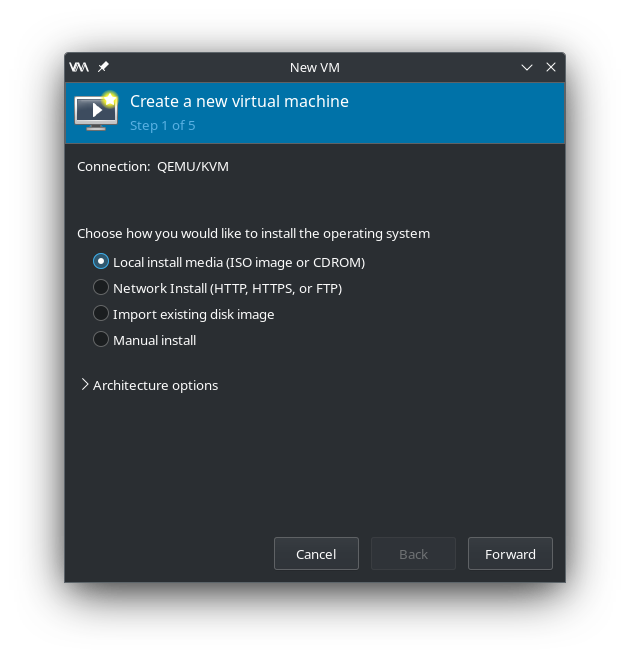
Click the Create new VM button and then navigate to where you saved your ISO file and select it as the installation media.
Virtual Machine Manager – Local install mediaVirtual Machine Manager – Select ISO file
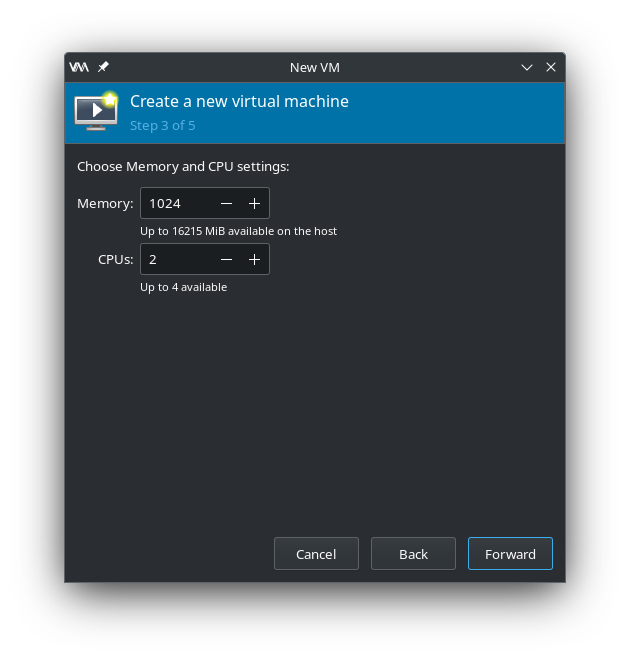
Once you’ve chosen your ISO you’ll need to configure the actual VM. Start by setting the amount of RAM and number of virtual CPUs you want the VM to have.
Virtual Machine Manager – Configure RAM and CPU
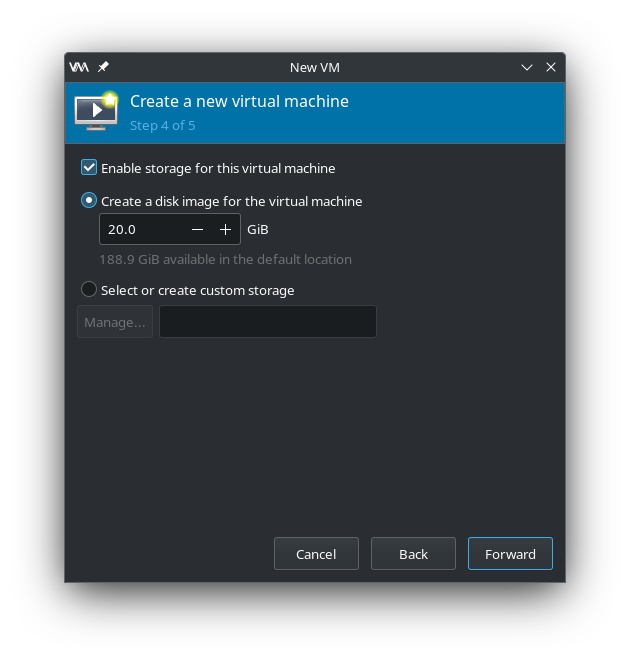
Next set the size of the virtual disk that the VM will use.
Virtual Machine Manager – Create virtual disk
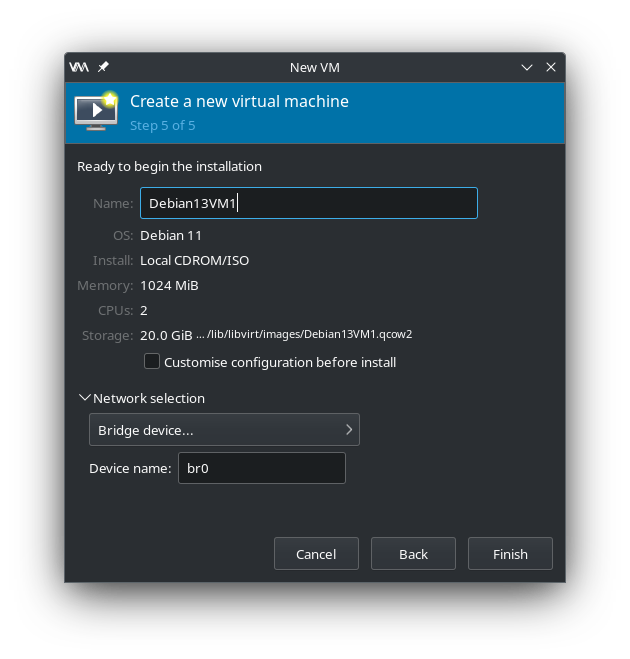
Finally, give the VM a name and set its network device to br0 as created above. Click finish and your VM will boot.
Virtual Machine Manager – Name VM and select bridge interface
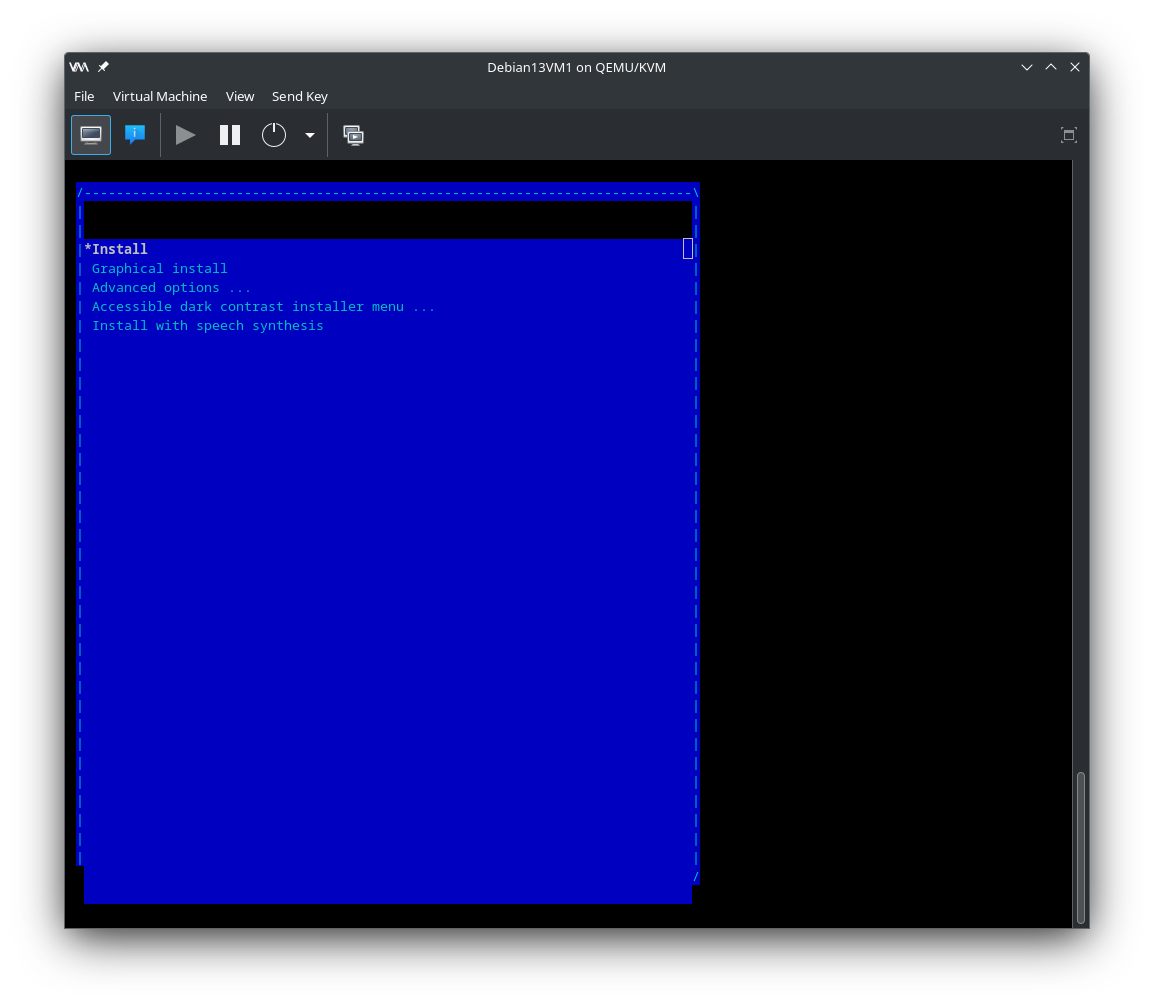
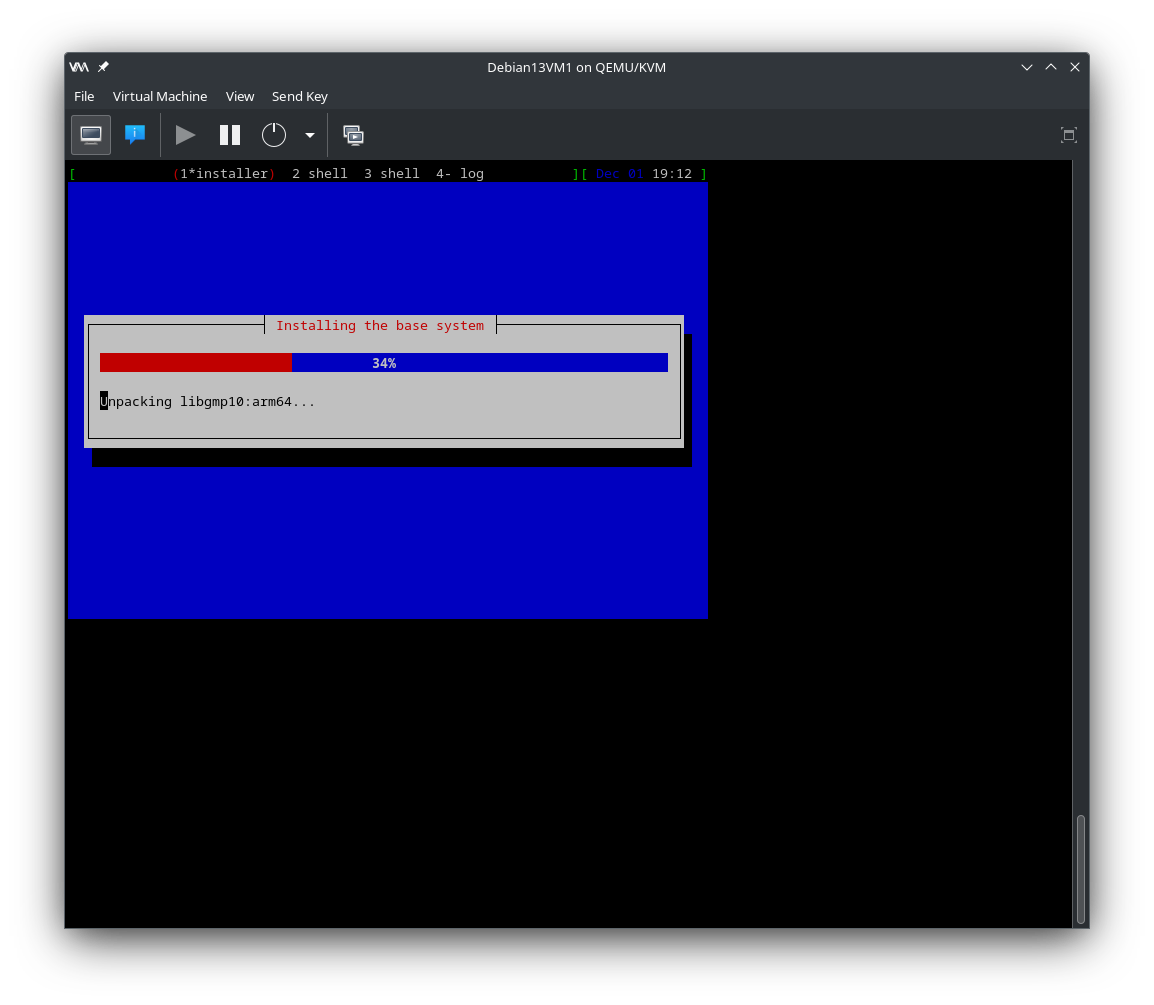
Now it’s just a case of going through the standard Debian install process to build your Debian VM.
Once the installation is complete and the VM has rebooted you will have a functional Debian computer ready to use for whatever you like, just like a physical PC but, in virtual form. You’ll find that the VM runs as fast as the actual physical machine thanks to the kernel based virtualisation.
Since RaspberryPi are now forcing users of its SBC to use RaspberryPi OS 13 (via the RaspberryPi Imager tool) instead of the reliably stable Debian 11 or 12 several issues have come to light.
Firstly if like me you run most of the your Pi4/5 SBCs headless/lights out you’ll notice that networking is now ridiculously managed via Network Manager and Netplan.
This is a ridiculous method of managing such a simple device, it’s over complicated, messy and ill thought out. Yet another classic example of change for the sake of change and not to actually improve things.
This combination of Network Manager (often referred to as Network Mangler for good reason) and Netplan is fraught with bugs. Try setting a second IP address on an interface and you’ll find it doesn’t work. nmtui will show the ip address as being configured however, netplan never actually puts the config into play.
Having to use nmtui on the command line to manage ethernet interfaces is also ridiculous. Its badly laid out menu system takes an age to get through to do the simplest of config changes. What’s wrong with just editing the /etc/network/interfaces file?
After much frustration trying to configure the ethernet interface on my headless Pi5 I decided to get rid of this hideous method of managing ethernet interfaces and put it back to using the simple interfaces file.
I’ve documented the steps just in case anyone else wants to do the same.
Step 1: Make sure the traditional networking stack is installed:
# Example /etc/network/interfaces for Ethernet (eth0) with static IP:
#
# Loopback
auto lo
iface lo inet loopback

# Ethernet
auto eth0
iface eth0 inet static
    address 192.168.1.10
    netmask 255.255.255.0
    gateway 192.168.1.1
    dns-nameservers 1.1.1.1 8.8.8.8
Example for DHCP:
auto eth0
iface eth0 inet dhcp
If you use Wi-Fi:
auto wlan0
iface wlan0 inet dhcp
    wpa-ssid "YourSSID"
    wpa-psk "YourPassword"
Step 5 – Enable the traditional networking service
The /etc/network/interfaces method works perfectly on Pi 5 and is lighter weight and ideal for embedded or headless servers.
If you later reinstall NetworkManager, it will override interfaces again unless you mark them as unmanaged in /etc/NetworkManager/NetworkManager.conf.
You can still use ifup / ifdown commands manually for control.
You now have your Pi running the classic, lightweight networking stack which is ideal if you use your Pi as a 24/7 server like I do.
Note: This method is still supported on RaspberryPi Debian 13 but, it’s no longer the default.
As a final note, if you want to add a second IP Address to your Ethernet interface it’s extremely simple to define in the /etc/network/interfaces file. I’ve created an example of how to do this below for reference.
# Loopback
auto lo
iface lo inet loopback

#
# Primary interface - static IP
#
auto eth0
iface eth0 inet static
    address 192.168.1.10
    netmask 255.255.255.0
    gateway 192.168.1.1
    dns-nameservers 1.1.1.1 8.8.8.8

#
# Secondary IP on same interface
#
auto eth0:1
iface eth0:1 inet static
    address 192.168.1.11
    netmask 255.255.255.0
Check both IP Addresses appear on the same interface:
ip a show eth0
For the example above you’ll see:
inet 192.168.1.10/24
inet 192.168.1.11/24
Finally, if like me you use lm-sensors to keep check on how hot your Pi is running you’ll find that the sensors command no longer works, it just throws a segmentation fault. This is a nuisance as I use this as part of my Node-Red Monitoring Dashboard.
A partial work around is to use the vcgencmd command as it can return the temperature of the system on a chip (SOC) device.
vcgencmd measure_temp
You can create an alias for this command in your ~/.profile file, I’ve named the alias ‘cputemp’ in this example:
alias cputemp="vcgencmd measure_temp"
Once you’ve saved your .profile file logout and back in again and you’ll now have a new command to use to get the CPU temp.
In December 2024 the RaspberryPi 500 was announced with great fanfare in the maker world. Following on from the RaspberryPi 400 series, the 500 model moved the keyboard based 80’s style desktop computer to the new faster CPU and RP1 I/O chip technology that came with the RaspberryPi 5 model.
This was hailed as a big step forward in performance for the 500 series however, for me it was disappointing. The problem with the 500 is that it didn’t come with an M.2 NVME SSD connector and was based around the much slower SD card storage solution.
All of my Pi5 models have been upgraded with the Pimoroni SSD Baseboard and a 250GB M.2 NVME SSD drive making a huge improvement in performance for the little single board computer (SBC).
Along comes the Raspberry Pi 500 and once again it’s hobbled by the fact that it has no SSD support on the motherboard. What was ridiculous was that all the pads and tracks were on the circuit board but, not populated. This annoyed many in the RaspberryPi community, myself included as the new faster machine was once again held back by slow SD card I/O.
What made it even worse was the fact that the 500 didn’t have the facility to add an M.2 NVME SSD via the PCIe interface like on the Pi5, making it even more disappointing.
Needless to say I, along with many others didn’t put my hand in my pocket to purchase a 500 as it would be a huge step backwards from my Pi5’s.
Step forward to September 2025 and RaspberryPi announce the new RaspberryPi 500+, the computer we all hoped for 12 months earlier.
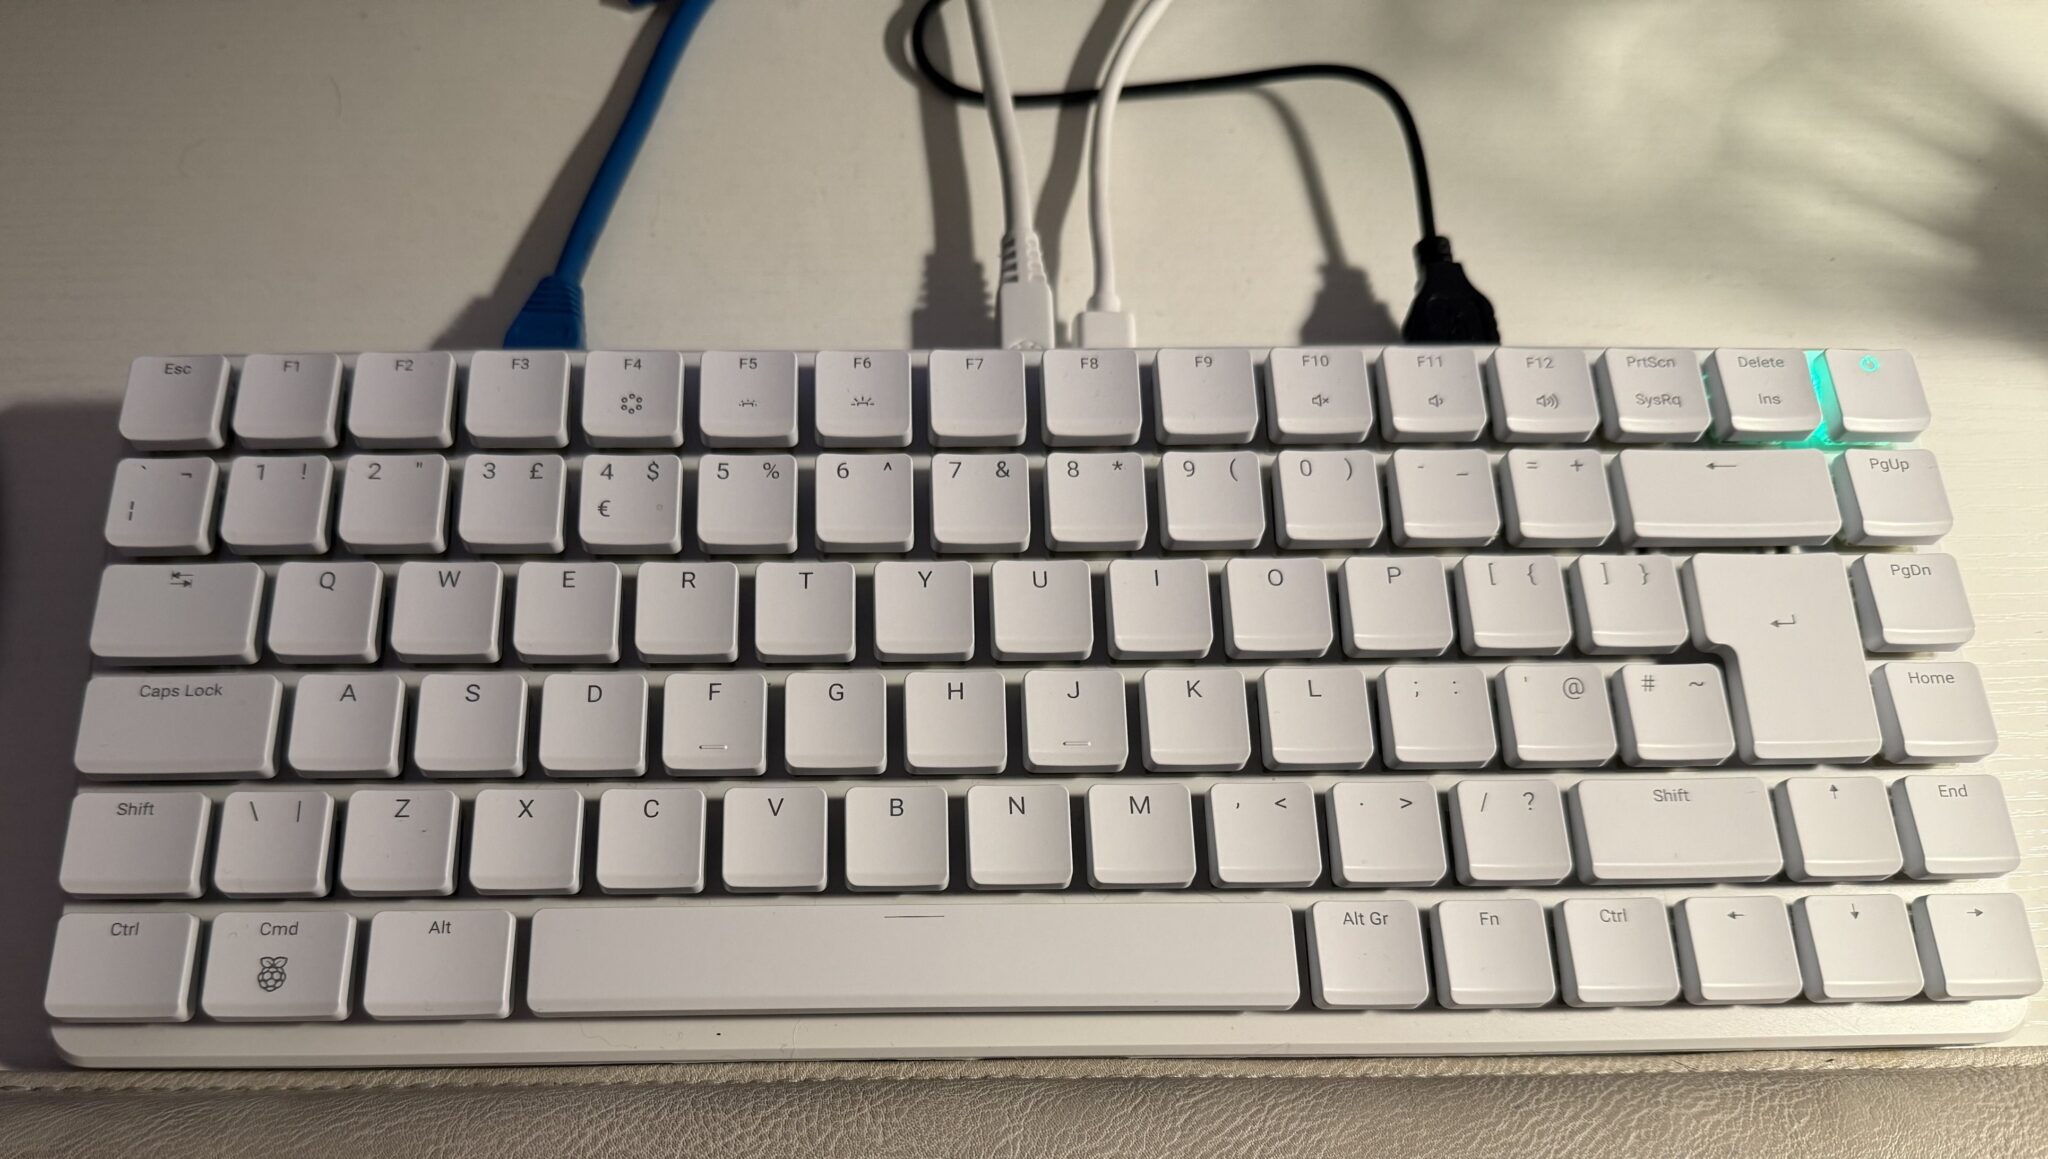
My RaspberryPi 500+ that I’m using to write this article
I ordered my 500+ from Pimoroni the moment the email saying it was available with its new high spec dropped into my inbox. Being one of the first to splash the cash I got a 20% discount off the price too, which made the purchase even easier.
A few days later the 500+ landed on my doorstep and I hastily unpacked it.
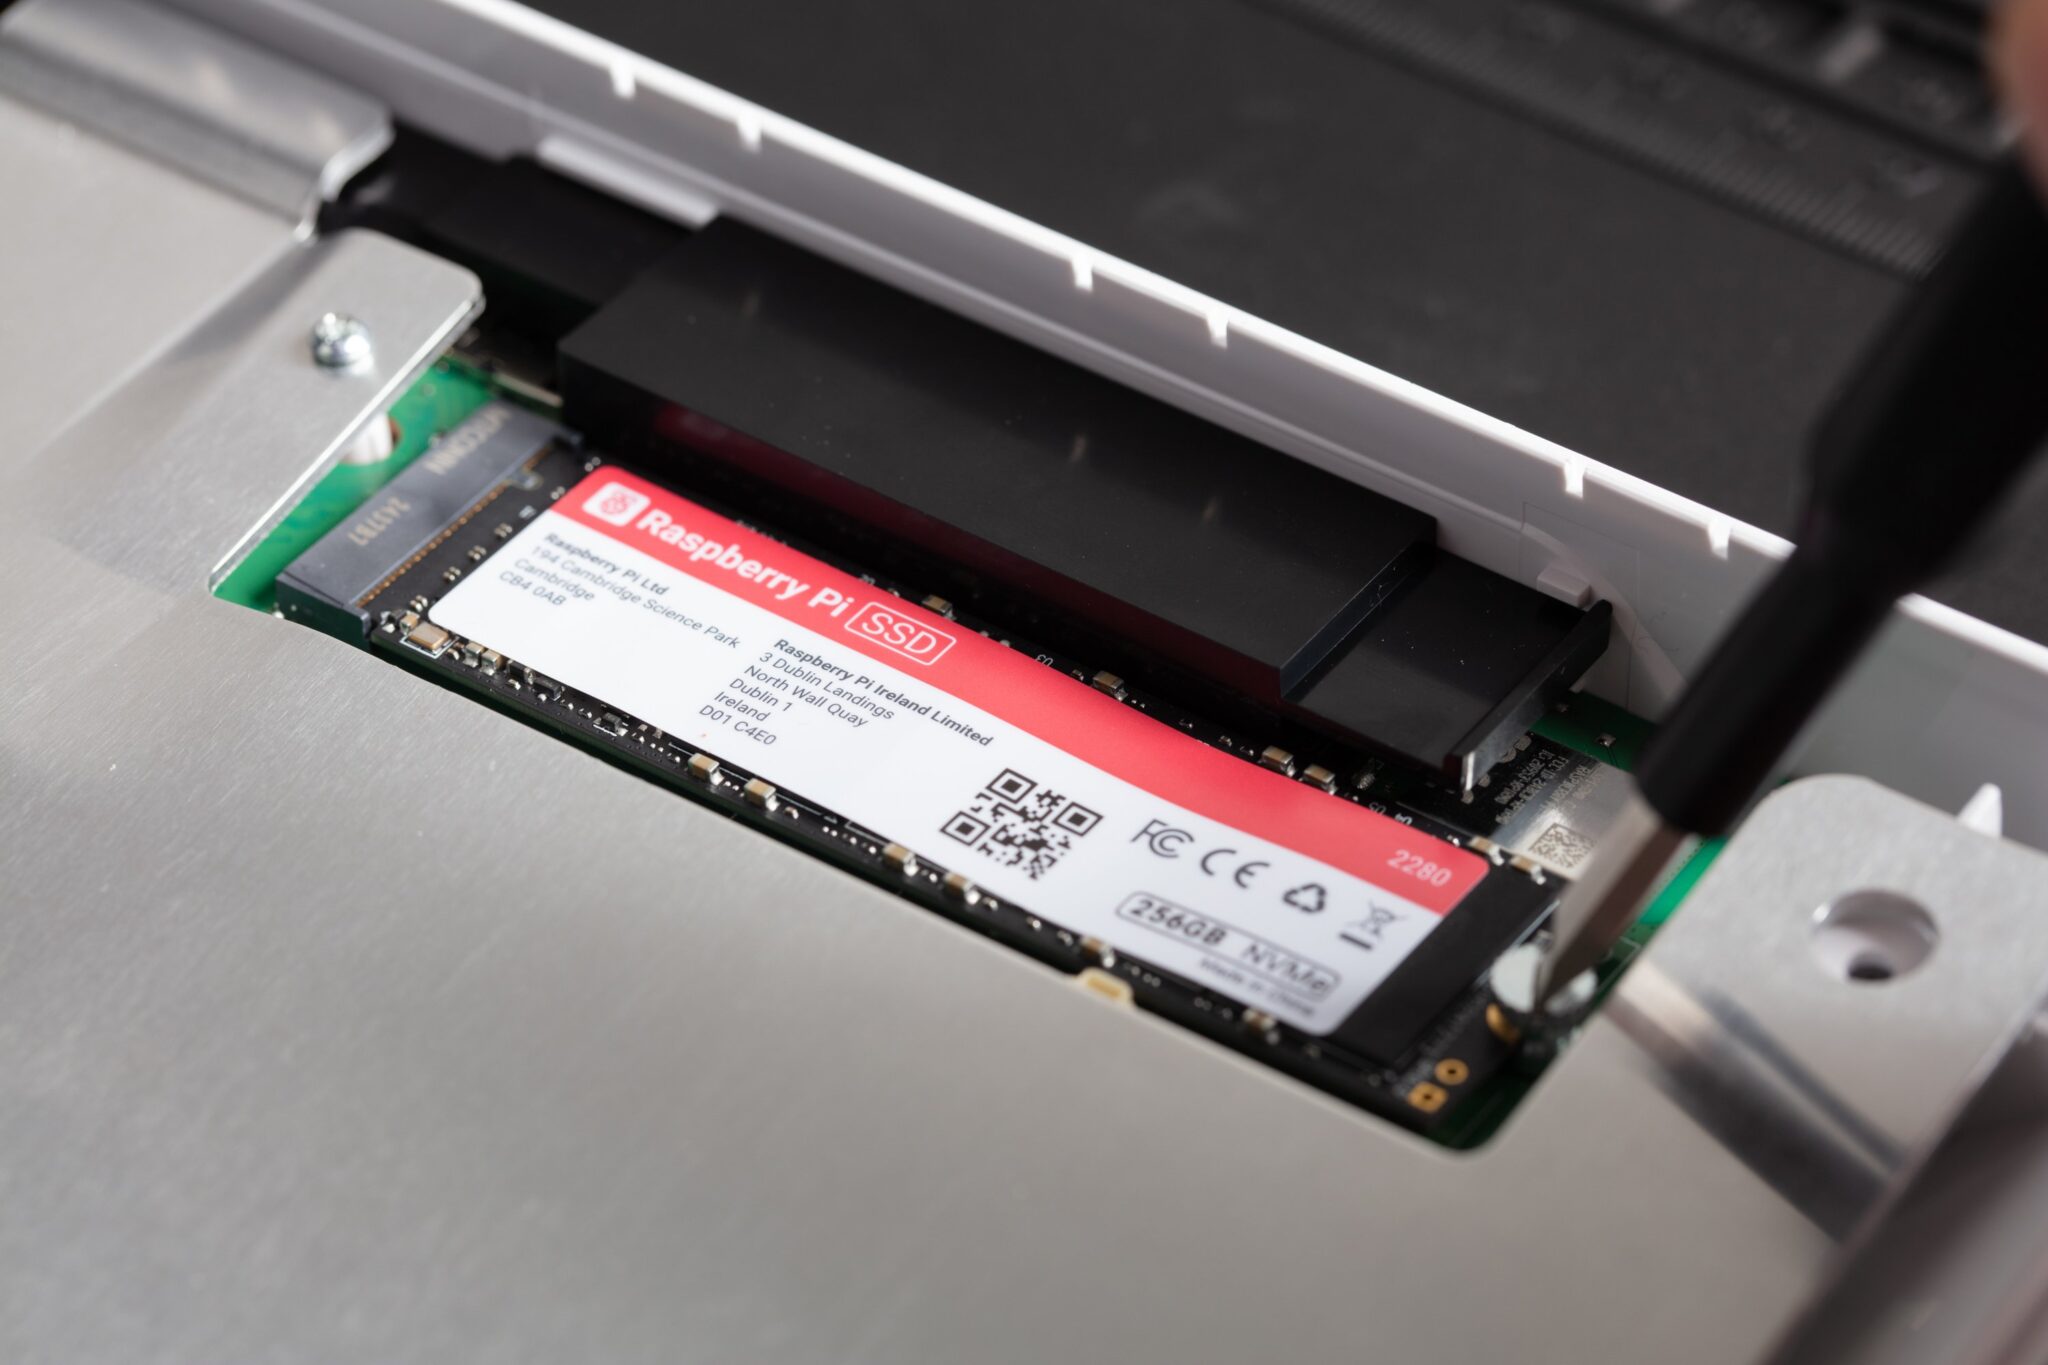
The 500+ comes with 16GB of RAM and a 256GB M.2 NVME SSD drive from the factory, exactly what we all wanted from the original 500. To everyone’s surprise the 500+ also comes with a new Clicky Gateron Blue KS-33 mechanical keyboard. This isn’t something I was expecting but, it was a nice surprise!
Connecting the 500+ to my mouse, ethernet cable, 4K monitor and official PSU it burst into life. The SSD comes preloaded with RaspberryPi OS and boots first time, no messing with loading ISO images to SD cards here!
The first thing I noticed was that the 500+ feels snappier than my Pi5, even though they both have the same SSD drive. Apps start just that bit quicker on the 500+ and copying files around feels quicker too.
Could this be because the SSD is now directly on the motherboard rather than at the end of a ribbon cable like on the Pi5?
The new keyboard is very different to use compared to the old 400/500 and the official RaspberryPi keyboard for the Pi SBC’s. It’s very clicky and slightly wider with more space between the keys. Initially this is annoying as it creates typo hell but, after some time your muscle memory adjusts and your typing gets back to it’s normal typo free experience.
The new keyboard is a nice improvement over the original 500 and makes the hiked price of £178.00 (with 20% discount) worth paying. The new keyboard is also backlit and can be adjusted to a range of colours and effects. I settled on having the keys light up in red once pressed as this is much easier on the eyes.
Since I’d been using a Pi5 with SSD as my desktop PC in the home office for over a year now I wanted to move my custom KDE-Plasma setup over to my new 500+ in place of the rather sparse RaspberryPi OS desktop that comes as standard on the 500+ SSD.
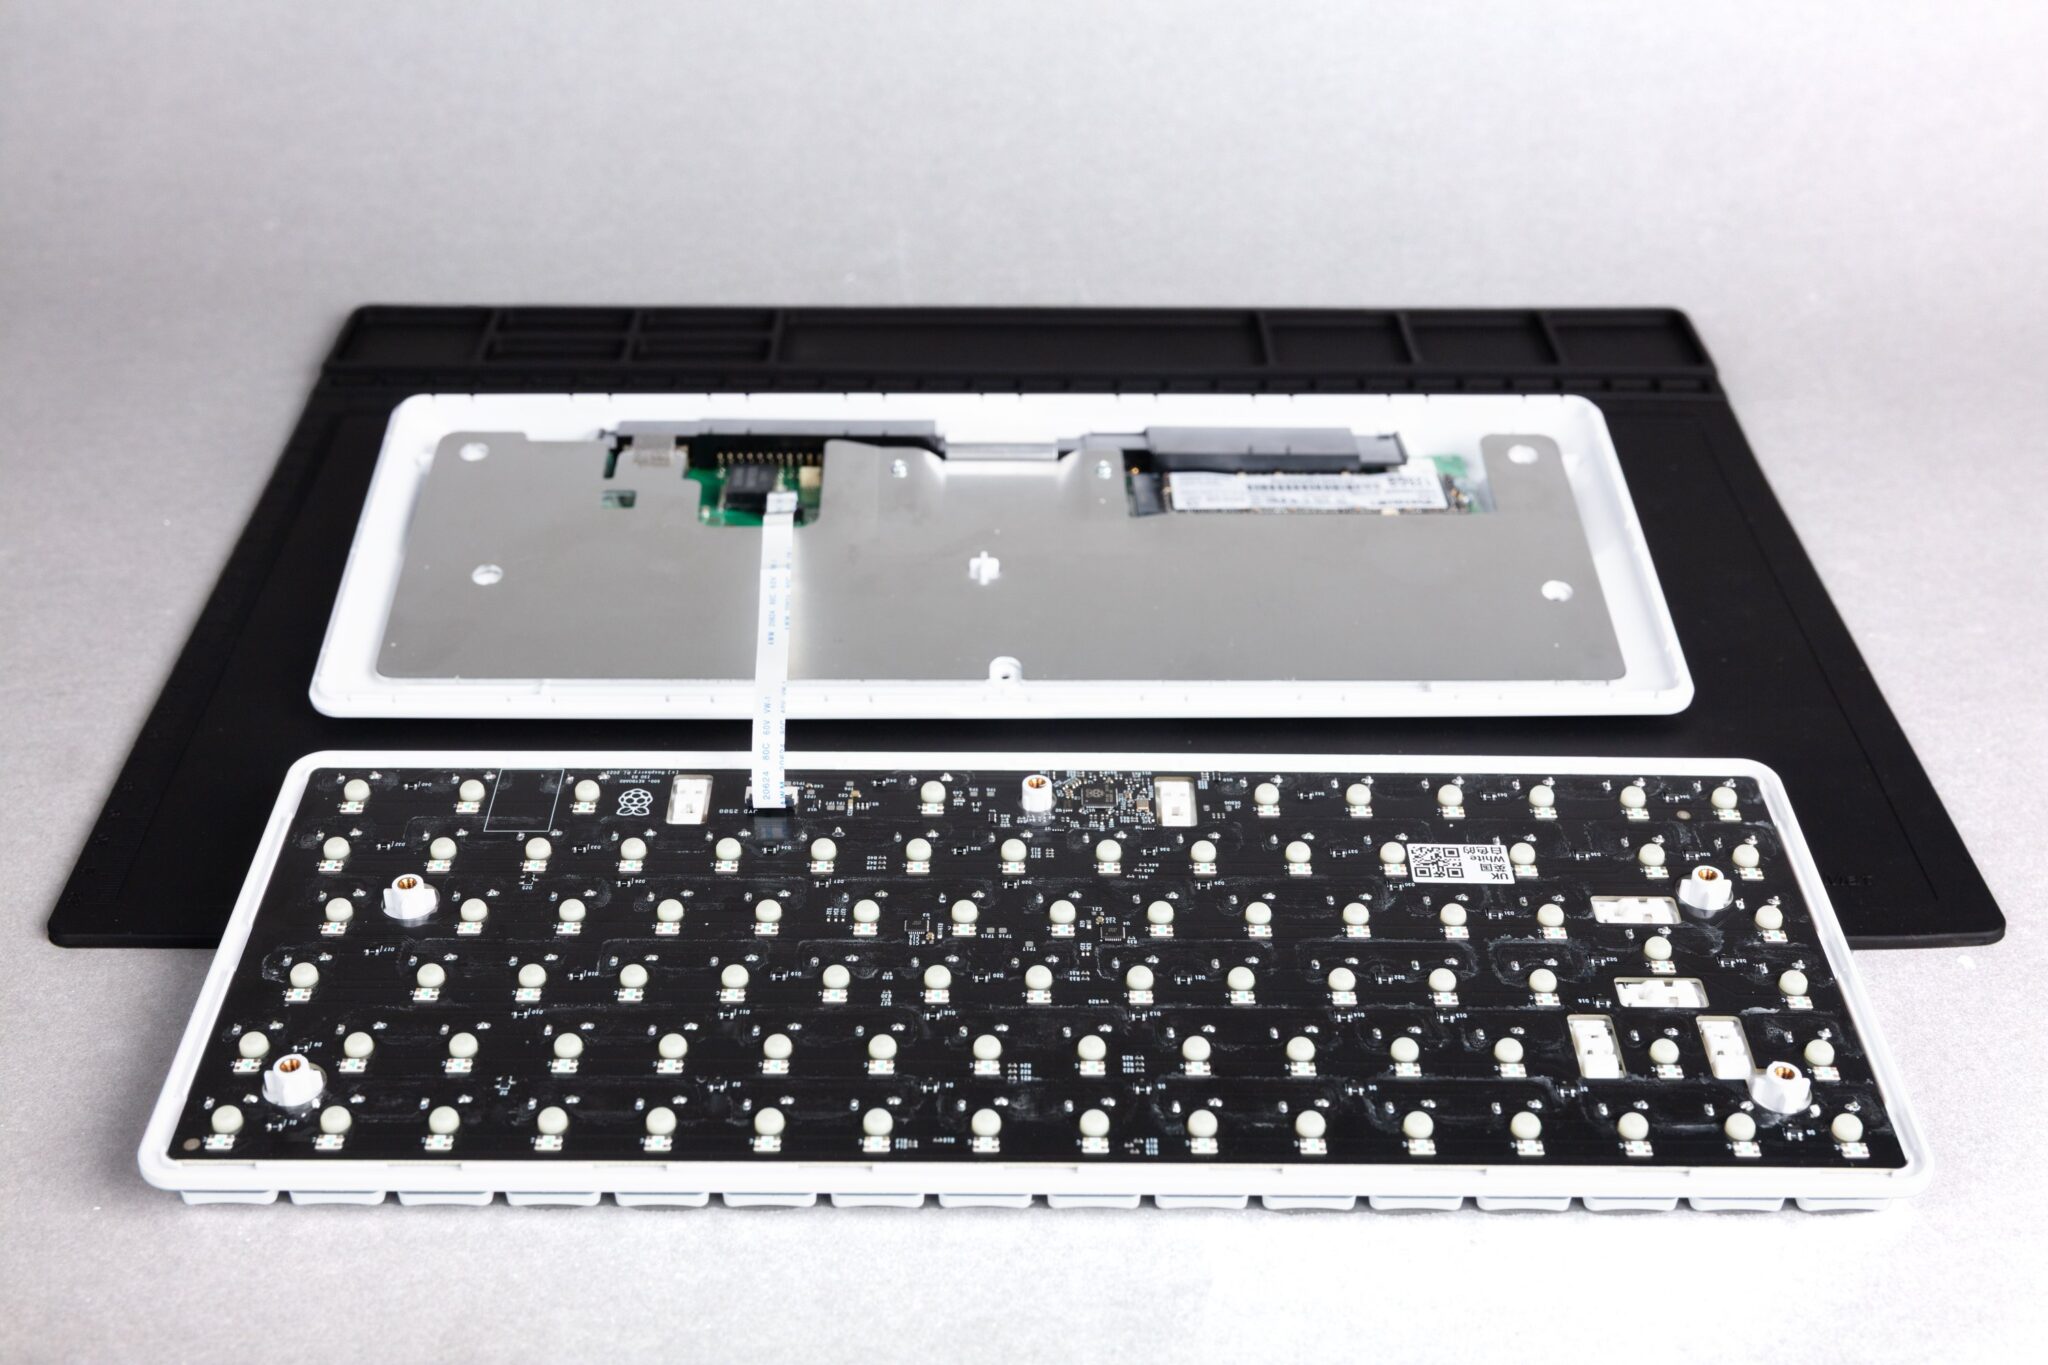
RaspberyPi 500+ open for SSD replacementRaspberryPi 500+ M.2 NVME SSD Drive
Opening the 500+ is relatively easy using the supplied spudger to tease the keyboard top and bottom apart once the screws have been removed.
Upon splitting the top and bottom sections you immediately become aware of the rather fragile looking ribbon cable that connects the keyboard to the motherboard. Access to the SSD drive is very good and it only took a minute to swap the drives over.
Gently clicking the keyboard back to the bottom half of the case and inserting all the screws I reconnected the computer to all my peripherals and switched it on.
In no time at all my favourite KDE-Plasma desktop and all my files and apps were at my fingertips just as they had been for the last year on my Pi5. An easy transition to the new 500+ now means I have a spare Pi5 and 250GB SSD for another project.
I must say that it would had been much nicer if there was a little removable panel on the bottom of the 500+ providing access to the SSD. This would had made it so much simpler to change the SSD drive without having to find the necessary tools to take the unit apart. Maybe an improvement for the 600+ next year!
The other thing I’ve noticed is that the 500+ runs considerably cooler than the Pi5 with the official cooler. My Pi5 would often reach 50 deg C however, the 500+ rarely gets above 30 deg C.
Overall I’m really pleased with my new RaspberryPi 500+, it’s the RaspberryPi I’ve been wanting in my home office for some time and finally it’s arrived.
Was it worth waiting for? Absolutely! It’s everything the 500 should had been at the outset.
Back in January 2025 I wrote an article about a little RadioBerry Project I’d started that was based around a very old Philips 170A-15 receiver from 1946.
The idea of the project was to build a nice shortwave receiver for the radio shack based around the RadioBerry HAT on a RaspberryPi 4 housed in a vintage receiver cabinet.
The project has taken longer than I imagined due to getting side-tracked by other projects that I already had ongoing.
With the original internals removed there’s plenty of room inside for the RadioBerry, RaspberryPi 4 and the small 15w audio amplifier. The audio is delivered via a pair of Celestion speakers that I had that were originally part of an old surround sound TV system.
Power distribution is achieved very simply using a multi-plug adapter that also has USB A connections in it. The whole thing is then powered via one 240v mains cable.
The screen fits over the original opening for the glass tuning display and is held in place by two mounting screws on the rear of the LCD panel.
I purchased some new speaker grill cloth from Amazon and remade the speaker grill front with cut outs for the speakers. It looks really tidy and matches the rest of the bakelite cabinet nicely.
1946 Philips 170A-15 Shortwave Receiver RadioBerry HAT on RaspberryPi 4
To finish the project off I need to purchase 3 rotary encoders so that I can have a VFO knob and two more knobs for other things (to be determined). The Volume control is already in place with the original knob fitted to it. It will be nice to complete the 4 knob line up.
I had to make a couple of fittings top and bottom to hold the original rear panel in place but, it worked out just fine and I only had to fit an SO239 antenna connector and ethernet RJ45 port so that it can be connected to my local LAN.
Receiving radio Caroline on 648Khz
The audio quality from the little RadioBerry and 15w amp is pretty good. With the speakers hidden nicely behind the refurbished speaker grill the project looks quite tidy!
It also makes a great receiver for the HAM bands with it’s coverage of 100Khz to 30Mhz.
The DL1YCF Enhanced fork of PiHPSDR works really well on the touchscreen and provides a modern control interface to the RadioBerry HAT.
Listening to the 20m HAM Band
I’ll drop a final article once I have purchased the 3 rotary encoders to fill the 3 remaining holes in the front of the cabinet.
Over the last few weeks I’ve been working on my install-pihpsdr script to build a version of the DL1YCF PiHPSDR fork that will work with the Adalm Pluo, Pluto+ and LibreSDR transceivers.
Since I don’t own any of these devices, Steve M0XVT has loaned me his Adalm Pluto and LibreSDR devices to test with.
Initially neither of the devices would work with the PiHPSDR build that my script was creating. After some investigation I found this was due to the fact that the developer build script was only building the SOAPYSDR library, it wasn’t building the modules for each device type.
This was easily fixed by adding some extra code that would build the necessary SOAPYSDR modules so that the devices were discovered on the local LAN.
Since I had the devices to hand I took the opportunity to test the updated build script on a number of Linux Distro’s that I have to hand.
PiHPSDR running on Linuxmint 22.1 Cinnamon Edition using the LibreSDR transceiver
I tested the updated build script on Kubuntu 22.04LTS, Linuxmint 22.1 Cinnamon Edition and RaspberryPi 4/5 running the latest RaspberryPi OS 64bit version.
These all worked great with the transceivers and will now make a great platform for QO-100 stations that use either the Adalm Pluto, Pluto+ or LibreSDR devices.
Of course this build of PiHPSDR will also work with the Hermes Lite 2 and RadioBerry devices that I use most of the time in my own radio shack.
The updated PiHPSDR install script can be downloaded from my original blog article on the subject that is located here: https://m0aws.co.uk/?p=3686
The updated build script will most likely work on most Debian based Linux distro’s and build a working version of PiHPSDR. If you find a distro where you have problems please email me and let me know the details and I’ll happily look at the issue and try to resolve it.
Thanks to Steve for the loan of his precious SDR transceivers, I had a lot of fun with them!
Let me start this article by confessing that I hate Snap on Linux!
The whole idea that you’d need a container type environment to install an application on a Unix system is very far from where I want to be.
It annoys me that snaps are updated automatically too. I know you can disable this but, I shouldn’t have too. App’s should only get updated when I want to update them, not before.
What I really hate is the fact that the Snap back end system is proprietary and owned solely by Canonical, the Ubuntu people. This goes against my OpenSource ethos.
Sadly I had to install Snap to get the Signal messenger app installed on my RaspberryPi 5 desktop computer. App’s installed via Snap are extremely slow to start, run slow and are heavy on resources. Snap also mounts a whole bunch of dependency Snaps via loop devices to make the app work. Snaps make a real mess of your system.
The final straw that broke the camel’s back for me was when Snap did an automatic upgrade to Signal to a version that has a serious bug in it causing it to crash a minute or so after startup. I initially reverted to the previous version to get it working again but, sure enough Snap did another auto-update and broke it again.
This time I couldn’t revert back to the previous version as Canonical, in their infinite wisdom decided to remove the previous version of Signal from their Snap store!
At this point I removed the Signal Snap from my computer, along with all the “hanger on” snap packages that were clogging up the RaspberyyPi 5 and finally did a complete purge of snapd using dpkg to get rid of all the horrendous snap mount points on the file system.
After a reboot I then went hunting for the Signal messenger app source code. Looking through the code it’s not a 5min job to get it compiled on a RaspberryPi and so I followed a few of the forked versions to see if someone had already done all the hard work for me.
After disappearing down a few Rabbit Holes I eventually stumbled into the world of Pi Apps.
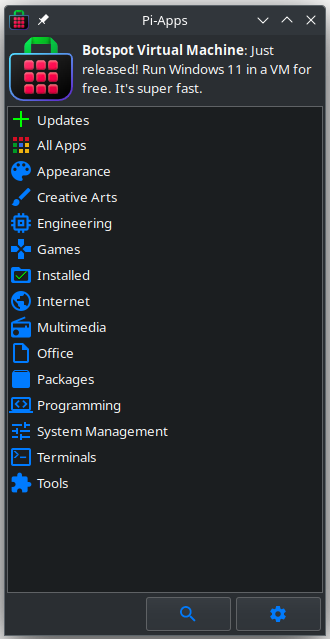
Pi Apps is a neat little app that provides access to the “most popular app store for RaspberryPi computers”. It’s 100% free, OpenSource and written in shell scripts. Perfect!
Installing the “Pi Apps” app is straight forward and only takes a few moments.
Pi-Apps – App store for RaspberryPi
Opening Pi-Apps I found a multitude of OpenSource apps all ready to be installed at the click of a button. In no time at all I’d found Signal and had it installed without getting anywhere near the dreaded Snap.
The version of Signal available at the time of writing this article is v7.39.0 which is fine as this is a stable, bug free version that works reliably.
If you’re using a RaspberryPi computer I can highly recommend you install the Pi-Apps app to enhance your collection of great OpenSource programmes to make your little raspberry flavoured buddy even more useful.
Sometime back I purchased a RadioBerry HAT for my RaspberryPi 4 single board computer (SBC) to use as an experimental platform to test PiHPSDR software modifications and to test changes to the actual RadioBerry software. With these two projects completed I decided that the receiver on the RadioBerry was so good it would be a shame not to put it to good use.
RadioBerry HAT
For many decades I’ve been an avid Short Wave Listener (SWL) but, haven’t had a general coverage receiver for many years. The RadioBerry fills this gap in my radio lineup perfectly but, needs to be put into a suitable cabinet with speakers, display, control knobs and antenna connections.
Rather than just buy another bland square box I decided it would be nice to repurpose an old, vintage radio receiver from a bygone era and bring it into the 21st Century.
1946 Philips valve radio receiver
After much searching on the popular auction sites online I eventually found the perfect old receiver for the project, a vintage Philips 170A-15 valve receiver from 1946.
This lovely old Art Deco looking receiver is made from Bakelite which was an early type of plastic made from phenol-formaldehyde resin, obtained from coal tar and methanol.
The full specification for the receiver can be found on the Radio Museum Website.
Sadly this is a non working example of this lovely old receiver and so I don’t feel so guilty stripping it out and replacing it’s internals with the RadioBerry.
1946 Philips receiver Serial Number plate1946 Philips receiver Licence Plate
Having the original serial number and Licence plate on the radio is nice, it also makes it easy to search for information about the old receiver.
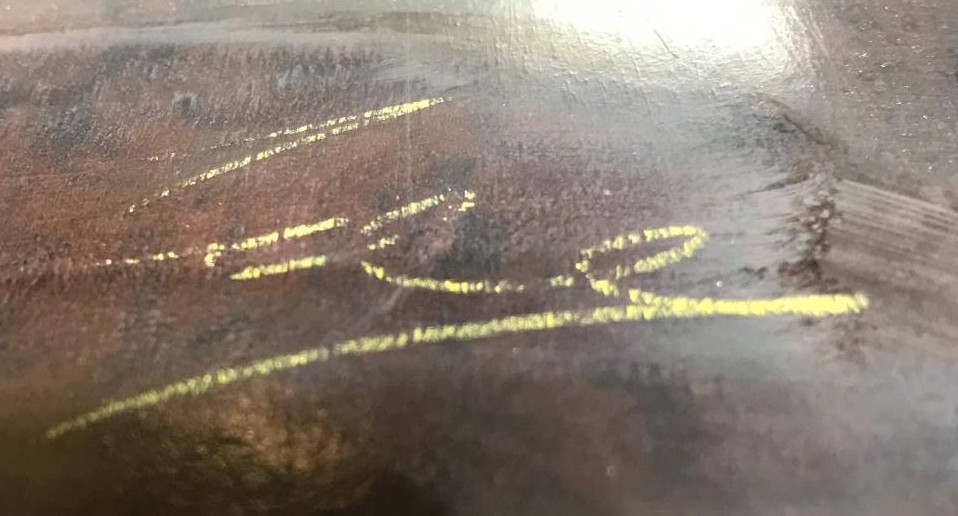
One nice thing I did discover during the disassembly of the receiver was the signature of the person that put the radio together during manufacture on the inside of the Bakelite cabinet.
1946 Philips receiver builder signature
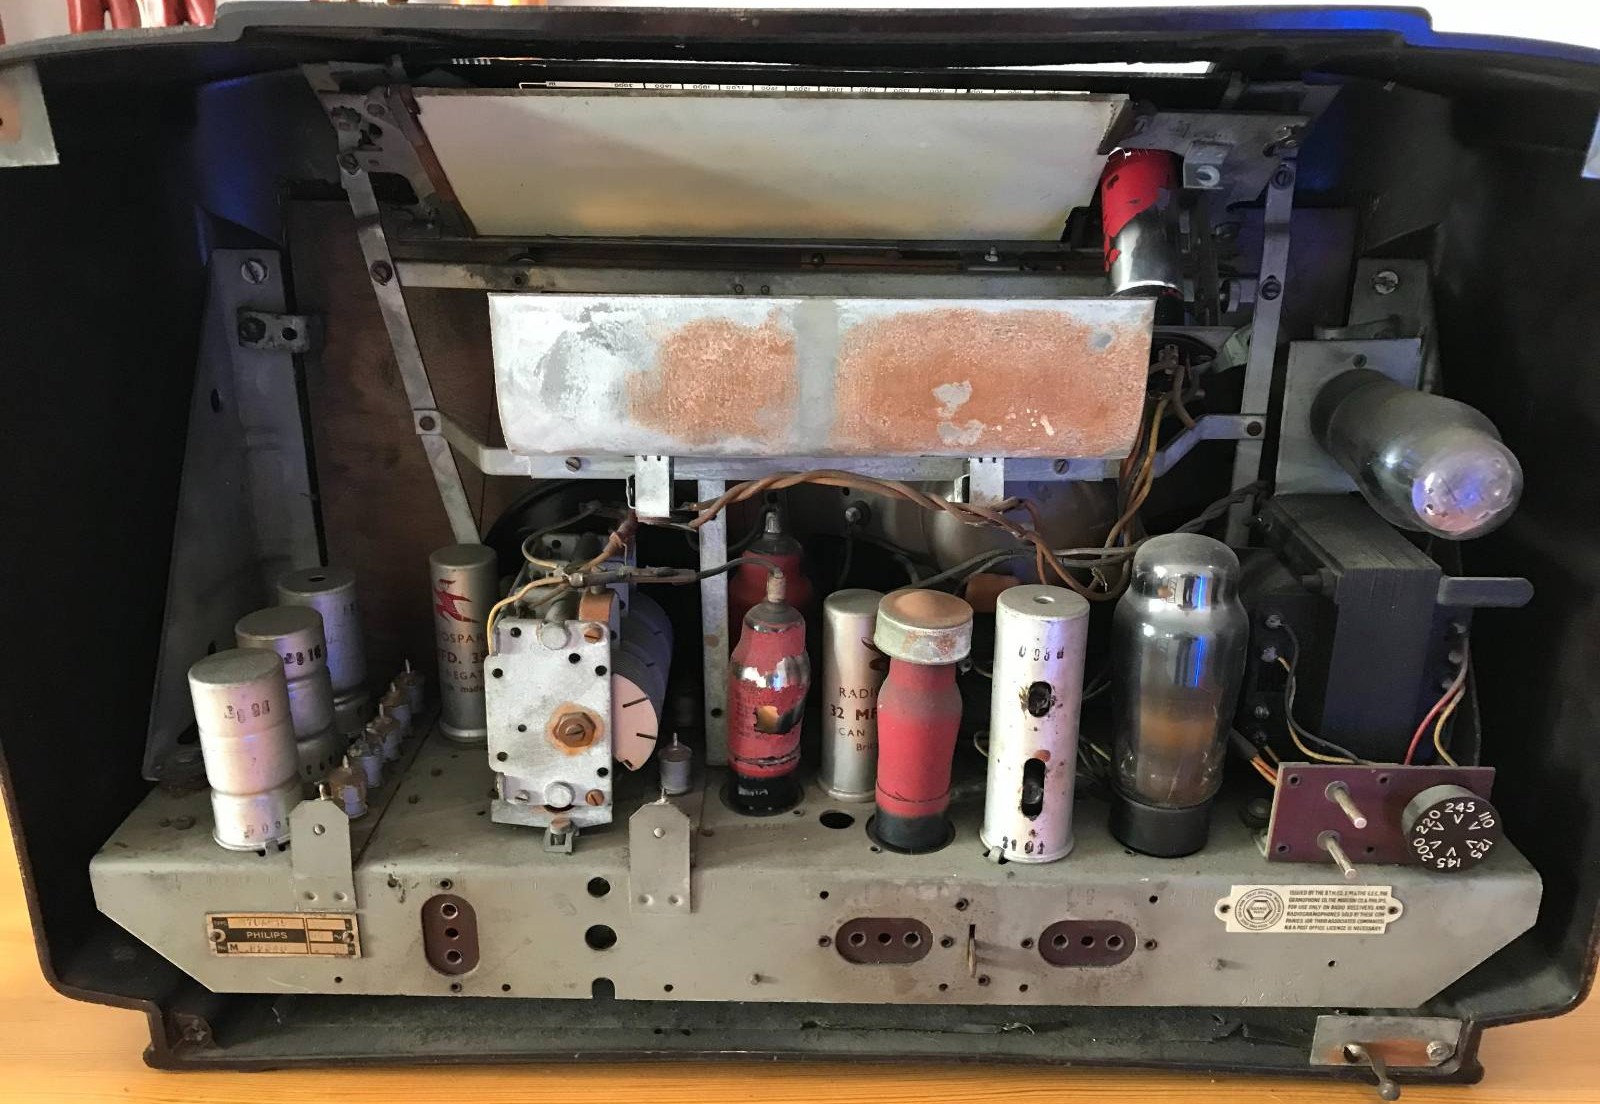
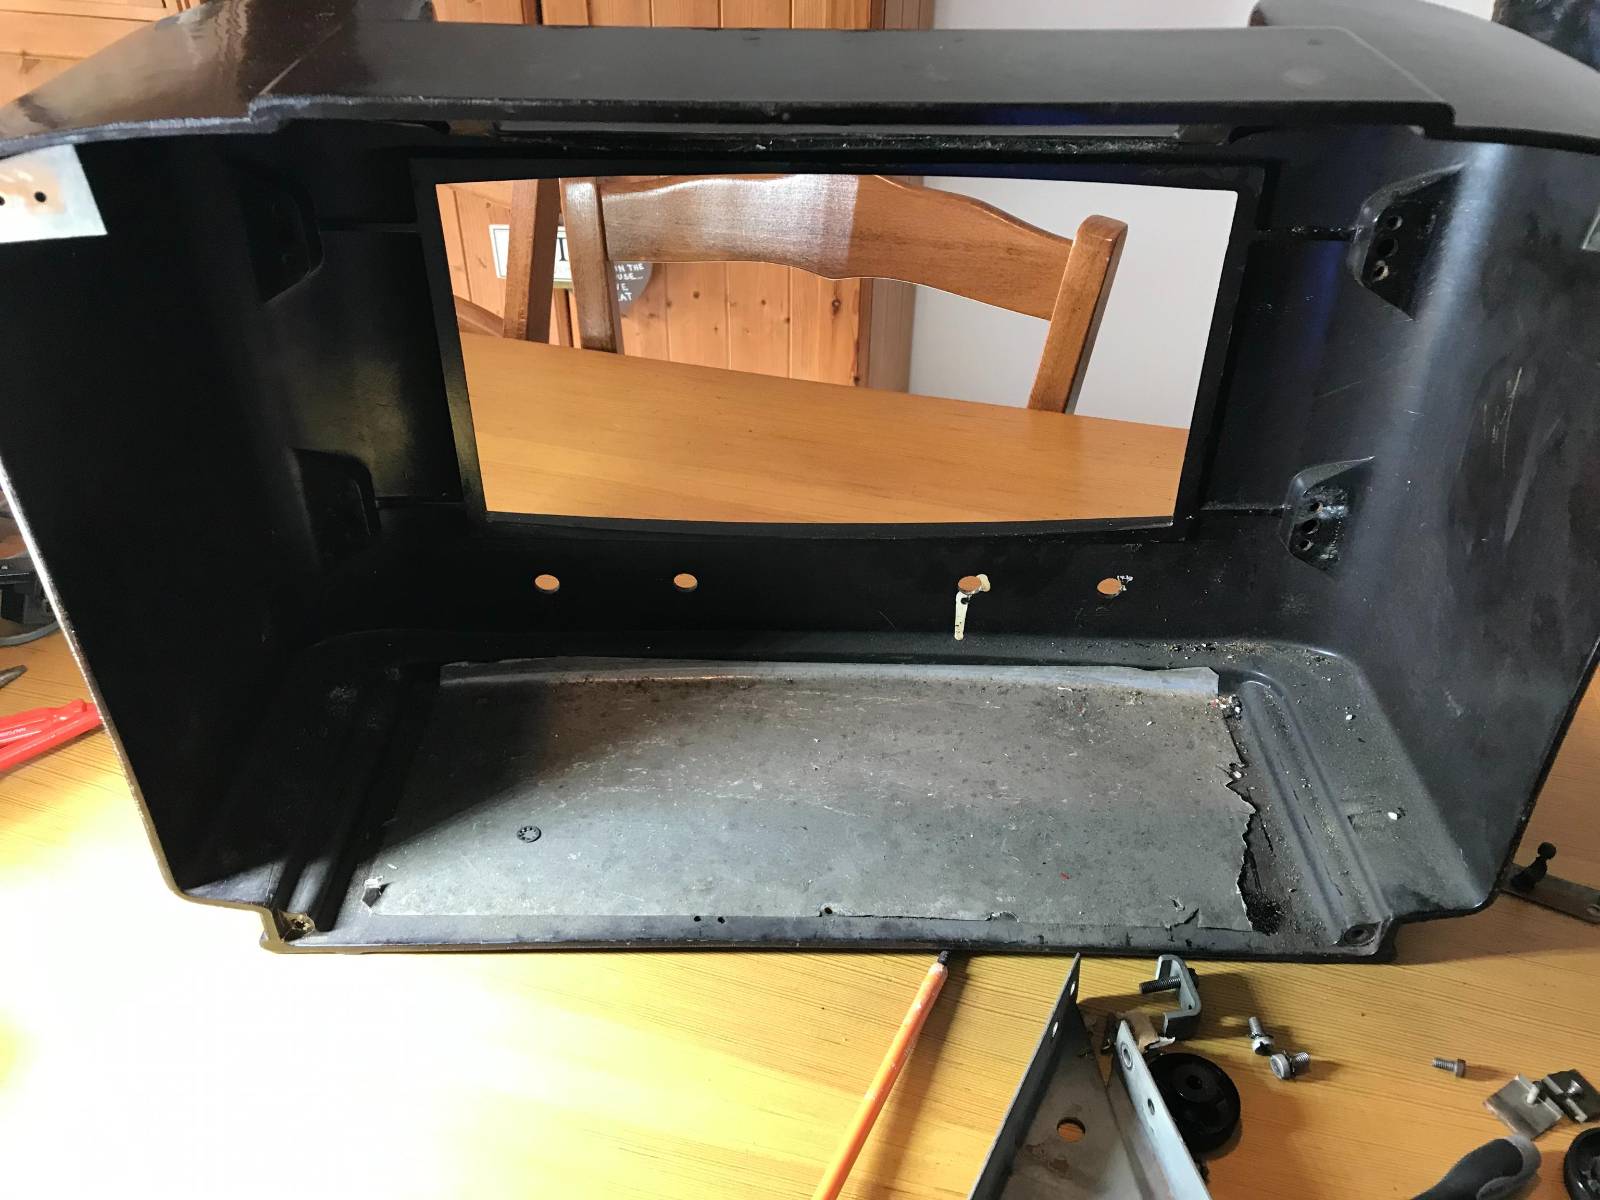
Getting the internals out of the cabinet was fun, so many little screws holding the old valve electronics and tuning display in place.
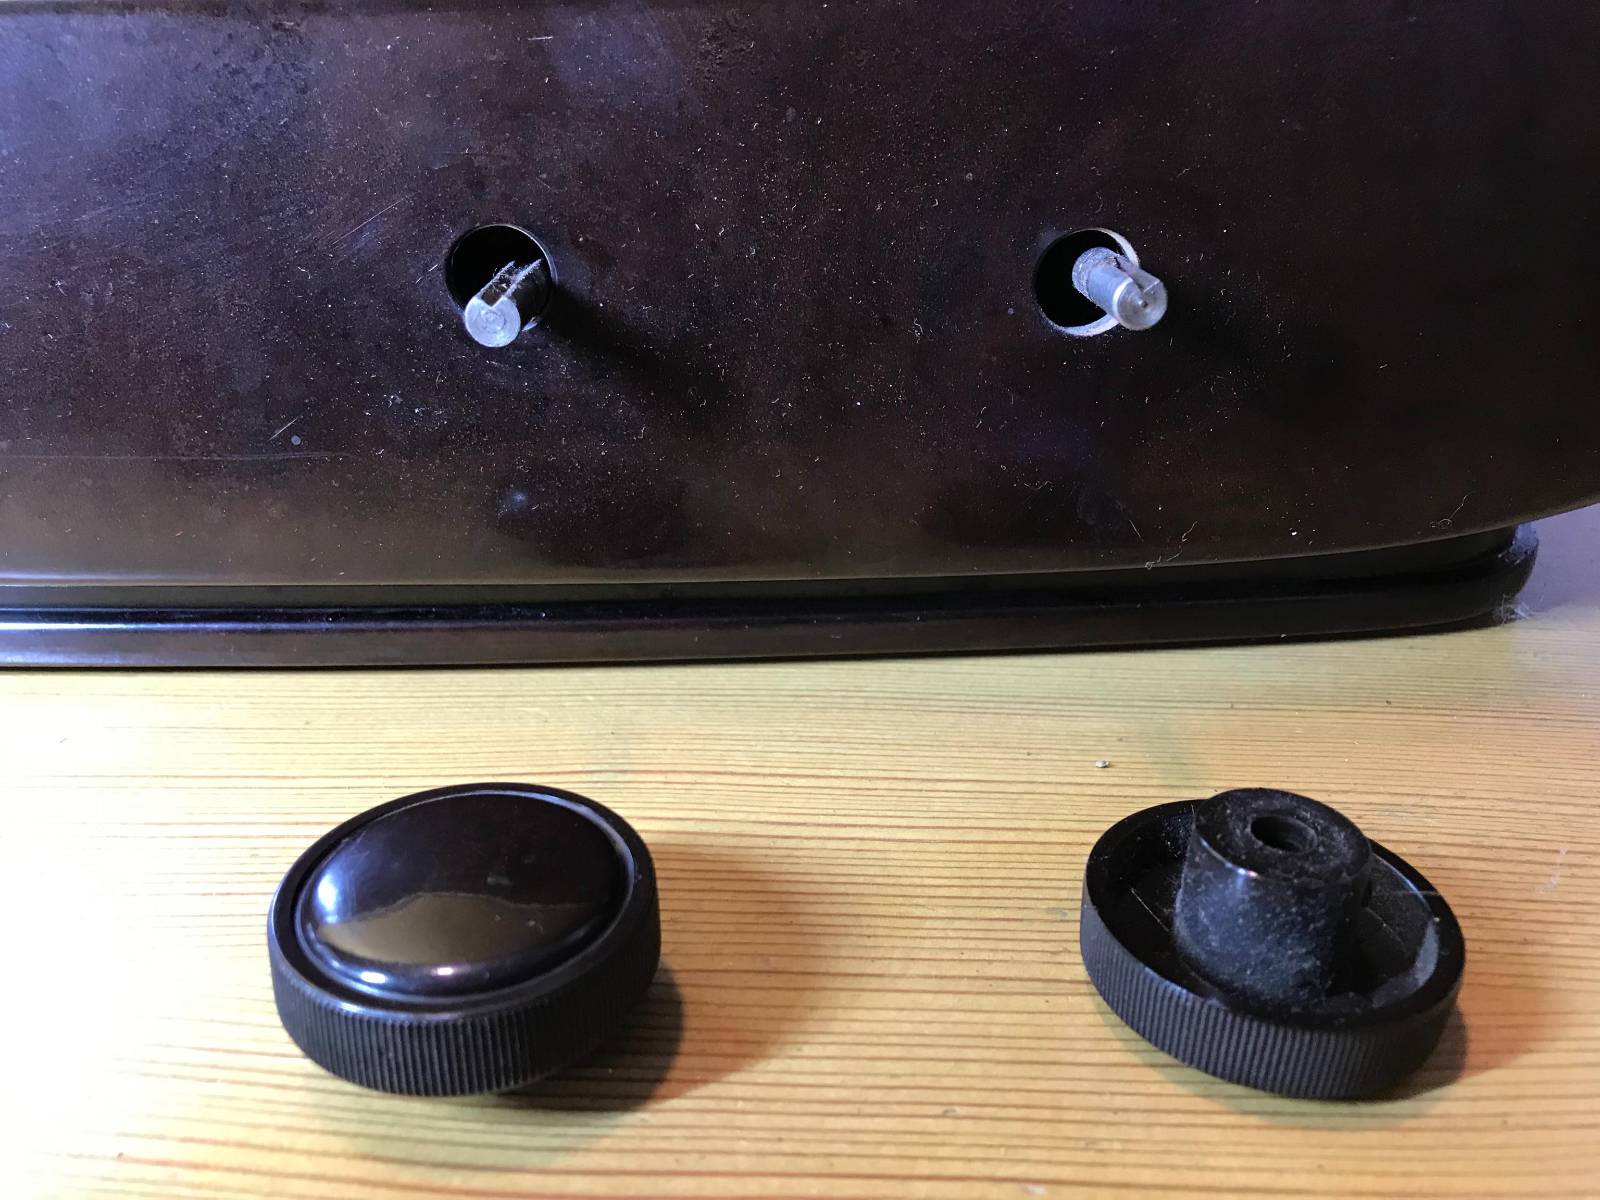
1946 Philips Receiver – Internal View1946 Philips receiver – removing the original control knobs
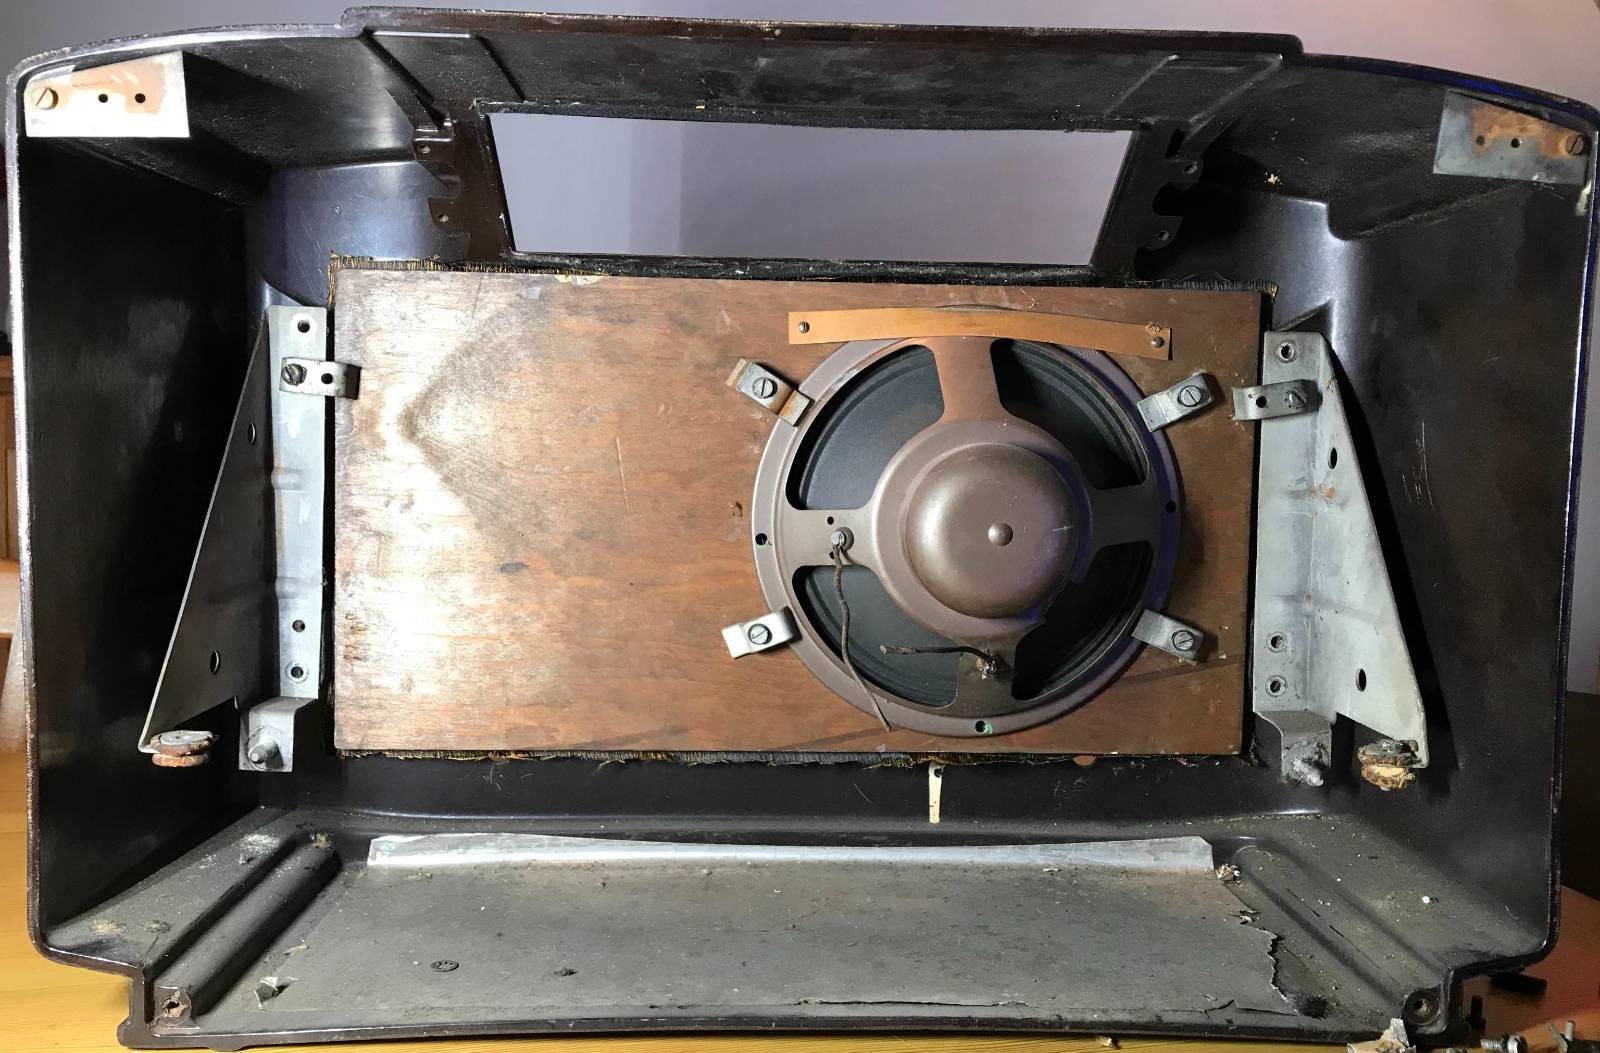
Once the electrical part of the radio was removed I gained access to the old speaker that was fitted to the front panel of the receiver. Unfortunately the speaker cone had a tear in it rendering it useless so I’ll need to get a new speaker(s) for the rebuild.
1946 Philips receiver speaker view
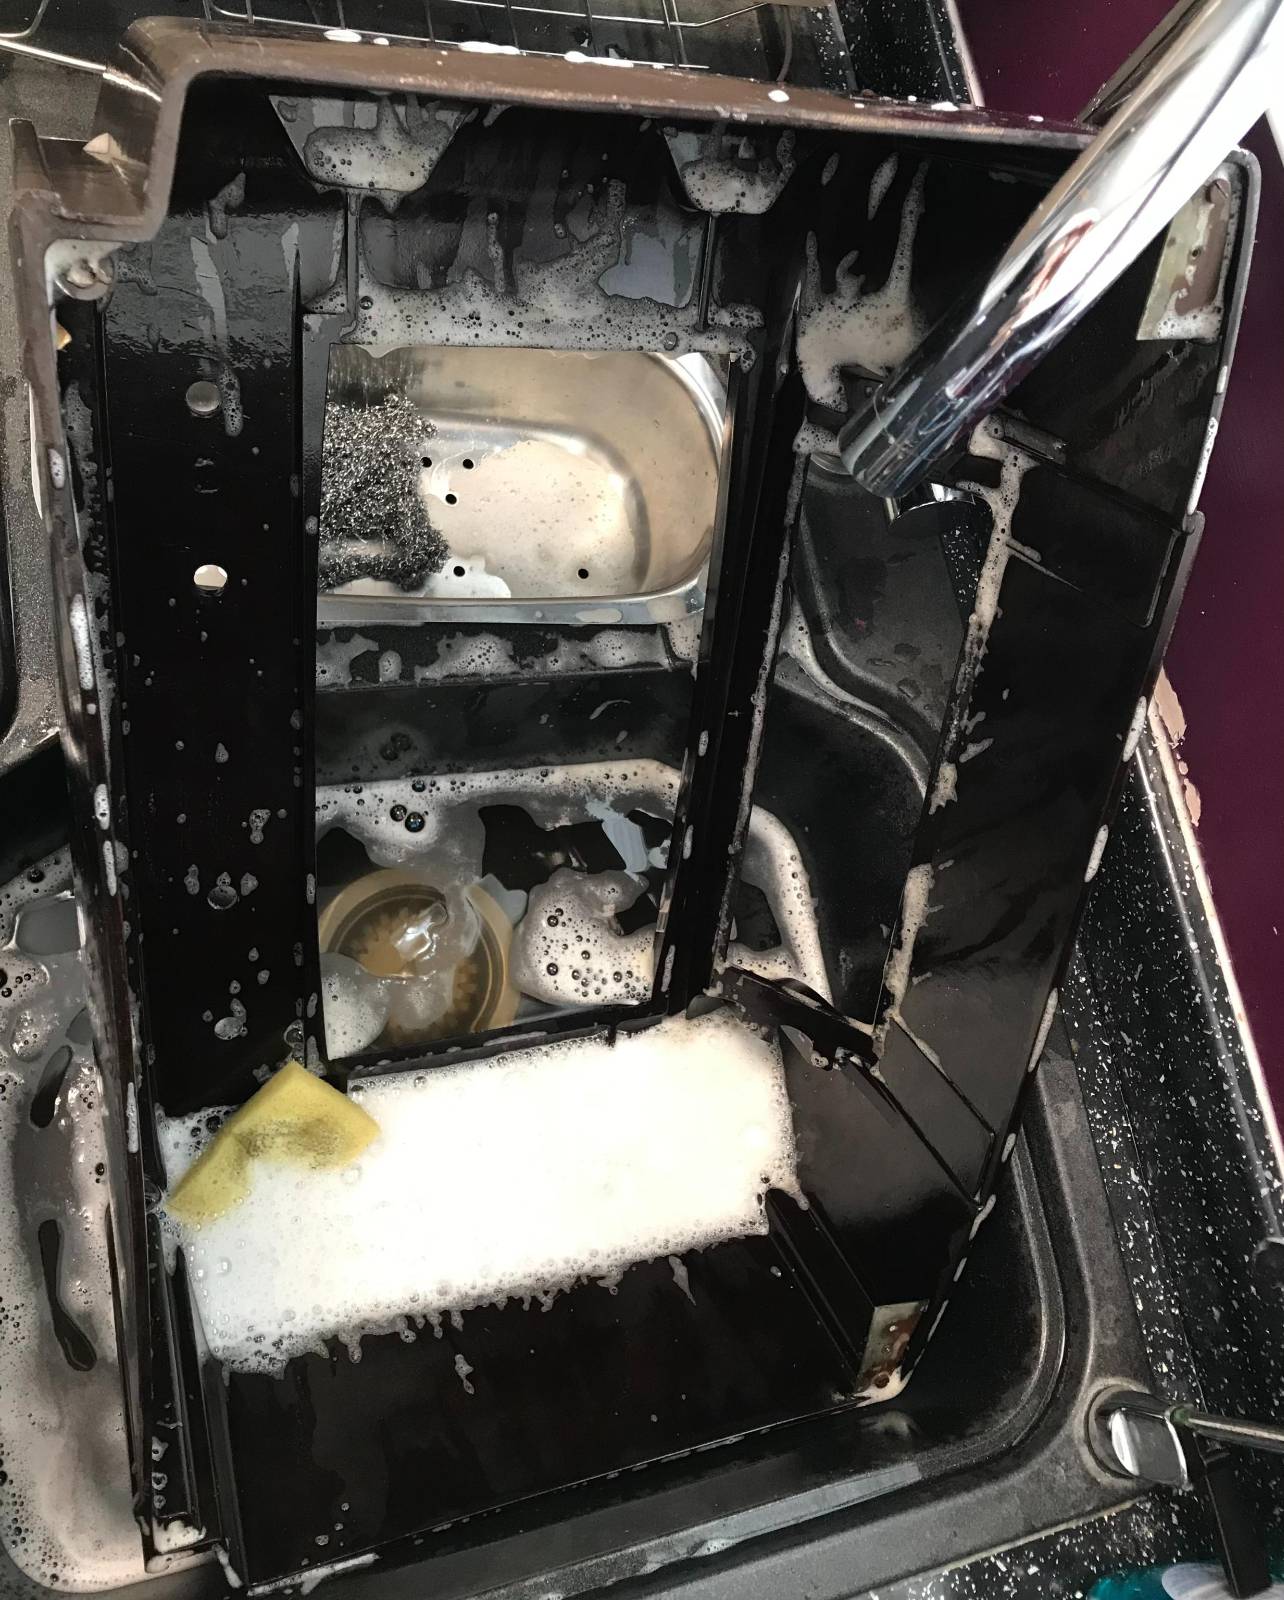
Once I got the speaker and fittings removed I set about cleaning the cabinet inside and out to remove the 79 years worth of dirt and grime that had collected within. The fascia of the receiver cabinet seems to have lost it’s shine and will need to be polished to get it back to it’s original beauty.
79 years worth of grime and dirt to be removed!Washing the Bakelite receiver case
It took 5 lots of fresh water and washing up liquid to get the cabinet clean. The first three lots of water looked like mud in no time at all such was the state of the cabinet.
With the cabinet now cleaned and put to one side to dry thoroughly I have started to search for the best type of polish to use to put the sheen back onto it.
Once I’ve got the cabinet looking good again I’ll start fitting the new internals. I also need to find a source for a new piece of material to cover the speaker hole at the front of the cabinet as the original material is looking somewhat tired.
The old Philips Emblem from 1946 on the receiver case
Since I’ve had my Hermes Lite 2 (HL2) and Xiegu XPA125B amplifier combo I’ve had to manually change the band setting on the amp as I never purchased the HL2 I/O board when I initially purchased the kit.
At the time I didn’t think I would need it but, changing band manually on the amp (and sometimes forgetting causing tuning issues) is a nuisance and so I put my hand in my pocket once again and ordered the I/O board for the HL2.
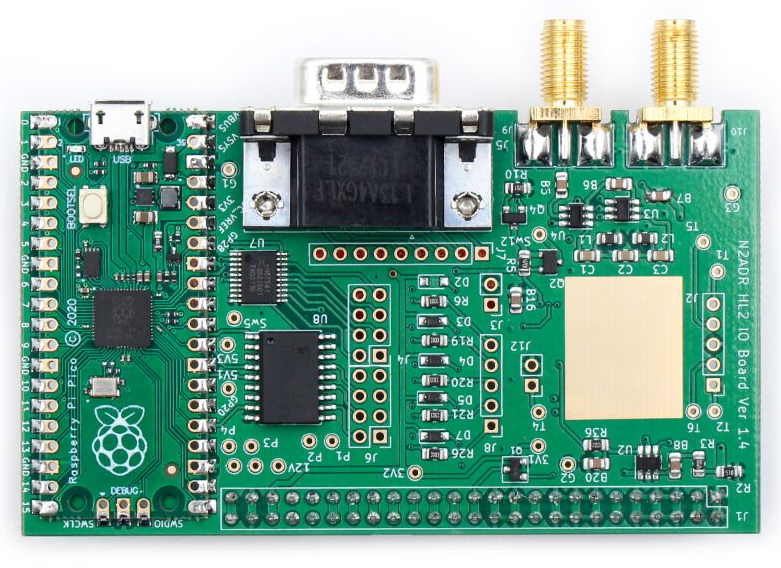
Hermes Lite 2 I/O Board
The HL2 I/O board is a small RaspberryPi Pico controlled device that can be used for a multitude of functions depending on the software loaded. Many people are writing their own software for the Pico to do things like control transverters, remote antenna switches, amplifiers and just about anything else you can think of. It’s a really versatile little add on board for the HL2.
The I/O board arrived after about 10 days from Makerfabs, all nicely packaged as always. Unfortunately due to Christmas, New year and other priorities it’s sat in the box since it arrived.
A couple of days ago I finally got round to getting it out of the box and set about configuring it to control the Xiegu amp.
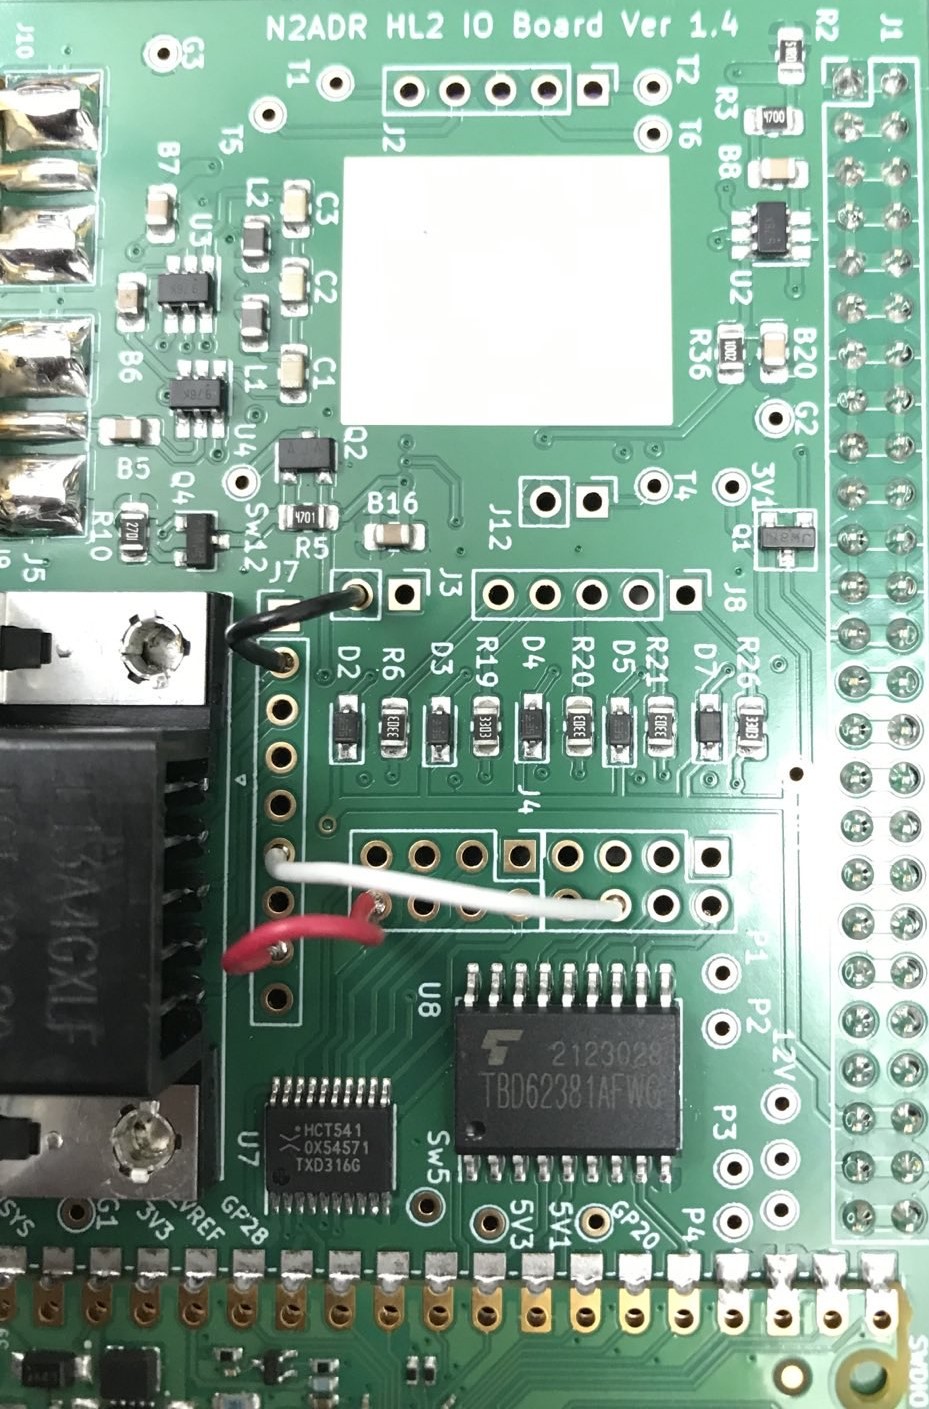
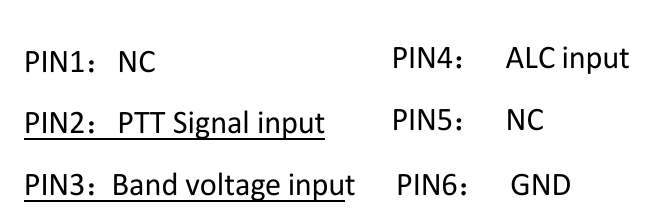
The Xiegu amp needs three connections from the I/O board. They are PTT, Band Switching Voltage and Ground. These are easily accessed from the I/O board via 3 jumper wires to connect to the DB9 connector on the rear of the board.
The other thing that is required is some software for the RaspberryPi Pico to control the whole process. Steve, M0XVT has kindly supplied me with a copy of the software.
Soldering the jumpers from the relevant points on the circuit board to the DB9 connector was pretty straight forward. You can use any of the pins on the DB9 connector that you like as from the factory the DB9 connector isn’t connected to anything. I decided to use pins 2, 6 and 8 and so will refer to those pins from this point forward.
HL2 I/O Board Jumpers
I used a different colour for each of the jumpers so that I knew which jumper was for which connection. The colours used also match the colours of the wire in the old RS232 serial lead that I cannibalized to make the connection between the I/O board and the amp thus making it easy to ensure continuity.
The colours are as follows:
Black Jumper - Ground - Pin 2 on DB9 Connector
White Jumper - PTT - Pin 6 on DB9 Connector
Red Jumper   - Band Control - Pin 8 on DB9 Connector
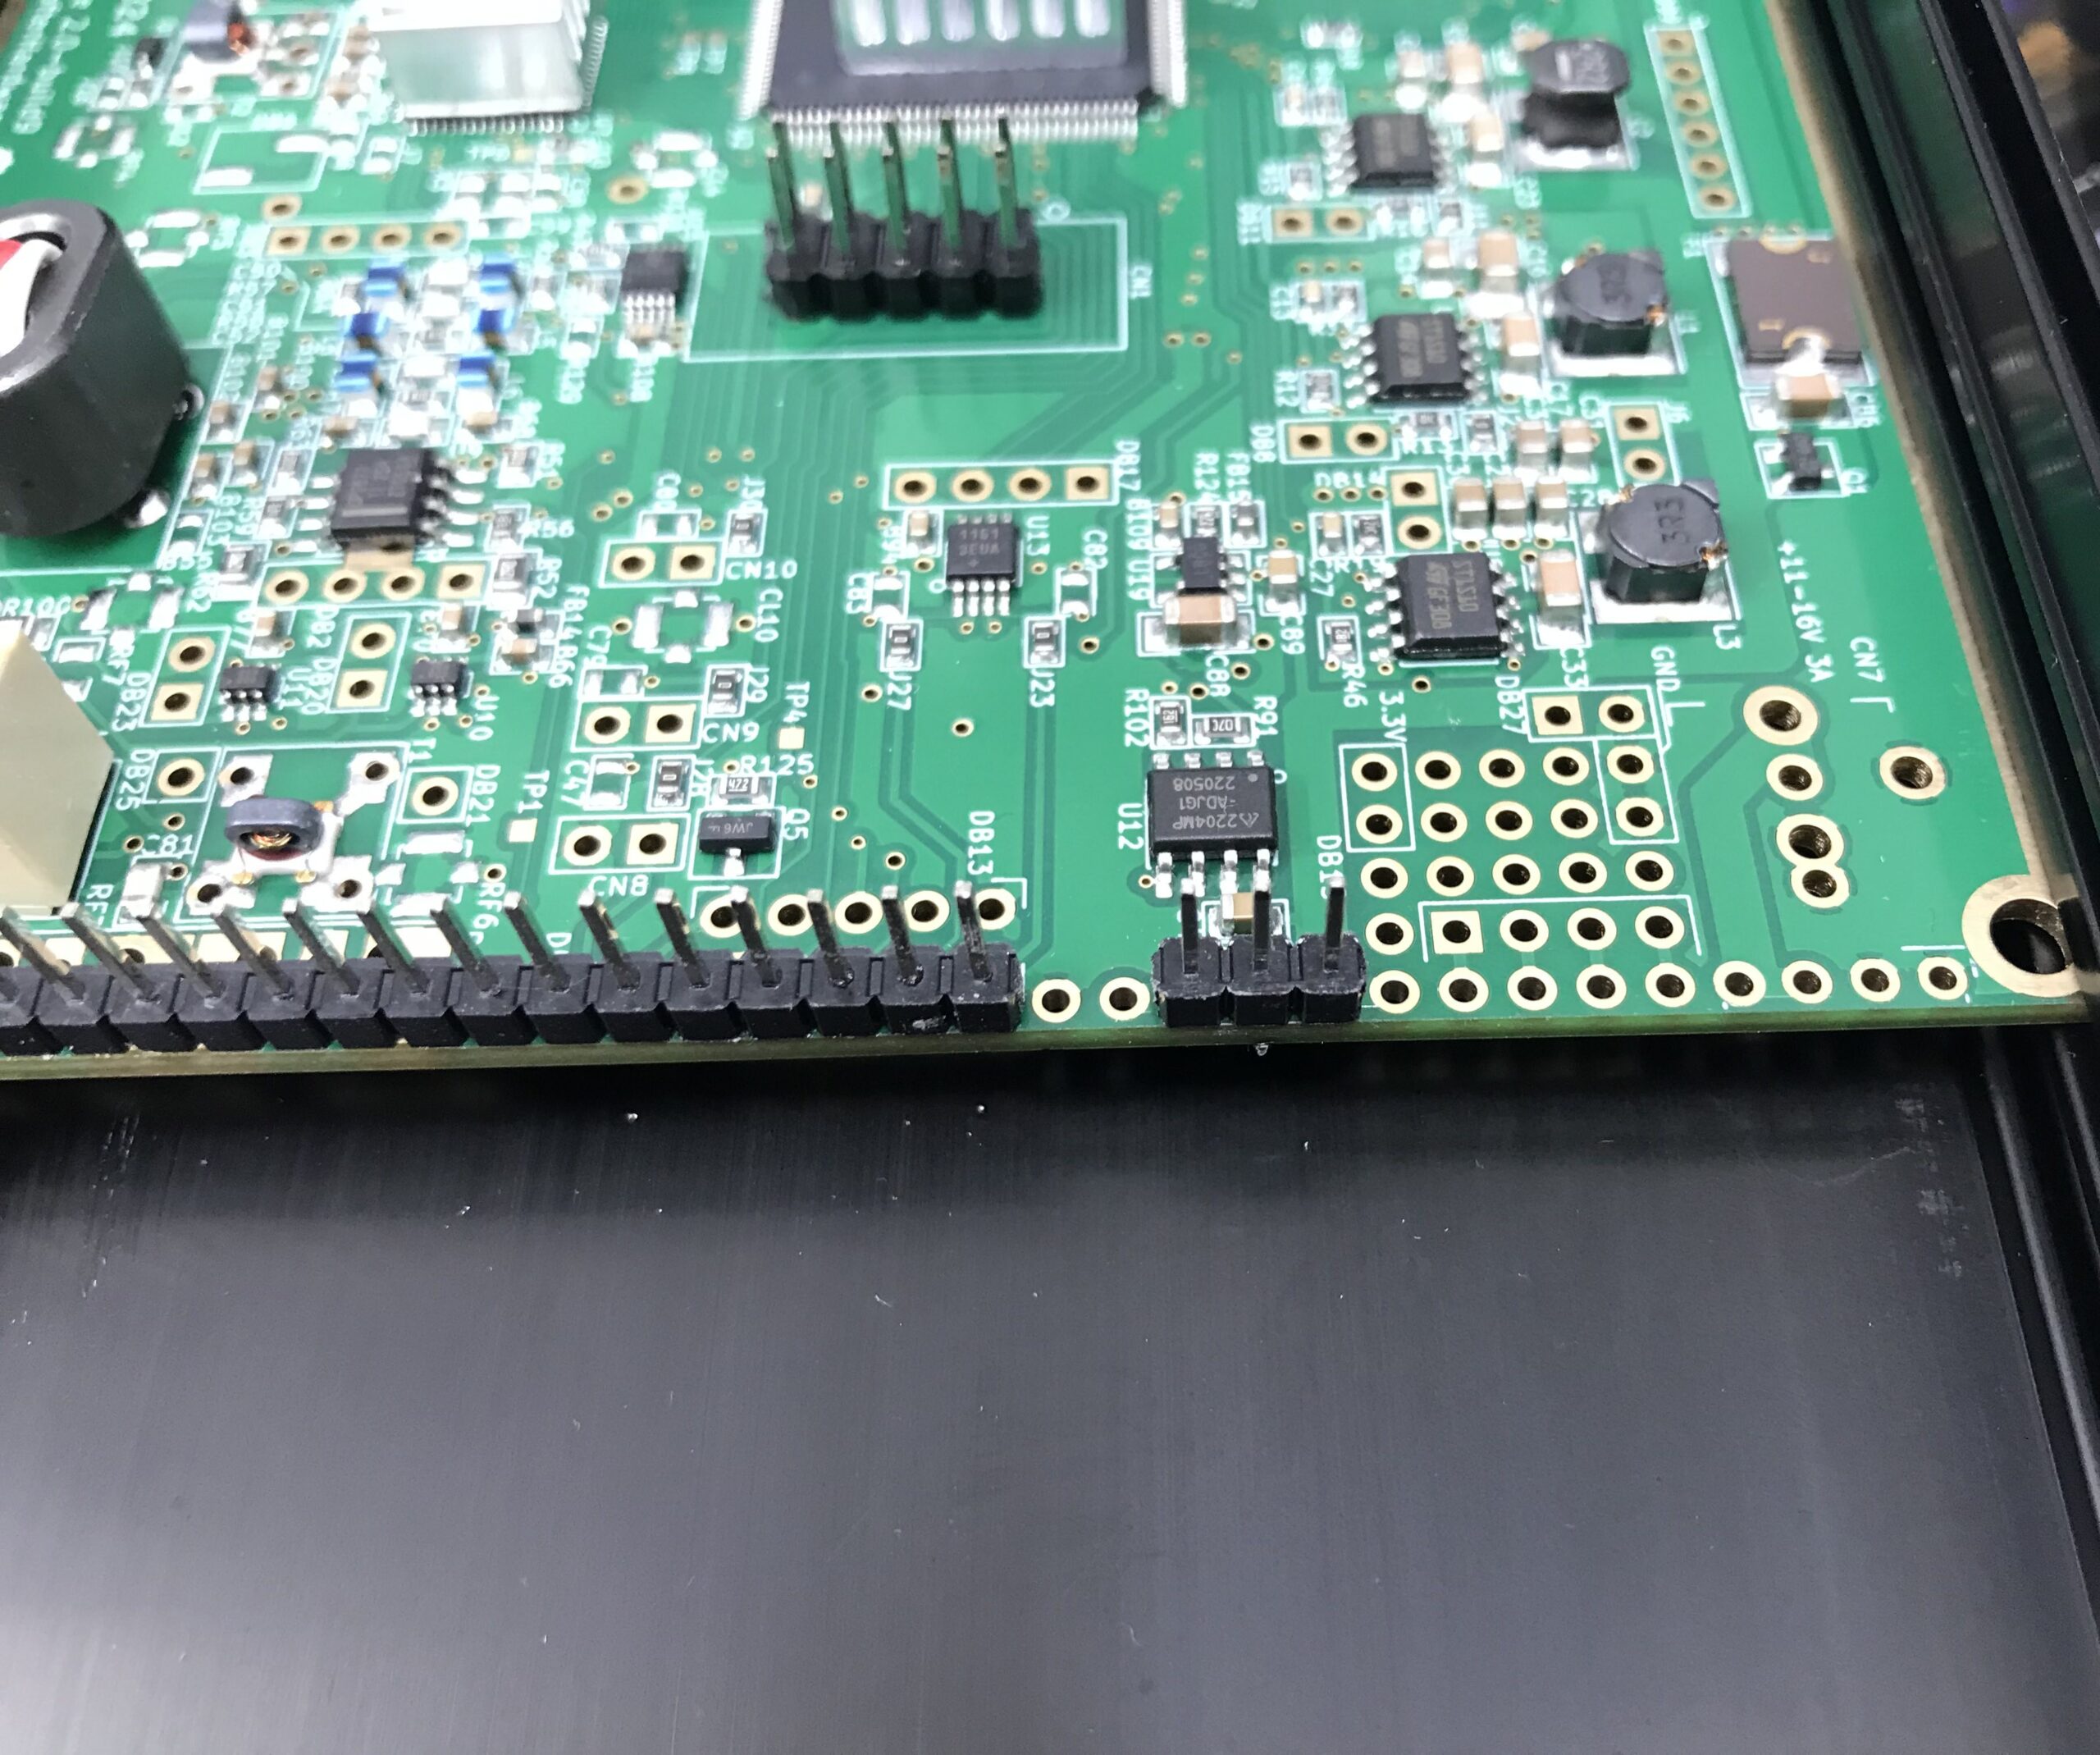
The I/O board gets its power feed directly from the HL2 main board however, the 3 pins it needs to connect to don’t have any headers in place and so, it’s necessary to solder a short row of 3 header pins onto the HL2 main board.
I found the easiest way to do this was to put the 3 header pins into the correct position and then use the HL2 to N2ADR filter board connector to hold them in place whilst soldering. This worked perfectly and I soon had the header pins soldered onto the main board.
Extra 3 header pins soldered to the main HL2 board
It’s important to note that the 3 extra header pins need to be placed 2 holes away from existing header pins as shown above. Take care to get these pins in the right position so as not to cause any damage to the 3 circuit boards once all are connected and powered up.
Note: The HL2 main board must be removed from the case to solder the extra 3 header pins in place. Take care to ensure the correct fitting of the PA heatsink when when refitting the HL2 main board into the case.
At this point I refitted the N2ADR Filter board back into the HL2 case so that the two sets of header pins aligned correctly ready for the placement of the new I/O board that would connect all 3 circuit boards together.
Preparing the N2ADR Filter board for reconnection
Once the filter board was in place I fitted the new I/O board taking care to ensure all pins aligned with the socket and then gently pushed it home.
Close up of the HL2 I/O board fitted to the main HL2 board and N2ADR Filter board
The close up of the I/O board connector above shows how the extra 3 header pins connect to the last 3 sockets in the I/O board connector. It’s a snug fit with the N2ADR filter board below it.
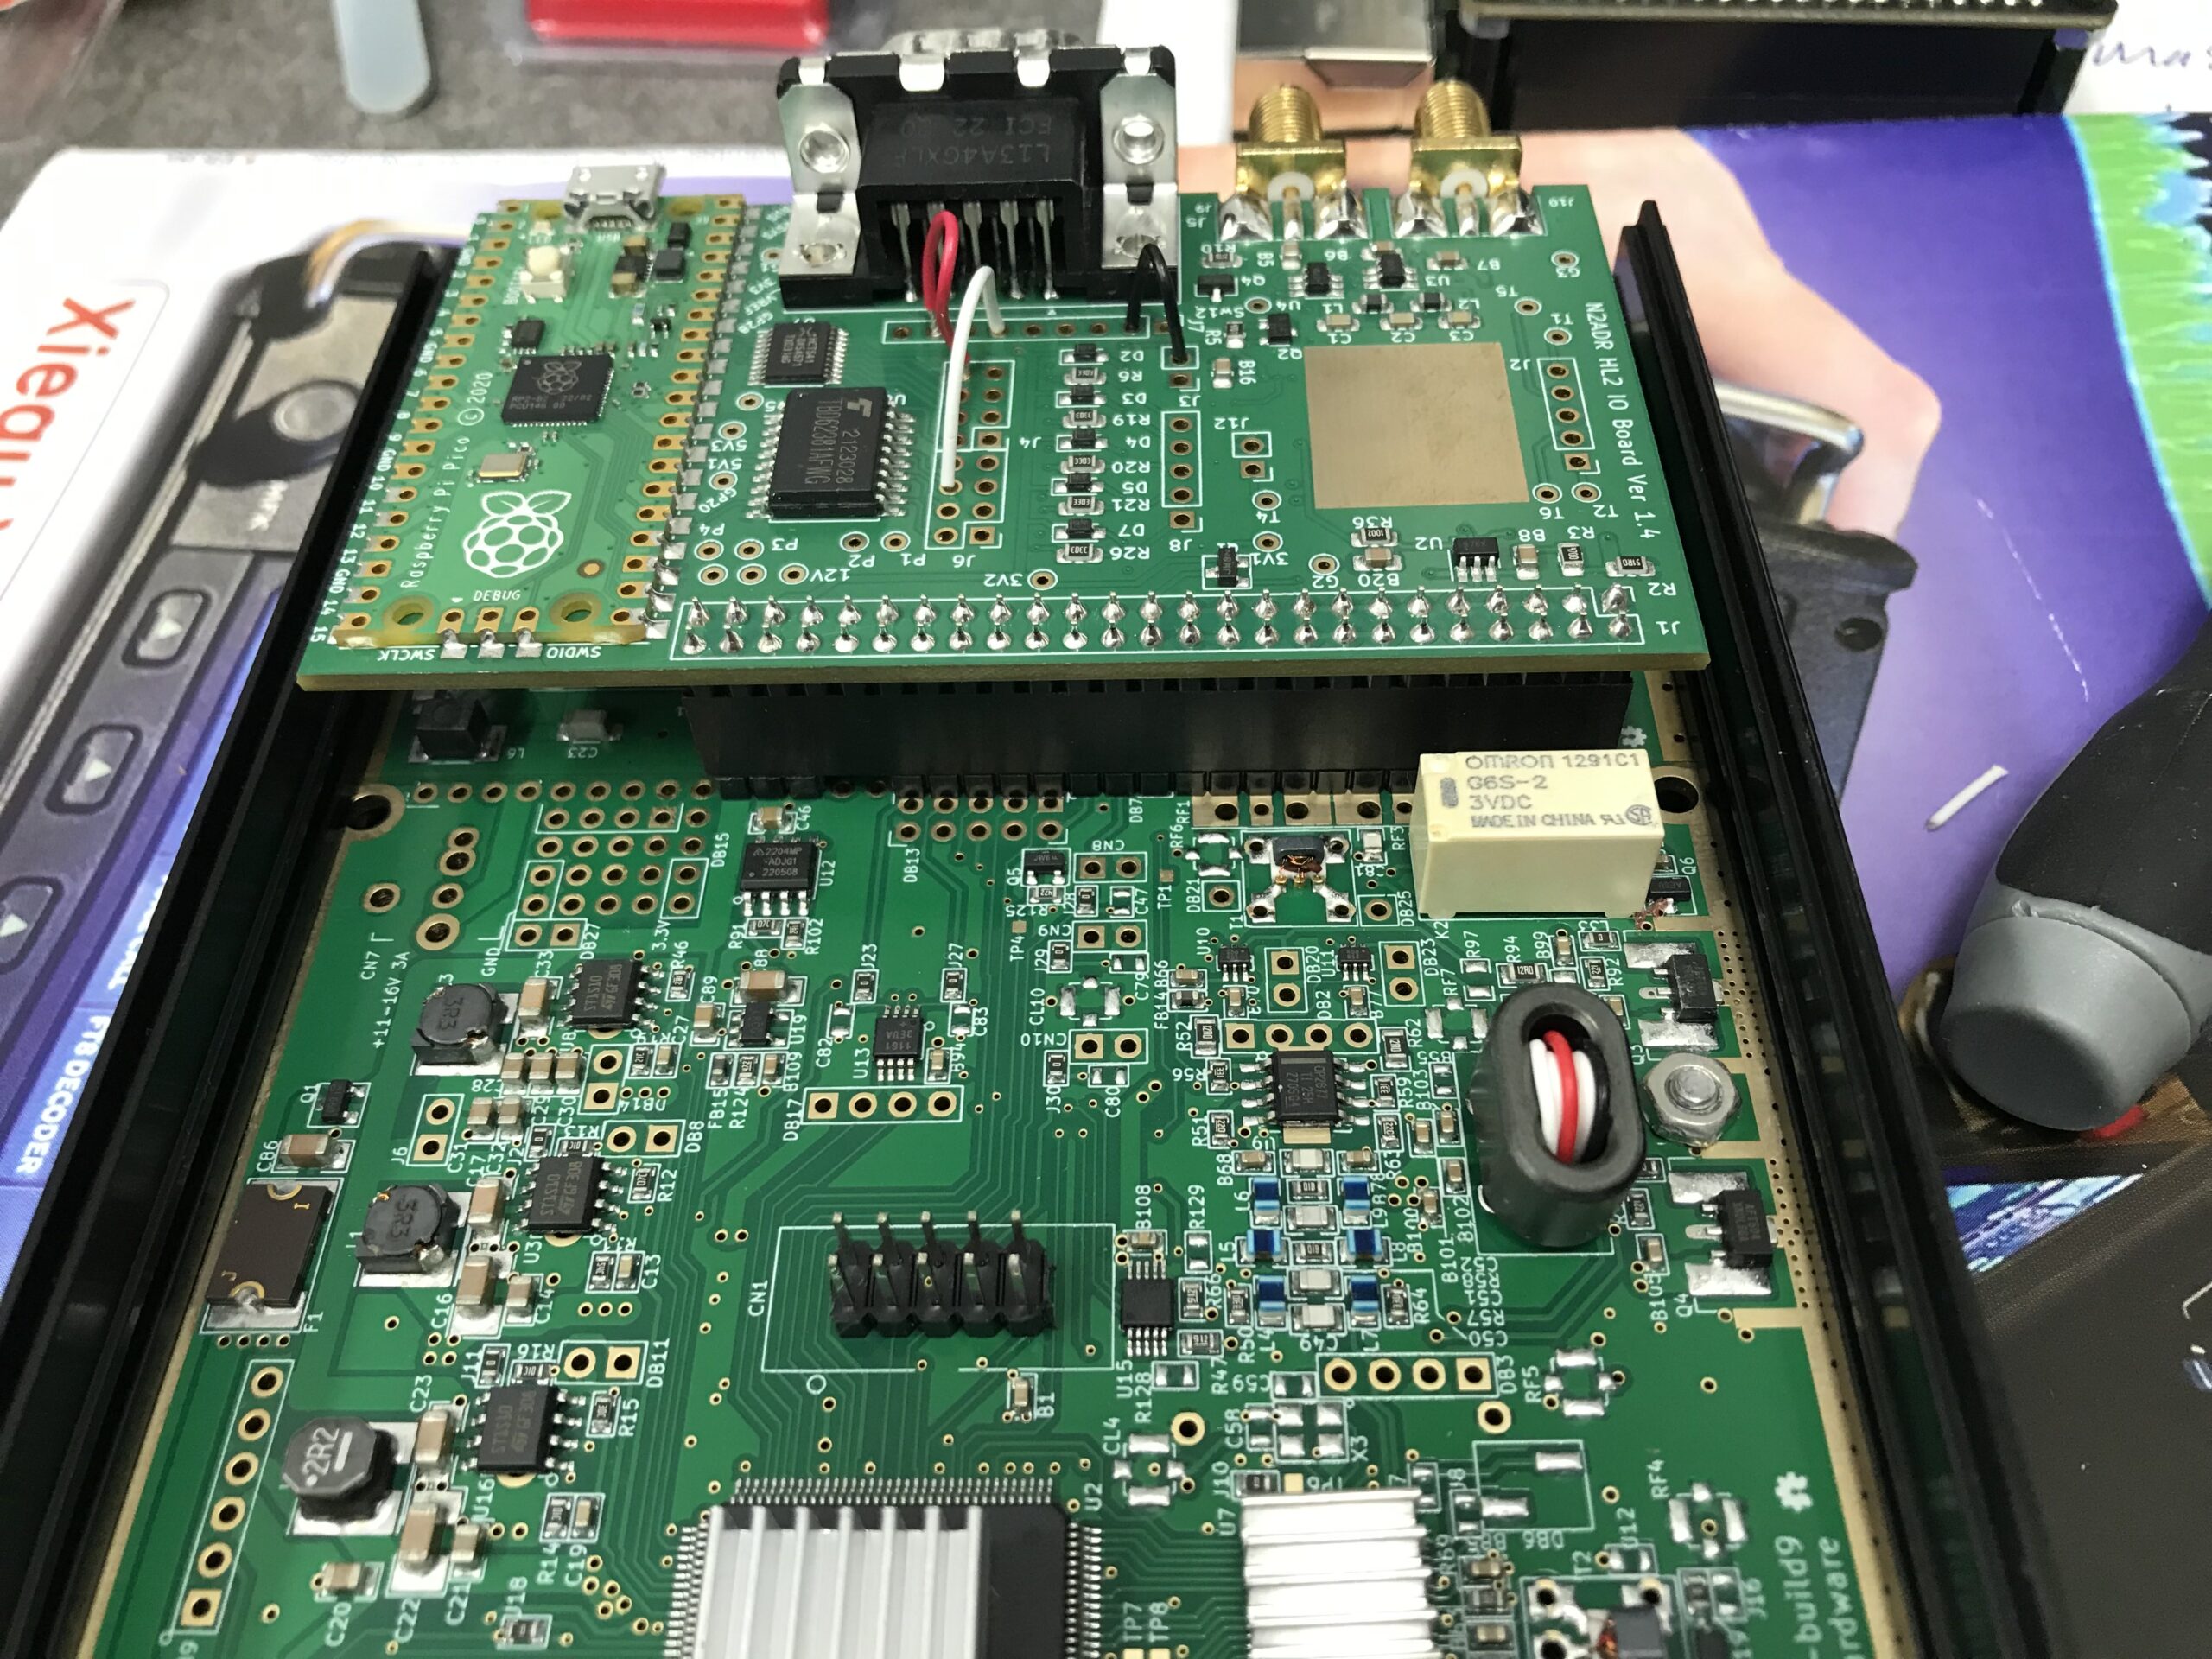
View of the fitted HL2 I/O board from above
Before the HL2 case can be put back together it’s necessary to load the software onto the RaspberryPi Pico (top left in photo above) that controls the I/O board.
This is accomplished by pressing the tiny button on the Pico whilst connecting a USB lead to the USB socket on the board that had already been plugged into my PC. Once connected the Pico appeared as a USB drive on my Kubuntu Linux desktop. All I then had to do was to copy the software file onto the drive. Once the software file is on the drive the Pico will reboot automatically and the little LED on the board will start to flash to show it has booted successfully. At this point I could safely unplug the USB cable.
The software for the RaspberryPi Pico is available for download below.
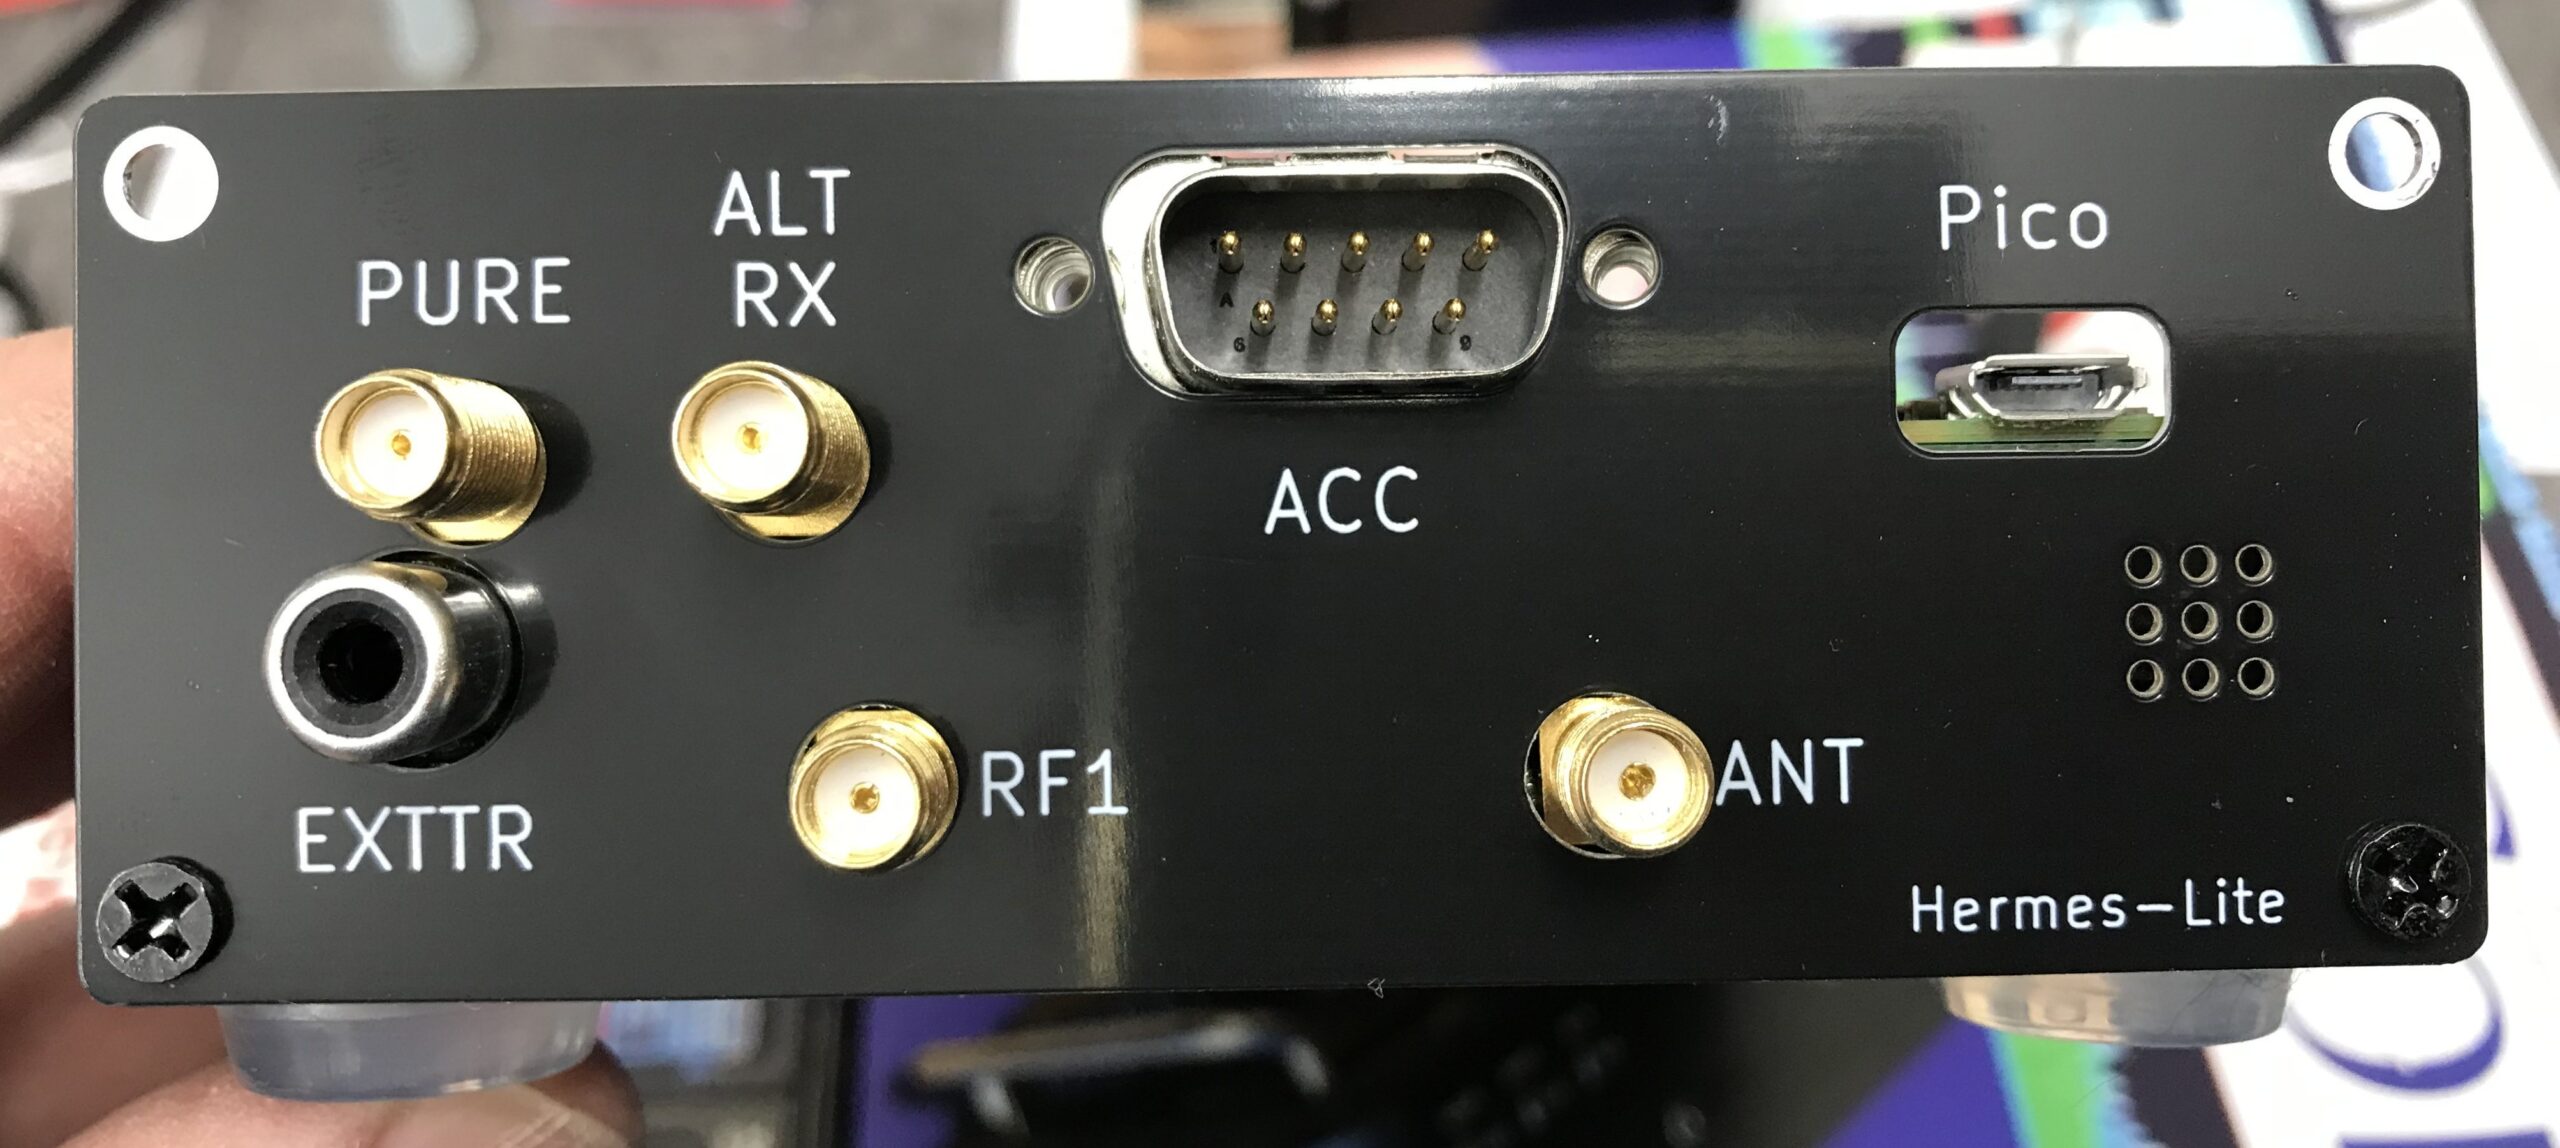
The I/O board comes with a new back panel for the HL2 to accommodate the extra connectors on the rear. Refit the top of the HL2 case and then attach the new rear panel using the original 4 counter sunk screws.
Supplied HL2 I/O board replacement rear panel fitted to the case
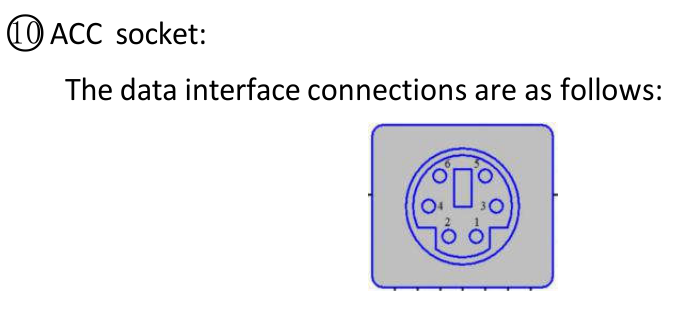
The final part of this project is to make the lead that will go from the HL2 rear DB9 ACC connector to the Xiegu XPA125B mini din ACC socket.
DB9 Pin 2 (BLACK) to Mini Din Pin 6 (GND)
DB9 Pin 6 (WHITE) to mini Din Pin 2 (PTT)
DB9 Pin 8 (RED) to Mini Din Pin 3 (Band Switching Voltage)
Below are a couple of screenshots from the Xiegu XPA125B user manual showing the Mini Din pin layout and the data interface connections for the amplifier.
Before I connected the lead to the two devices, I tested the end-to-end continuity of the lead to ensure all pins were correctly connected and that there were no shorts between any of the pins.
It’s important that the wires are connected to the correct pins on each end of the lead. Failure to ensure correct connection could cause damage to your HL2 and/or amplifier.
Once the lead had been tested, I connected it to both the Hermes Lite 2 and the Xiegu XPA125B amplifier. I also had to switch the amplifier band switching to AUTO.
Now when I change band on my HL2 in the PiHPSDR software the amplifier also changes band at the same time keeping the two devices in sync. No more manual band changing for me!
I hope this article is of use to other Hermes Lite 2 users who have purchased the Xiegu XPA125B but, have yet to setup auto band switching between the two devices.
Thanks to Steve, M0XVT for all the jumper information and the RaspberryPi Pico Software to get this all working.
UPDATE: The RaspberryPi Pico software originally came from Ramon, KP4RX. More information can found in this Google Groups article where he released the binary into the wild.
A full table of I/O resources available on the HL2 I/O board can be found on the KP4RX Guthub page.
The source code for the main.uf2 file above can be found at KP4RX.com
Regular readers of my blog will already know that I am a huge fan of the Linux operating system, it’s clearly evident in most of the content on this website.
I am also a very enthusiastic user of one of the first credit card sized computers that came to be, namely the RaspberryPi. I own all the iterations of this wonderful little computer from the very first version to the latest and greatest, RaspberryPi 5.
This little computer has done more for computing in education than Microsoft and Apple will ever achieve and it’s done it at an incredibly low price making it more accessible to schools, colleges and students than any other platform.
The RaspberryPi has what most consider to be the best support on the planet when it comes to single board computers (SBCs). From the dedicated team that build Raspberry Pi OS, to all the amazing projects and forums that are available, for free on the internet today.
The RaspberryPi computer really has revolutionised computing for the masses.
My RaspberryPi 5 that I am using to write this article.
Raspberry Pi OS really is very good. It’s based on the great Debian distro’ that many of us seasoned Linux users dearly love. It’s light weight, fast and meets the needs of everyone that is venturing into the exciting world of Linux and SBCs for the first time.
Overtime as we all become more experienced with Linux on the RaspberryPi we become more demanding and start to find the Raspberry Pi OS desktop environment lacking. Sure it can be enhanced by adding more and more to it however, it never quite reaches the point of satisfaction and we are always wishing for something more.
With the Pi-5, the latest iteration of this great credit card sized computer, users are now able to seriously think about building a more powerful desktop environment for their little berry flavoured computers.
On my desktop PCs dotted around the house I have used Kubuntu for decades. It’s a slick and powerful desktop environment that has met my needs for many years and I love it more than any other Linux desktop. Sadly Kubuntu isn’t easily available out the box for the RaspberryPi and so I decided that it was time to replicate it as closely as possible on my new, super powerful RaspberryPi 5.
When I ordered my RaspberryPi 5 from Pimoroni I added the NVMe base and 250GB M.2 SSD drive to the order. Up until now I’d always used SD cards however, they are slow and unreliable and so I decided that since the Pi-5 has PCIe it was time to take the step away from SD cards and start using SSD technology.
Getting the OS onto the SSD is a two stage affair. First you have to create a bootable SD card to boot the Pi-5 from and then use it via the RaspberryPi Imager to install the OS onto the SSD. It’s a bit long winded but, easy enough.
Since I’m a huge Kubuntu fan I decided my desktop of choice for my new Pi-5 was going to be KDE-Plasma. I had tried to install this desktop before on older model Pi’s however, it ran so slow that it was unusable. With the new Pi-5’s increased computing power and the speed of the SSD I was confident that this was now possible.
I started out installing the Lite version of Raspberry Pi OS on the SSD. This is a command line only version of Linux that doesn’t include any desktop environment, a nice clean slate to start from.
RaspberryPi Imager showing Pi OS Lite (64bit)
Once the Lite version of the OS was installed on the SSD I shutdown the Pi-5 and removed the SD card and then powered the Pi-5 back up again so that it booted from the SSD.
Upon booting I was presented with the simple Linux Login prompt. After entering my username and password as setup during OS install I landed at the Linux command prompt.
sudo su -
I used sudo to become root user as shown above and then set about building my new KDE based super computer. First I needed to update the operating system with all the latest patches and security fixes.
apt update && apt dist-upgrade
The update and upgrade process ran for a while but, it was soon complete.
reboot
I issued the reboot command and then logged back in again, I was now ready to start building the KDE desktop environment.
sudo su -
apt install kde-plasma-desktop gldriver-test
Becoming root again I type the command to install the KDE-Plasma desktop and the graphics-related config services. There’s a lot of packages to download and install so, I left it to do its thing.
A little while later all the packages were installed and ready to go. I now needed to tell the system to boot into the new graphical user interface instead of the command prompt using systemctl.
systemctl set-default graphical.target
Once this was done I needed to make a change to the display settings using the raspi-config program.
raspi-config
Selecting No.2 on the menu, Display Options and then D2 Screen Blanking, I disabled screen blanking so that I got the full 4K support for my KDE Desktop.
Once the system had been configured for a graphical user interface there was only one thing left to do and that was to shutdown the RaspberryPi.
shutdown -h now
The beautiful KDE-Plasma Desktop on RaspberryPi 5
Powering the Pi-5 back up again I was greeted by the standard KDE Plasma login screen and then, after logging in I was transported to the beautiful KDE desktop. I was now smiling like a Cheshire cat!
The KDE desktop is incredibly snappy on the Pi-5 with an SSD, app’s open instantly and run with minimum CPU exertion. It was now time to load the rest of the KDE application suite to complete the build. Popping open a terminal I hit the command line once more.
sudo su -
apt install kde-full vim yakuake vlc firefox rsyslog
This loads the full set of KDE applications adding just about everything you’ll ever need to the desktop environment. It’s about 1GB of packages and so depending on your internet speed it could take a while but, it’s well worth the wait.
Once complete you are ready to go with a fully functional, snappy, powerful desktop.
I’m extremely pleased with the performance of the Pi-5. KDE is super fast, snappy and responsive. With 8GB of RAM on tap the RaspberryPi has no problem with performance. The Pi-5 and KDE-Plasma really do make a great desktop computer at an incredible cheap price.
Looking for a new computer?
Add a cheap USB sound card and a pair of speakers and this little setup will meet the needs of 90% of the population with ease and go on to satisfy the more seasoned, demanding Linux user or programmer without breaking the bank.
More soon …
We use cookies to ensure that we give you the best experience on our website. If you continue to use this site we will assume that you are happy with it.