RaspberryPi computers are now moving into the realm of being powerful enough to replace the traditional desktop PC. My most recent purchase, a RaspberryPi 500+ is proof of this as it has been my daily desktop PC since it’s arrival.
One of the things I use heavily are virtual machines. They’re great for developing, prototyping and running new services. With the ability to snapshot, rollback and backup in an instant, virtualisation helps to reduce the development and test time for many of the programs and services that I’m playing with.
With RaspberryPi computers now supporting 16GB of RAM and M.2 SSD drives there is no reason for not taking advantage of virtualisation.
To this end I decided to test running some virtualised loads on my new 500+ with the plan to deploy to 16GB Pi5’s with SSD drives in place of more expensive Intel based computers.
On my Intel based machines I use QEMU, KVM and Virt-Manager to manage the multitude of virtual machines (VMs) I have running here. Since this is a solid, high performance platform for running VMs I decided to take the same route on the 500+
Installing the necessary packages is extremely simple, just one simple apt command:
# Main ethernet
# Setup Bridge called br1 on eth0
allow-hotplug eth0
iface eth0 inet manual
auto br1
iface br1 inet static
address 192.168.0.100
network 192.168.0.0
netmask 255.255.255.0
broadcast 192.168.0.255
gateway 192.168.0.1
dns-nameservers 192.168.0.5
bridge_ports eth0
bridge_stp off
#
#
Once this is done reboot your RaspberryPi and check you have access to your local LAN and of course the internet. You will now also inherit the two new groups that you added yourself to above.
Note: If you are using NetworkManager open the network settings app and create a bridge on eth0. You can also use the nmtui copmmandline app if you prefer.
At this point you’re ready to create your first virtual machine.
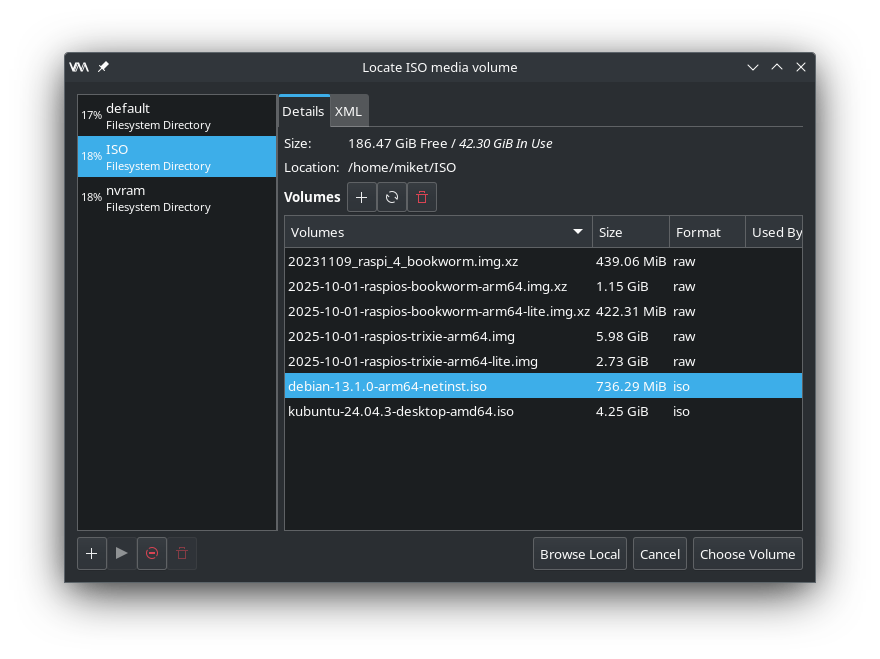
It’s important to have an arm64 version of Linux in ISO format that you can use to install into your VM. My preferred distro is Debian and so I downloaded the Debian 13 Arm64 netinst ISO from the debian.org website.
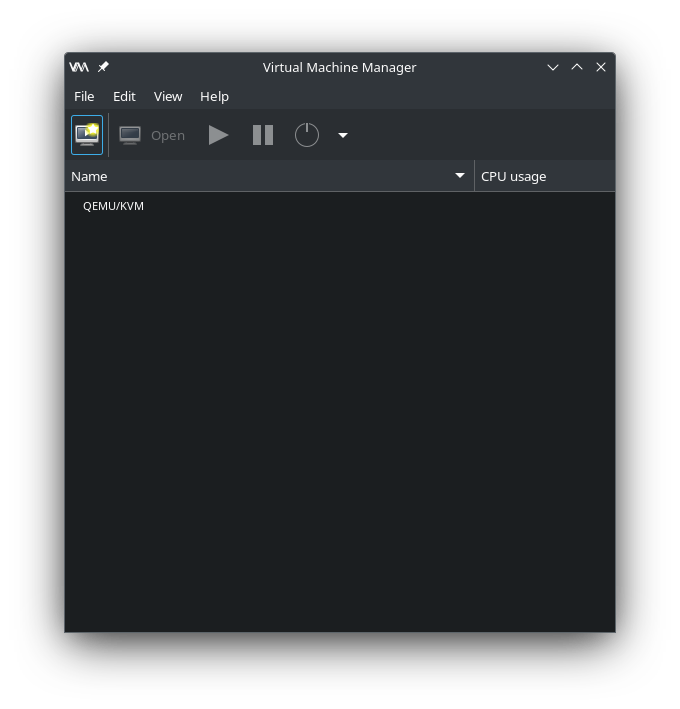
From the main menu start “Virtual machine Manager” or on the commandline type:
virt-manager
QEMU Virtual Machine Manager
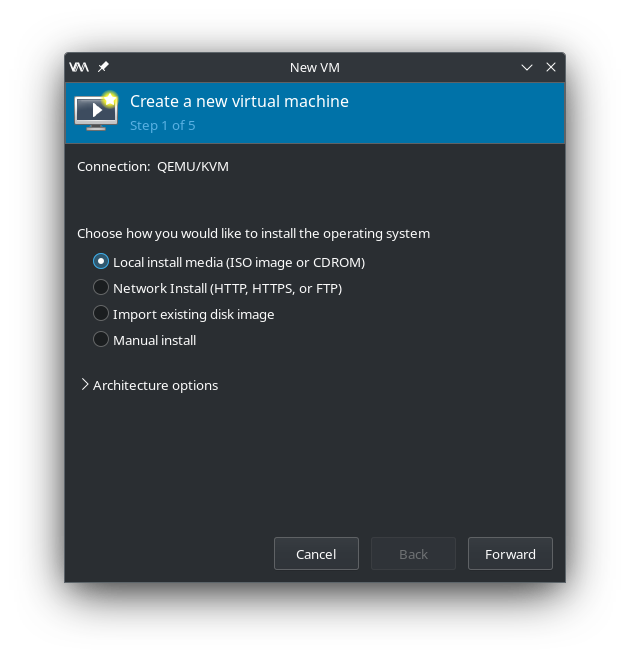
Click the Create new VM button and then navigate to where you saved your ISO file and select it as the installation media.
Virtual Machine Manager – Local install mediaVirtual Machine Manager – Select ISO file
Once you’ve chosen your ISO you’ll need to configure the actual VM. Start by setting the amount of RAM and number of virtual CPUs you want the VM to have.
Virtual Machine Manager – Configure RAM and CPU
Next set the size of the virtual disk that the VM will use.
Virtual Machine Manager – Create virtual disk
Finally, give the VM a name and set its network device to br0 as created above. Click finish and your VM will boot.
Virtual Machine Manager – Name VM and select bridge interface
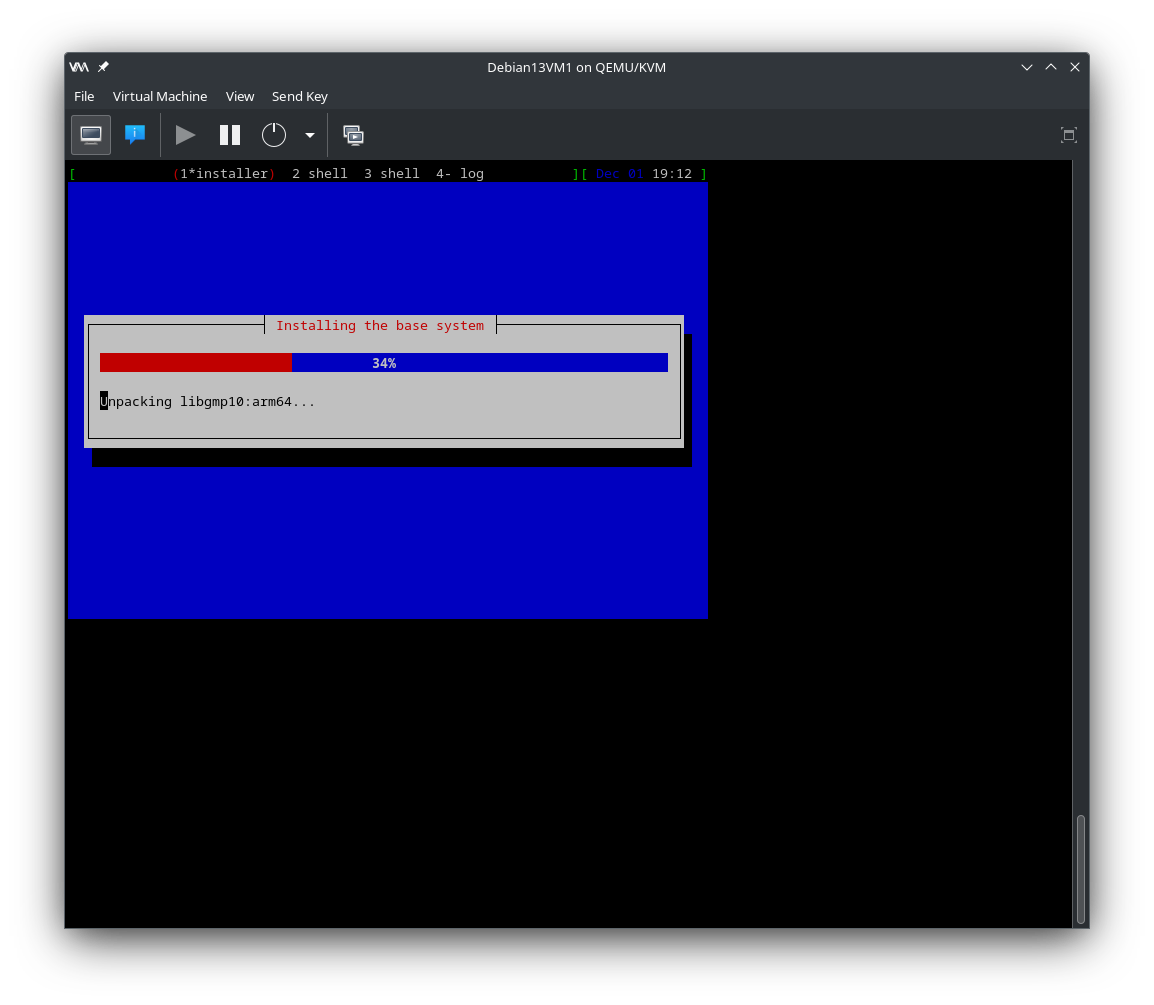
Now it’s just a case of going through the standard Debian install process to build your Debian VM.
Once the installation is complete and the VM has rebooted you will have a functional Debian computer ready to use for whatever you like, just like a physical PC but, in virtual form. You’ll find that the VM runs as fast as the actual physical machine thanks to the kernel based virtualisation.
Since RaspberryPi are now forcing users of its SBC to use RaspberryPi OS 13 (via the RaspberryPi Imager tool) instead of the reliably stable Debian 11 or 12 several issues have come to light.
Firstly if like me you run most of the your Pi4/5 SBCs headless/lights out you’ll notice that networking is now ridiculously managed via Network Manager and Netplan.
This is a ridiculous method of managing such a simple device, it’s over complicated, messy and ill thought out. Yet another classic example of change for the sake of change and not to actually improve things.
This combination of Network Manager (often referred to as Network Mangler for good reason) and Netplan is fraught with bugs. Try setting a second IP address on an interface and you’ll find it doesn’t work. nmtui will show the ip address as being configured however, netplan never actually puts the config into play.
Having to use nmtui on the command line to manage ethernet interfaces is also ridiculous. Its badly laid out menu system takes an age to get through to do the simplest of config changes. What’s wrong with just editing the /etc/network/interfaces file?
After much frustration trying to configure the ethernet interface on my headless Pi5 I decided to get rid of this hideous method of managing ethernet interfaces and put it back to using the simple interfaces file.
I’ve documented the steps just in case anyone else wants to do the same.
Step 1: Make sure the traditional networking stack is installed:
# Example /etc/network/interfaces for Ethernet (eth0) with static IP:
#
# Loopback
auto lo
iface lo inet loopback

# Ethernet
auto eth0
iface eth0 inet static
    address 192.168.1.10
    netmask 255.255.255.0
    gateway 192.168.1.1
    dns-nameservers 1.1.1.1 8.8.8.8
Example for DHCP:
auto eth0
iface eth0 inet dhcp
If you use Wi-Fi:
auto wlan0
iface wlan0 inet dhcp
    wpa-ssid "YourSSID"
    wpa-psk "YourPassword"
Step 5 – Enable the traditional networking service
The /etc/network/interfaces method works perfectly on Pi 5 and is lighter weight and ideal for embedded or headless servers.
If you later reinstall NetworkManager, it will override interfaces again unless you mark them as unmanaged in /etc/NetworkManager/NetworkManager.conf.
You can still use ifup / ifdown commands manually for control.
You now have your Pi running the classic, lightweight networking stack which is ideal if you use your Pi as a 24/7 server like I do.
Note: This method is still supported on RaspberryPi Debian 13 but, it’s no longer the default.
As a final note, if you want to add a second IP Address to your Ethernet interface it’s extremely simple to define in the /etc/network/interfaces file. I’ve created an example of how to do this below for reference.
# Loopback
auto lo
iface lo inet loopback

#
# Primary interface - static IP
#
auto eth0
iface eth0 inet static
    address 192.168.1.10
    netmask 255.255.255.0
    gateway 192.168.1.1
    dns-nameservers 1.1.1.1 8.8.8.8

#
# Secondary IP on same interface
#
auto eth0:1
iface eth0:1 inet static
    address 192.168.1.11
    netmask 255.255.255.0
Check both IP Addresses appear on the same interface:
ip a show eth0
For the example above you’ll see:
inet 192.168.1.10/24
inet 192.168.1.11/24
Finally, if like me you use lm-sensors to keep check on how hot your Pi is running you’ll find that the sensors command no longer works, it just throws a segmentation fault. This is a nuisance as I use this as part of my Node-Red Monitoring Dashboard.
A partial work around is to use the vcgencmd command as it can return the temperature of the system on a chip (SOC) device.
vcgencmd measure_temp
You can create an alias for this command in your ~/.profile file, I’ve named the alias ‘cputemp’ in this example:
alias cputemp="vcgencmd measure_temp"
Once you’ve saved your .profile file logout and back in again and you’ll now have a new command to use to get the CPU temp.
As I detailed in my QO-100 Satellite Ground Station Complete Build article I use a Griffin Powermate VFO knob to control the receive VFO frequency when in split mode or needing to RIT a DX station to get on frequency with them. Since building the ground station this setup has worked perfectly and without error however, for the last couple of days every time I start my Kubuntu Linux PC the USB VFO knob appears on a different USB event queue.
For the last two years the VFO knob has always appeared on /dev/input/event11 but, after connecting a Pluto+ SDR transceiver to the PC via USB the VFO knob now appears randomly on the /dev/input/events tree. This normally doesn’t cause any problems but, my Node-Red QO-100 Ground Station Control Dashboard expects the device to always be on /dev/input/event11.
Griffin Technology Powermate VFO
Initially I tried to find a way to lock the USB VFO knob to /dev/input/event11 however, there doesn’t appear to be a way to do this as the event tree is built at boot time by udev.
Digging deeper into udev I discovered that it’s possible to create a udev rule that is read at boot time, that will search for the device and then create a symlink to it with the same name each time making the USB VFO Knob appear as if it’s always in the same place. This is exactly what I need so I set about writing the udev rule.
To find out what event the USB VFO knob is currently on I ran evtest on the Linux command-line and got the following output.
No device specified, trying to scan all of /dev/input/event*
Available devices:
/dev/input/event0:      Sleep Button
/dev/input/event1:      Power Button
/dev/input/event2:      Power Button
/dev/input/event3:      Video Bus
/dev/input/event4:      Telink Wireless Receiver Mouse
/dev/input/event5:      Telink Wireless Receiver Consumer Control
/dev/input/event6:      Telink Wireless Receiver System Control
/dev/input/event7:      Telink Wireless Receiver
/dev/input/event8:      Kensington USB/PS2 Orbit
/dev/input/event9:      PixArt USB Optical Mouse
/dev/input/event10:     USB PnP Audio Device
/dev/input/event11:     HDA Intel PCH Front Mic
/dev/input/event12:     HDA Intel PCH Rear Mic
/dev/input/event13:     HDA Intel PCH Line
/dev/input/event14:     HDA Intel PCH Line Out Front
/dev/input/event15:     HDA Intel PCH Line Out Surround
/dev/input/event16:     HDA Intel PCH Line Out CLFE
/dev/input/event17:     HDA Intel PCH Line Out Side
/dev/input/event18:     HDA Intel PCH Front Headphone
/dev/input/event19:     HDA Intel PCH HDMI/DP,pcm=3
/dev/input/event20:     HDA Intel PCH HDMI/DP,pcm=7
/dev/input/event21:     HDA Intel PCH HDMI/DP,pcm=8
/dev/input/event22:     HDA Intel PCH HDMI/DP,pcm=9
/dev/input/event23:     HDA Intel PCH HDMI/DP,pcm=10
/dev/input/event24:     Griffin PowerMate
/dev/input/event25:     Realtek RTL2832U reference design
This shows that currently the Griffin Powermate VFO knob is on event 24.
Having this information I now needed to use the udevadm command to obtain the Vendor and Product ID of the USB VFO knob.
udevadm info -a /dev/input/event24
This returns a lot of information about the USB device, more than I was expecting but, upon close inspection I found the Vendor and Product IDs.
Note: That should all be on one line in the file not wrapped as shown above.
This one line rule sets the subsystem to input events, sets the Product and Vendor IDs to that of the Griffin Powermate USB VFO knob and then creates the symlink /dev/powermate
Once I’d completed the rule, I saved the file and exited the vi text editor.
Next I needed to use udevadm to get it to re-read the udev rules as if it were boot time and check that it created the symlink.
udevadm control -R
Once the udevadm command completed I used the ls command to see if the symlink had been created.
As shown above the symlink had been created and I could now enter /dev/powermate into my Node-Red code so that it always finds the VFO knob regardless of what event number it appears on.
Just to make sure it worked correctly at boot time, I shutdown my Kubuntu linux PC and started it from a cold boot. Sure enough the /dev/powermate symlink was created and pointed to the new event number in the /dev/input tree, problem solved!
I hope this information is useful to Linux users especially as it can be used for any USB input device.
It’s worth noting that you will need to be root user to run most of the commands or use sudo from your regular user account.
Over the last few weeks I’ve been working on my install-pihpsdr script to build a version of the DL1YCF PiHPSDR fork that will work with the Adalm Pluo, Pluto+ and LibreSDR transceivers.
Since I don’t own any of these devices, Steve M0XVT has loaned me his Adalm Pluto and LibreSDR devices to test with.
Initially neither of the devices would work with the PiHPSDR build that my script was creating. After some investigation I found this was due to the fact that the developer build script was only building the SOAPYSDR library, it wasn’t building the modules for each device type.
This was easily fixed by adding some extra code that would build the necessary SOAPYSDR modules so that the devices were discovered on the local LAN.
Since I had the devices to hand I took the opportunity to test the updated build script on a number of Linux Distro’s that I have to hand.
PiHPSDR running on Linuxmint 22.1 Cinnamon Edition using the LibreSDR transceiver
I tested the updated build script on Kubuntu 22.04LTS, Linuxmint 22.1 Cinnamon Edition and RaspberryPi 4/5 running the latest RaspberryPi OS 64bit version.
These all worked great with the transceivers and will now make a great platform for QO-100 stations that use either the Adalm Pluto, Pluto+ or LibreSDR devices.
Of course this build of PiHPSDR will also work with the Hermes Lite 2 and RadioBerry devices that I use most of the time in my own radio shack.
The updated PiHPSDR install script can be downloaded from my original blog article on the subject that is located here: https://m0aws.co.uk/?p=3686
The updated build script will most likely work on most Debian based Linux distro’s and build a working version of PiHPSDR. If you find a distro where you have problems please email me and let me know the details and I’ll happily look at the issue and try to resolve it.
Thanks to Steve for the loan of his precious SDR transceivers, I had a lot of fun with them!
Regular readers of my blog will already know that I am a huge fan of the Linux operating system, it’s clearly evident in most of the content on this website.
I am also a very enthusiastic user of one of the first credit card sized computers that came to be, namely the RaspberryPi. I own all the iterations of this wonderful little computer from the very first version to the latest and greatest, RaspberryPi 5.
This little computer has done more for computing in education than Microsoft and Apple will ever achieve and it’s done it at an incredibly low price making it more accessible to schools, colleges and students than any other platform.
The RaspberryPi has what most consider to be the best support on the planet when it comes to single board computers (SBCs). From the dedicated team that build Raspberry Pi OS, to all the amazing projects and forums that are available, for free on the internet today.
The RaspberryPi computer really has revolutionised computing for the masses.
My RaspberryPi 5 that I am using to write this article.
Raspberry Pi OS really is very good. It’s based on the great Debian distro’ that many of us seasoned Linux users dearly love. It’s light weight, fast and meets the needs of everyone that is venturing into the exciting world of Linux and SBCs for the first time.
Overtime as we all become more experienced with Linux on the RaspberryPi we become more demanding and start to find the Raspberry Pi OS desktop environment lacking. Sure it can be enhanced by adding more and more to it however, it never quite reaches the point of satisfaction and we are always wishing for something more.
With the Pi-5, the latest iteration of this great credit card sized computer, users are now able to seriously think about building a more powerful desktop environment for their little berry flavoured computers.
On my desktop PCs dotted around the house I have used Kubuntu for decades. It’s a slick and powerful desktop environment that has met my needs for many years and I love it more than any other Linux desktop. Sadly Kubuntu isn’t easily available out the box for the RaspberryPi and so I decided that it was time to replicate it as closely as possible on my new, super powerful RaspberryPi 5.
When I ordered my RaspberryPi 5 from Pimoroni I added the NVMe base and 250GB M.2 SSD drive to the order. Up until now I’d always used SD cards however, they are slow and unreliable and so I decided that since the Pi-5 has PCIe it was time to take the step away from SD cards and start using SSD technology.
Getting the OS onto the SSD is a two stage affair. First you have to create a bootable SD card to boot the Pi-5 from and then use it via the RaspberryPi Imager to install the OS onto the SSD. It’s a bit long winded but, easy enough.
Since I’m a huge Kubuntu fan I decided my desktop of choice for my new Pi-5 was going to be KDE-Plasma. I had tried to install this desktop before on older model Pi’s however, it ran so slow that it was unusable. With the new Pi-5’s increased computing power and the speed of the SSD I was confident that this was now possible.
I started out installing the Lite version of Raspberry Pi OS on the SSD. This is a command line only version of Linux that doesn’t include any desktop environment, a nice clean slate to start from.
RaspberryPi Imager showing Pi OS Lite (64bit)
Once the Lite version of the OS was installed on the SSD I shutdown the Pi-5 and removed the SD card and then powered the Pi-5 back up again so that it booted from the SSD.
Upon booting I was presented with the simple Linux Login prompt. After entering my username and password as setup during OS install I landed at the Linux command prompt.
sudo su -
I used sudo to become root user as shown above and then set about building my new KDE based super computer. First I needed to update the operating system with all the latest patches and security fixes.
apt update && apt dist-upgrade
The update and upgrade process ran for a while but, it was soon complete.
reboot
I issued the reboot command and then logged back in again, I was now ready to start building the KDE desktop environment.
sudo su -
apt install kde-plasma-desktop gldriver-test
Becoming root again I type the command to install the KDE-Plasma desktop and the graphics-related config services. There’s a lot of packages to download and install so, I left it to do its thing.
A little while later all the packages were installed and ready to go. I now needed to tell the system to boot into the new graphical user interface instead of the command prompt using systemctl.
systemctl set-default graphical.target
Once this was done I needed to make a change to the display settings using the raspi-config program.
raspi-config
Selecting No.2 on the menu, Display Options and then D2 Screen Blanking, I disabled screen blanking so that I got the full 4K support for my KDE Desktop.
Once the system had been configured for a graphical user interface there was only one thing left to do and that was to shutdown the RaspberryPi.
shutdown -h now
The beautiful KDE-Plasma Desktop on RaspberryPi 5
Powering the Pi-5 back up again I was greeted by the standard KDE Plasma login screen and then, after logging in I was transported to the beautiful KDE desktop. I was now smiling like a Cheshire cat!
The KDE desktop is incredibly snappy on the Pi-5 with an SSD, app’s open instantly and run with minimum CPU exertion. It was now time to load the rest of the KDE application suite to complete the build. Popping open a terminal I hit the command line once more.
sudo su -
apt install kde-full vim yakuake vlc firefox rsyslog
This loads the full set of KDE applications adding just about everything you’ll ever need to the desktop environment. It’s about 1GB of packages and so depending on your internet speed it could take a while but, it’s well worth the wait.
Once complete you are ready to go with a fully functional, snappy, powerful desktop.
I’m extremely pleased with the performance of the Pi-5. KDE is super fast, snappy and responsive. With 8GB of RAM on tap the RaspberryPi has no problem with performance. The Pi-5 and KDE-Plasma really do make a great desktop computer at an incredible cheap price.
Looking for a new computer?
Add a cheap USB sound card and a pair of speakers and this little setup will meet the needs of 90% of the population with ease and go on to satisfy the more seasoned, demanding Linux user or programmer without breaking the bank.
(This information is also for the Hermes Lite 2, Adalm Pluto, Pluto+ and LibreSDR)
During my RadioBerry build I started out using the version of PiHPSDR that was created just for the RadioBerry. The problem with this is that it is hard coded for a very small screen making it hard to use on a big screen since the user cannot resize the window dynamically.
I decided to look for a forked version of the PiHPSDR software that had the ability to change the window size to suit all use cases. During my search I stumbled across the DL1YCF fork of the source code that has some enhancements, one of which is the ability to change the display size.
In no time at all I had the source code downloaded and compiled only to find that it didn’t work with the RadioBerry. After some investigation I found that this was due to the fact that the RadioBerry software has compiled into it code that is used to access the GPIO pins on the RaspberryPi so that it can communicate with the RadioBerry HAT. This is fine except that the DL1YCF version of PiHPSDR also has code in it to use the GPIO pins. This of course causes a conflict and the net result is that nothing works.
Reading through the source code and Makefile I found that all I needed to do was to compile a version of PiHPSDR without GPIO support. This would then remove the conflict and allow the RadioBerry software to operate correctly.
To this end I put together a download/compile/install script for the DL1YCF version of PiHPSDR that will work on a RaspberryPi with a RadioBerry HAT and give the ability to resize the window to fit any size screen.
The script also works on a Linux Desktop PC running Ubuntu/Kubuntu/Linuxmint/Debian operating systems. (It will most likely work on other distro’s too but, these are all I have to hand currently). You can of course also use this software with a Hermes Lite 2 transceiver.
DL1YCF PiHPSDR running on RaspberryPi 4 with RadioBerry HAT on a large monitor
To install this enhanced version of PiHPSDR on your RaspberryPi/Desktop PC with GPIO support disabled, download the installation script below, unzip it and run it in a terminal on your RaspberryPi/Desktop PC in your home directory. (/home/<your-username>).
The script will download the latest source code from the DL1YCF github, disable the GPIO code and then compile and install it to your computer. If installing on a RaspberryPi it will create an icon on the desktop for you to use to start the software.
If installing on a PC then you will need to create your own desktop icon as the one created only works on a RaspberryPi. You can of course just start the software from the command line in a terminal. (My preferred method).
If you have a RaspberryPi 5 then I highly recommend that you run this version of PiHPSDR on it as it has a lot more computing power and handles using dual receive with ease. It will run on a Pi4 but, you will load the CPU more as it’s not as powerful as the later model Pi5.
The script will ask if you want to compile in SOAPYSDR support so that PiHPSDR will work with RTL-SDR, Adalm-Pluto, Pluto+ and LibreSDR. Enter Y to compile in support or N if you don’t need it.
I’ve been working on squashing some bugs in my Node-RED AllStarLink Control Dashboard with the help of Steve, M0XVT which has resulted in a new version of the flow now being available for download below.
If you’re reading this and aren’t too sure what it is all about then, have a look at my original article detailing the Node-RED AllStarLink Control Dashboard that I developed and wrote about back in September 2024 and hopefully it’ll all make sense.
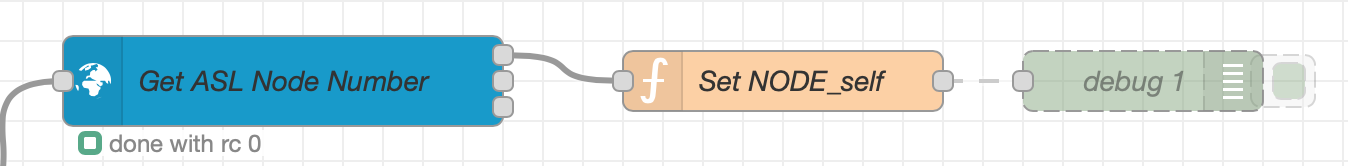
This new version of the flow resolves an issue whereby the dashboard used an incorrect node number for the node it connects to resulting in it not working unless a piece of code was changed. The update was a simple change to add a couple of nodes that connect to the RaspberryPi and read the Asterisk/AllStarLink node number from the asterisk configuration files at startup.
Node-RED AllStarLink Control Dashboard v1.2 additional sub flow
I also fixed another bug whereby the buttons could show a false connect on a button when the user connects to another node via AllMon2/Supermon instead.
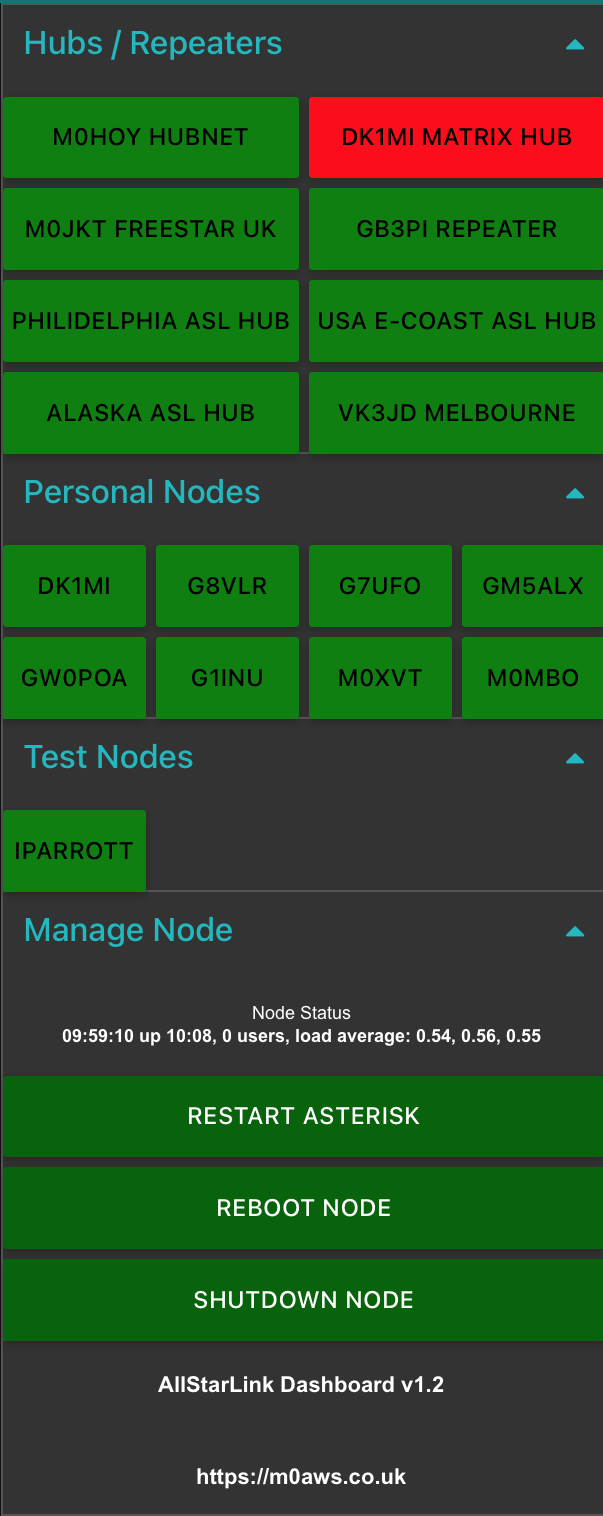
This flow no longer has the blue spare button as it now connects to a node in Melbourne Australia.
Node-RED AllStarLink Control Dashboard v1.2
You can download the new, v1.2 updated flow below and import it to your Node-RED flow editor using the standard import tool from the burger menu in the flow editor.
Ever since we moved into the village of Eyke we’ve suffered with power cuts and power surges. It’s been that bad that we have a number of uninterruptible power supplies (UPS) dotted around the house to keep important things running when the power goes out.
Of late it’s been getting worse, not just the power cuts but, the power bouncing on and off very quickly for period of 10-15secs when the power comes back on. Unfortunately we had a particularly bad power bounce when the power came back on and it killed the main UPS for the IT equipment rack and also took out my RAID storage array that I use for backups.
On top of this the main server computer also took a hit and its solid state (SSD) drives started to fail. This left me in a position where I had no backups to recover from and had to get all the data off the running virtual machines (VMs) before the SSDs failed.
My old server that I decommissioned some months ago was now my radio shack PC and so had a desktop operating system on it and lots of HAM radio software installed and configured but, I needed to press it back into service as a server again, very quickly!
So after backing up the desktop data I rebuilt the computer as a server again and began the tedious job of building new VMs and migrating the configuration and data over from the old VMs.
You’re probably wondering why I didn’t just transfer the VMs over hole to the replacement server? To do this I’d need to shut them down to get a clean snapshot however, when I tried it with a small, unimportant VM it became corrupt during the shutdown process and could no longer be transferred to the replacement server.
Not wanting to take the risk with any of the other VMs due to having lost all the backups, I decided to replicate all the VMs manually. Needless to say this isn’t a 5min job!
So, after a rather long week rebuilding everything I now have all the services up and running on the replacement server and the damaged server ready to be stripped down to an empty case and rebuilt from scratch.
This has meant that at times my M0AWS Blog, The Matrix server and other online services have been offline for short periods but, sadly there was nothing I could do about it. Unfortunately the national grid/power companies take no responsibility for such events and say they only guarantee the frequency of the mains power (50Hz) not the voltage!
The last entry in the old UPS log was an over voltage alert showing 1000v!
With a new UPS in place and online, we’ve already had a number of power cuts and it’s handled them well, lets hope we don’t get another big one!
Backups are now running again on external drives that are disconnected when not in use to protect them from power surges and all the services successfully migrated over to the replacement server.
This is more of an aide memoire for myself more than anything but, may be useful to anyone who is using a SHARI powered AllStarLink node.
Out the box the SHARI build as documented here and here uses node numbers in announcements when connecting/disconnecting. The information in this article will change this so that the announcements use the node callsigns instead of node numbers.
As user repeater, login to the RaspberryPi that the SHARI is connected too via SSH and make the following changes:
1: Using your favourite command line text editor, edit /usr/sbin/write-node-callsigns and change SRCDIR to point to /var/www/html/allmon2
# 28/08/24 - M0AWS - Changed path to point to allmon2
##SRCDIR=/var/www/html/allmon
SRCDIR=/var/www/html/allmon2
2: Copy the astb.txt file into the necessary directory:
Please note: This build is now deprecated and will no longer work. Please use the new AllStarLink 3 build process as documented on the AllStarLink website.
We’ve recently added a new room to the Matrix HAM Radio Space for Digital Voice modes as this was an area of interest that didn’t really fit into any of the other rooms.
The new Digital Voice room has attracted a lot of attention from members, with a lot of the focus being on the AllStarLink system. Michael, DK1MI built an AllStarLink node in the cloud for us all to use for Matrix Nets and so I decided I had to get in on the fun.
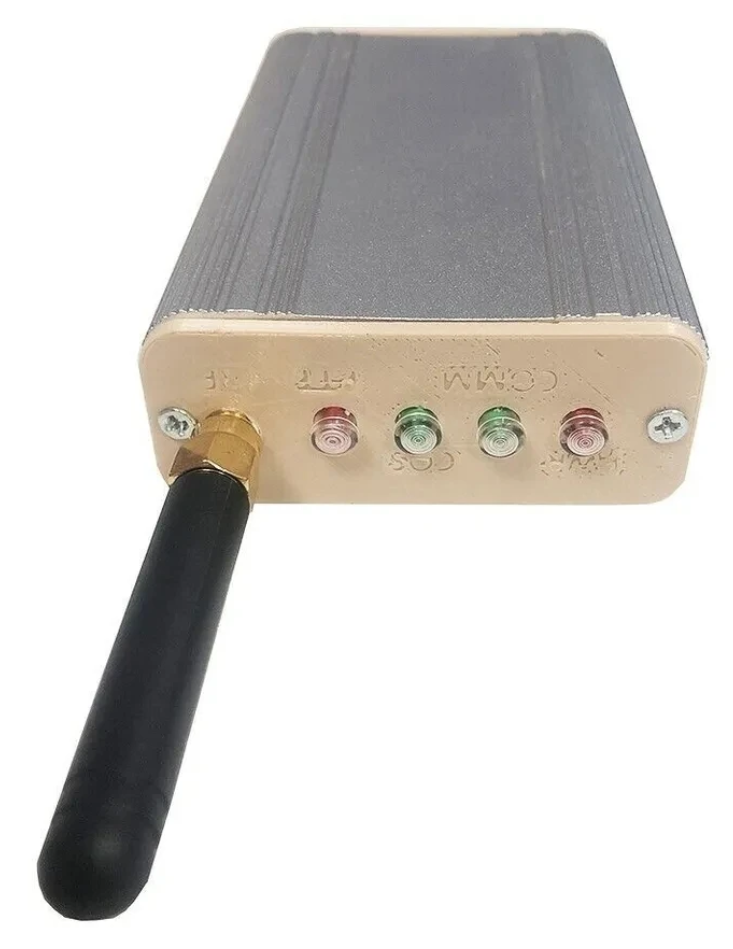
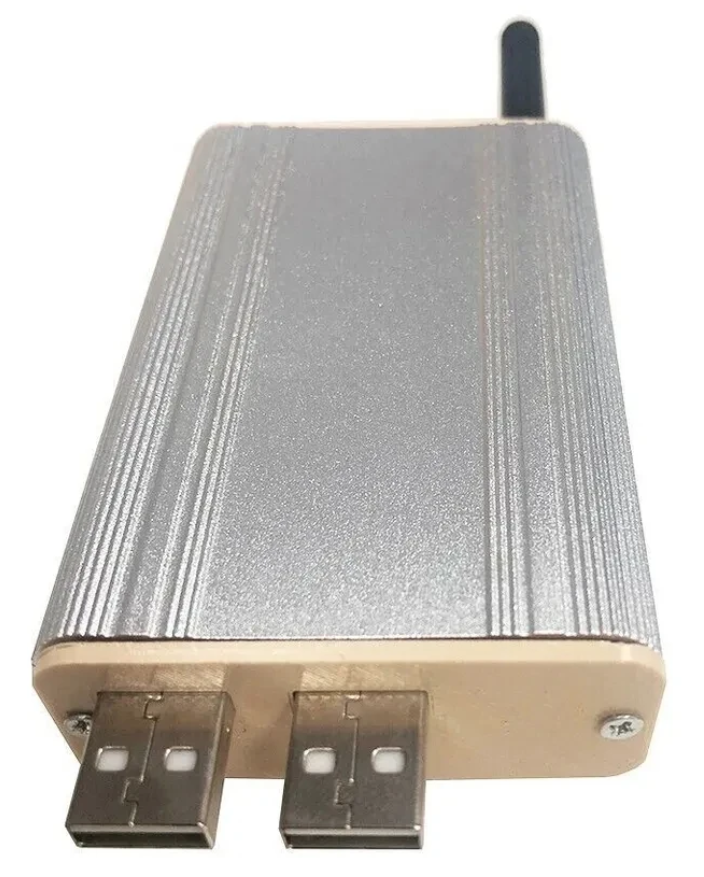
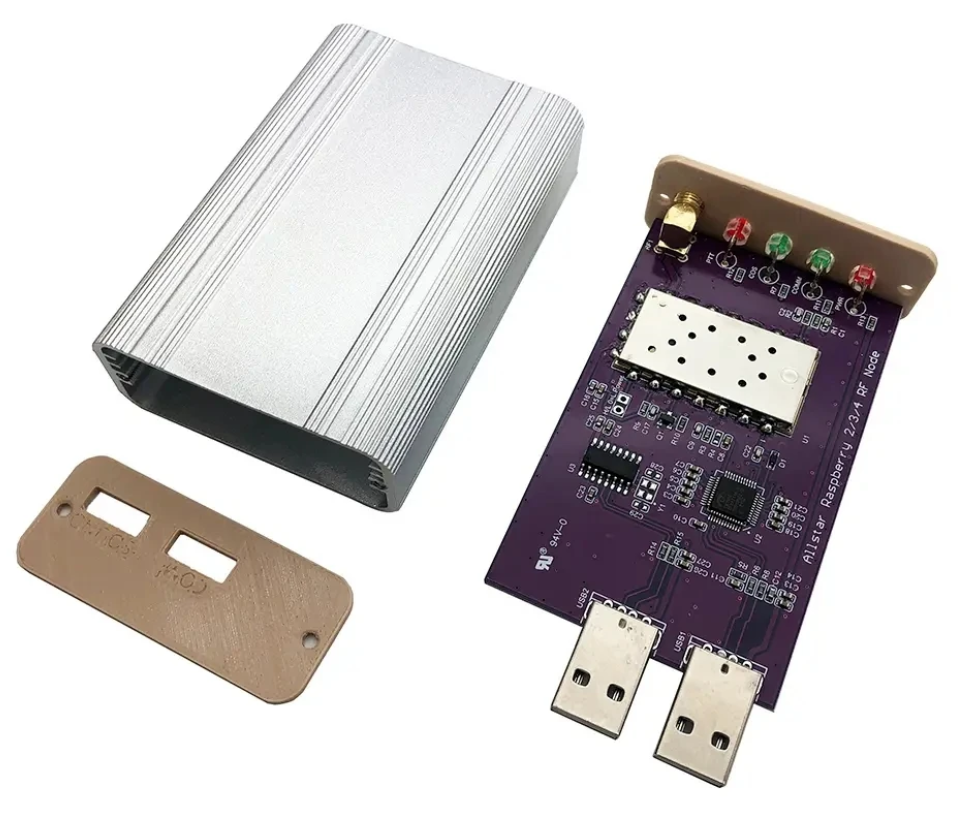
Jumbospot SHARI SA818 Amateur Radio AllStarLink Radio Interface Front Panel ViewJumbospot SHARI SA818 Amateur Radio AllStarLink Radio Interface Rear ViewJumbospot SHARI SA818 Amateur Radio AllStarLink Radio Interface stripped down View
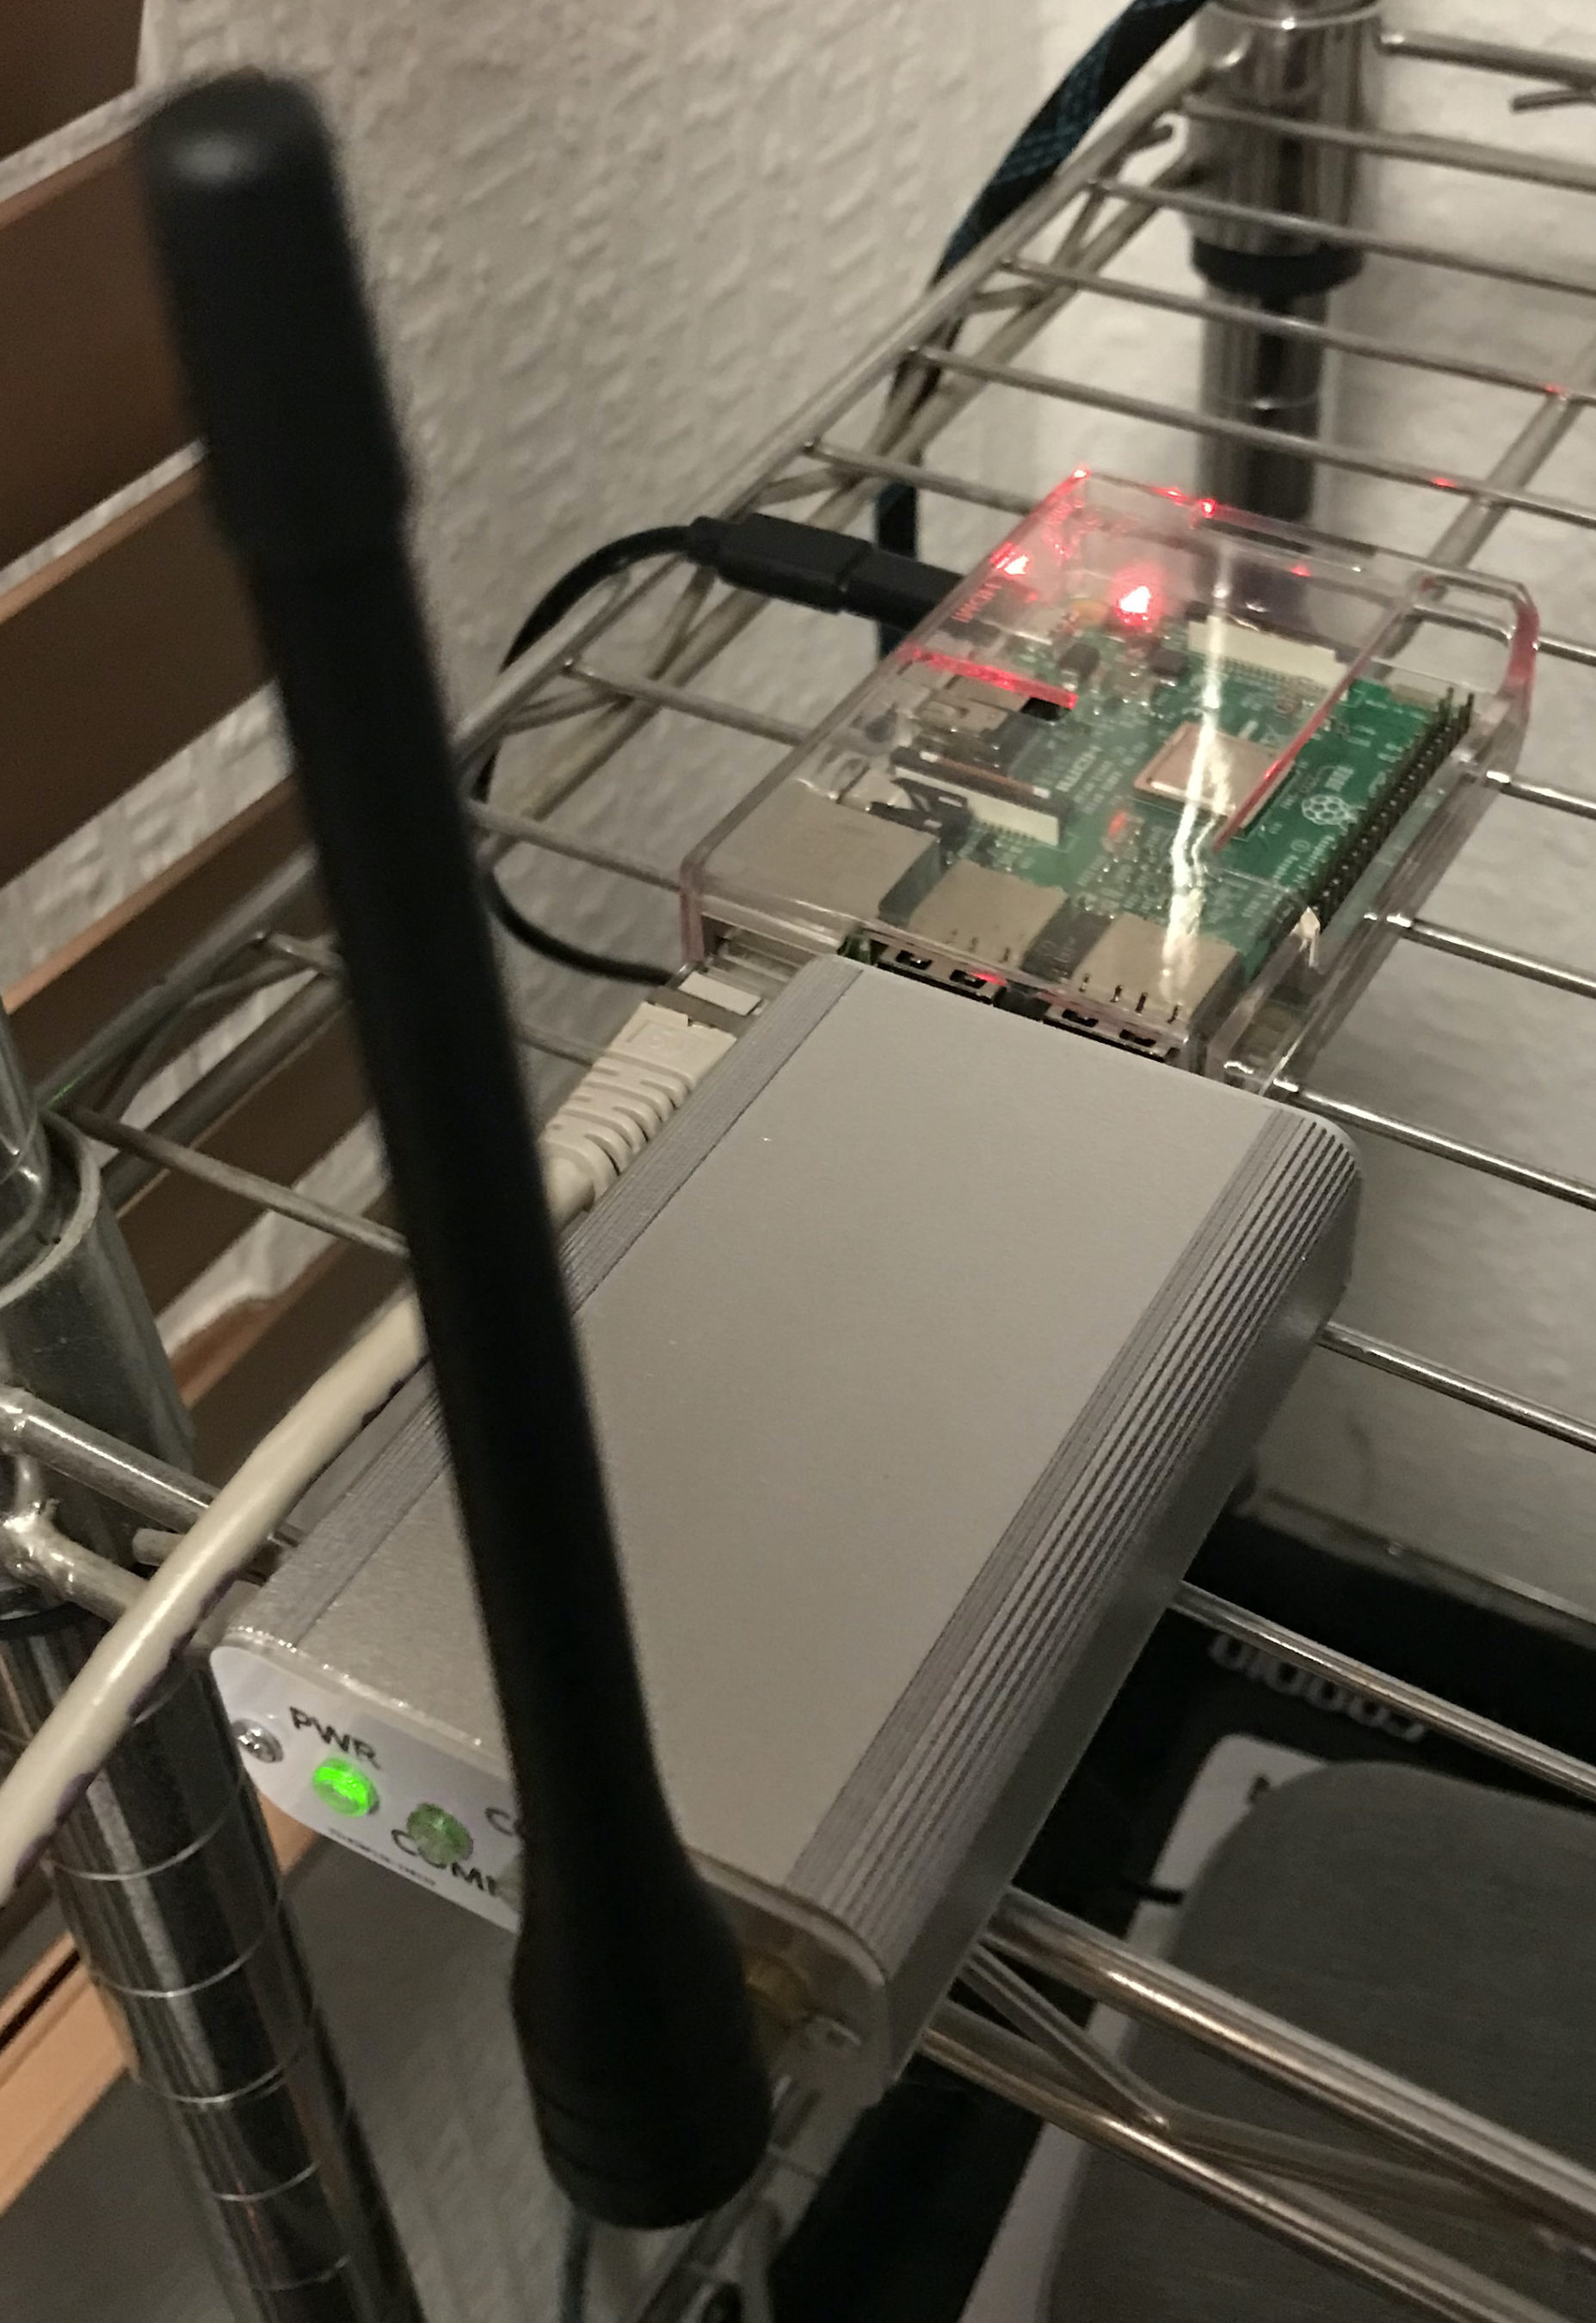
The two USB connectors on the SHARI device are position such that they plug into two of the available 4 USB ports on the RaspberryPi without the need for cables. This keeps the whole solution together in one neat package.
Before you start you will need to obtain a node number and secret (password) from the AllStarLink Portal. To get this you will need to provide proof to the AllStarLink administrators that you are a licensed Amateur Radio (HAM) operator. This is done by uploading a copy of the first page of your HAM licence to the website for the admin team to check. This can take 24hrs to be completed so make sure you get this all done before trying to build your node. You cannot build a node successfully without a node number and secret.
Of course you will also need a transceiver that can operate on the 438.800Mhz frequency or other frequency of your choice on the 2m or 70cm HAM band.
You will also need to open port 4569 on your internet router and setup port forwarding to the IP Address that you will be using on your RaspberryPi node. It’s important to use a static IP Address on your RaspberryPi.
There are quite a few different Linux based operating system (O/S) images that are available for the RaspberryPi devices that have been specifically tailored for the AllStarLink node and include all the necessary software and library packages out the box.
Once downloaded you need to burn the ISO image onto a suitable SD card for your RaspberryPi. I use BalenaEtcher as it’s extremely quick and reliable at burning ISO images to SD cards.
Of course if you are a hardline Linux command line junkie you can always use dd to create the SD card.
Once you’ve got your O/S onto your SD card, slot it into your RaspberryPi making sure your SHARI device is connected to the two USB ports and then power it up. Make sure you have a good PSU for the RaspberryPi as the two devices together draw around 3A of current during the transmit cycle. (I use a 3.6A PSU from Amazon).
The default login for the Raspbian O/S is shown below. Login via SSH and configure your RaspberryPi for your local network. It’s important to use a static IP Address configured either directly on the RaspberryPi or via DHCP in your router.
Next you need to change directory into the asterisk config file directory using the command shown below:
cd /etc/asterisk
In this directory you will find all the default config files that come as part of the distro. For this build we’re not going to use them and so we need to move them out of the way ready for a set of config files that have already been configured correctly.
Using the following commands create a new directory, move into that new directory and then move all the unwanted configuration files into it:
mkdir ORIGINAL-CONF-FILES
cd ./ORIGINAL-CONF-FILES
mv ../*.conf ./
ls -la
cd ../
You should now be back in the /etc/asterisk directory which will now be empty apart from the custom directory which we left in place.
You now need to copy the correctly configured configuration files into the /etc/asterisk directory. Start by downloading the zip file containing the new configuration files
Download removed as deprecated.
Once downloaded, copy the .zip file into the repeater users home directory (/home/repeater) using either scp on the Linux command line or if using Windows you can use the FileZilla Client in SFTP mode using the login details above.
Once you have the .zip file in the repeater user’s home directory you need to copy the file into the /etc/asterisk directory as user root:
Next as user root, change directory into the /etc/asterisk directory and unzip the .zip file:
cd /etc/asterisk
unzip ./AllStarLink-Config-v3.zip
Once the file is unzipped you will have a directory called AllStarLink-Config in the /etc/asterisk directory. You now need to cd into the directory, copy all the files out of it into the /etc/asterisk directory leaving a copy in the AllStarLink-Config directory for future reference:
cd /etc/asterisk/AllStarLink-Config
cp ./* /etc/asterisk
cd /etc/asterisk
You now need to move a couple of files into the repeater users home directory using the following commands:
The gpioBASH script and configuration details were supplied by Mark, G1INU in the Digital Voice room on the Matrix. It adds the COS light functionality to the setup. The COS light will now light every time the SA818 hears RF on the input.
The next thing you need to do is configure the SA818 radio device in the SHARI. The script I used was originally from https://wiki.fm-funknetz.de/doku.php?id=fm-funknetz:technik:shari-sa818 all I’ve done is change the entries to switch off CTCSS and change the frequency to 438.800Mhz. Configuring the SA818 is done by running the SA818-running.pyPython programme that you moved into the repeater user home directory. Making sure you are still user root, run the following commands:
cd /home/repeater
./SA818-running.py
At this point your SHARI SA818 device will be configured to operate on 438.800Mhz and CTCSS will be disabled.
If you want to change the frequency or enable and set a CTCSS tone to access the node you will need to edit the Python programme using your favourite text editor and change the entries accordingly. Once changed rerun the program as shown above and your SHARI will be reconfigured to your new settings.
Next you need to move the allmon.ini.php file into the correct directory so that it enables access to the Allstar Monitor web page on the device so that you can manage connecting/disconnecting nodes. Use the following commands as user root to achieve this:
The allmon.ini.php file needs to have your node name entered into it to work correctly. As user root, change directory and edit the file using your favourite editor.
cd /var/www/html/allmon2
Using your text editor, search for the line starting [XXXXX] and change the XXXXX to your node number. Save the change and exit the file.
At this point you are almost complete, all that is left to do is add your node number and node secret into the appropriate configuration files in the /etc/asterisk directory.
Since I am a Linux command line junkie I use vi to edit all the configuration files on the command line as user root, but you can use any editor of your choice.
cd /etc/asterisk
Start with the extensions.conf file. Search for the line starting with NODE = and delete the XXXXX entry and insert your node number. Save the file and exit it.
Next you need to edit the iax.conf file. This time search for the line starting with register= and change the XXXXX for your node number and the YYYYYYYYYYYY for your node secret. Be careful not to accidentally delete any other characters in the lines otherwise it will corrupt the configuration file.
In the same file search for the two lines that start with secret = and change the YYYYYYYYYYYY for your node secret. Once you have changed both of the secret entries, save and exit the file.
The final file to edit is the rpt.conf file. Once again open the file using your favourite editor and search for the line starting with XXXXX = radio@127.0.0.1:4569/XXXXX, change the XXXXX entries for your node number making sure not to delete any other characters next to the XXXXX entries.
Further down in the same file there is a line that starts with [XXXXX], once again change the XXXXX for your node number making sure to keep the square brackets at each end of the node number as you edit it.
Finally move down to the very bottom of the file and find the two lines that start with /home/repeater/gpio, once again change the XXXXX entries for your node number.
The final thing to change in the rpt.conf file is to replace my callsign with your own callsign so that the node identifies itself correctly. Scroll through the file until you find the two lines shown below, delete M0AWS and add your own callsign instead making sure you keep all the spaces between words as shown below.
idrecording = |i DE M0AWS
idtalkover = |i DE M0AWS
Once this is done, save and exit the file. At this point your node should be fully configured and will only require a reboot to get it working.
As user root, reboot your raspi using the reboot command.
reboot
Once your raspi comes back online, login using SSH as user repeater and then become root user using the sudo command detailed above.
You now need to create the admin user password for the Allstar Monitor web page on the device. This is done using the following commands as user root:
cd /var/www/html/allmon2
htpasswd -c .htpasswd admin
You will be asked to enter a password twice for the admin user. Make sure you make a note of this user/password as you will need it to login to the web page.
Finally check that the controlpanel.ini.php file is in the /var/www/html/allmon2 directory:
ls -la /var/www/html/allmon2/controlpanel.ini.php
If the file isn’t shown in the directory, enter the following commands to create the file in the correct place as user root and then exit the SSH session:
cd /var/www/html/allmon2
cp ./controlpanel.ini.txt ./controlpanel.ini.php
cd
exit
Once this is done your configuration is complete, logout from the terminal session by entering exit once more and your SSH session will terminate.
Using your favourite web browser enter the IP Address of your raspi into the URL bar as shown below:
http://<Your-Raspi-IP>/allmon2
Note: remove the <> from the URL once you have entered the required information.
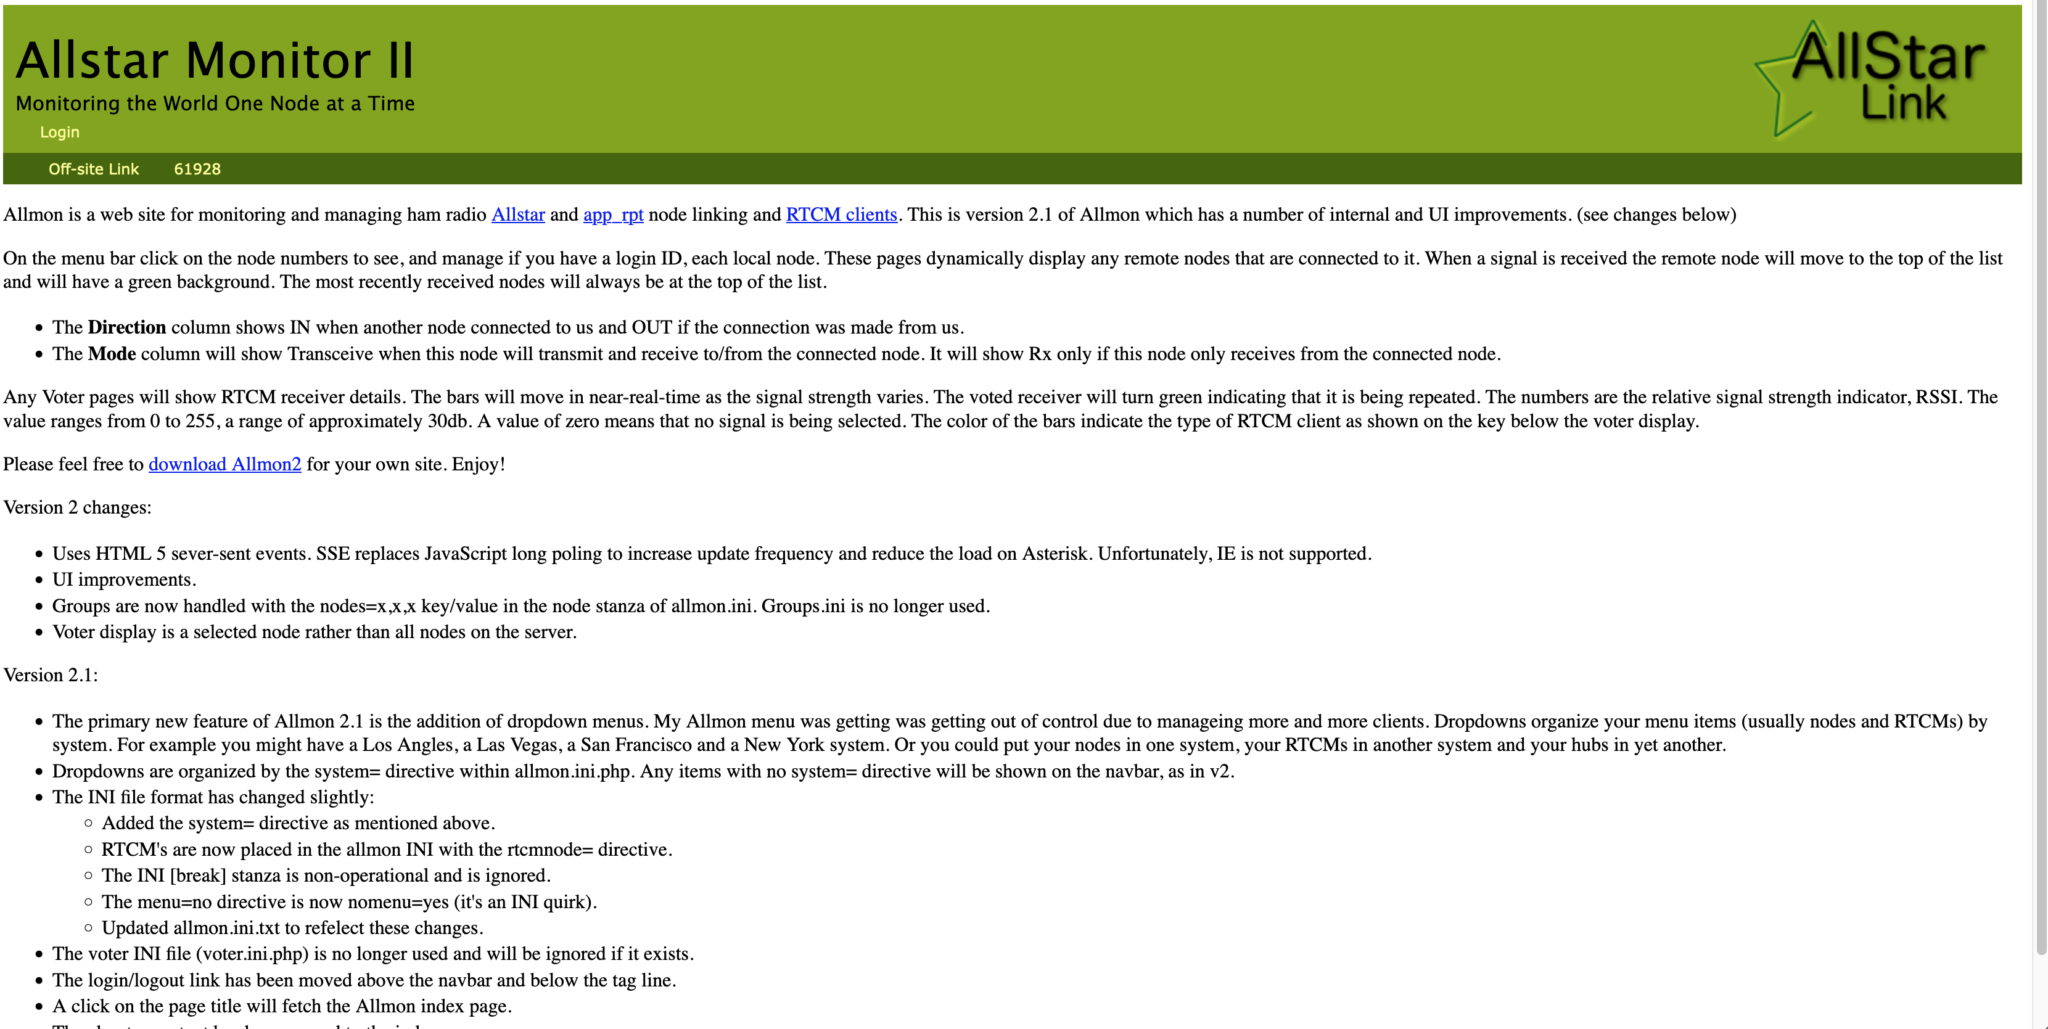
Once this is done you should be presented with your node control panel as shown below.
First visit to the AllStar Monitor Web Page
Login using Admin and the password you set above and you are now ready to start using your node.
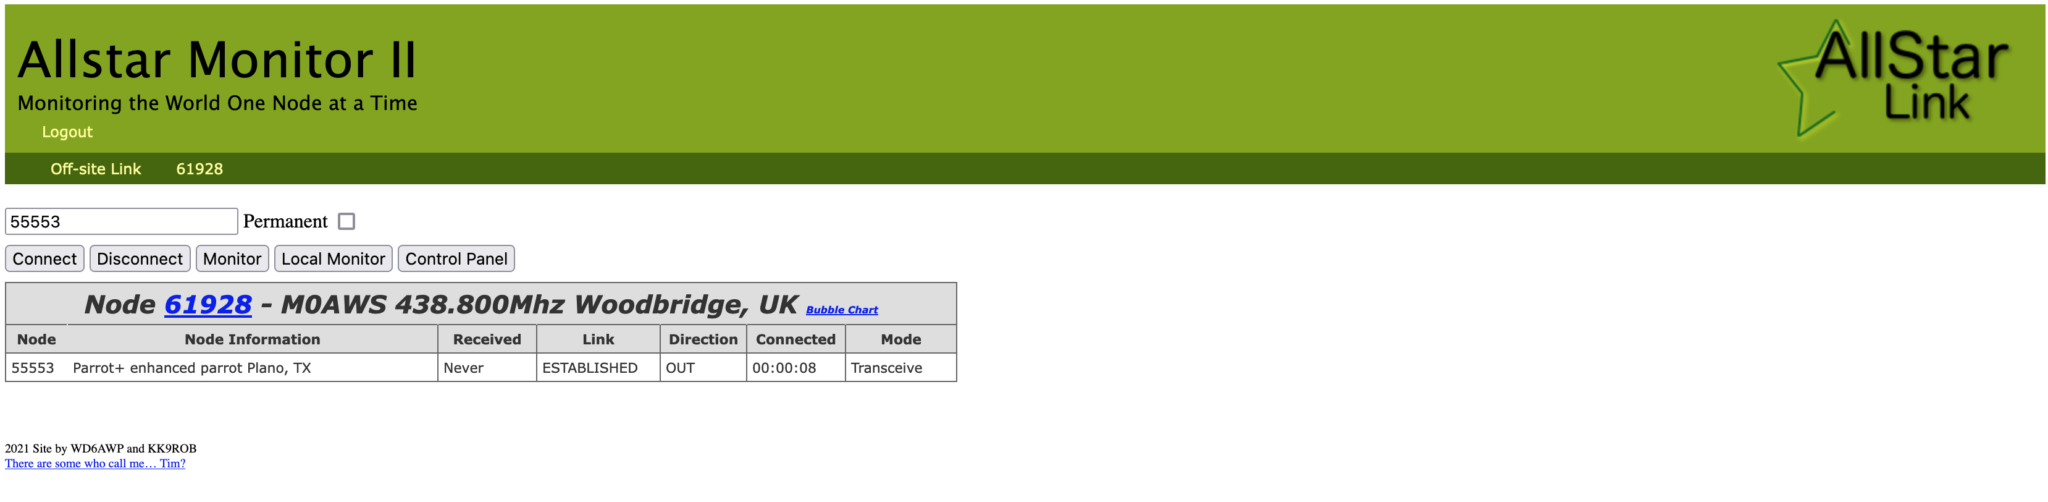
It’s a good idea to connect to node 55553 which is a parrot test node to check your audio levels. You can do this by entering the node into the field at the top left and pressing the connect button.
M0AWS AllStarLink Node 61928 connected to 55553 Parrot
Once connected, tune your radio to 438.800Mhz FM and transmit a test message using your callsign and test123, or something similar. The parrot will then play your recording back to you so that you can hear how you sound. It will also comment on your audio level as to whether it is OK or not.
You are now connected to AllStarLink network and have the world at your finger tips. Below is a small list of nodes in the UK, Australia and America to get you started chatting with other HAMs via your node.
57881	Matrix HAM Radio Space AllStarLink Node (Hosted by Dk1MI)
55553	ASL Parrot for testing
41522	M0HOY HUBNet Manchester, UK
60349	VK6CIA 439.275 Perth, Western Australia
51077	VK6SEG South West Hub B Albany WA
2167	M0JKT FreeSTAR UK HUB 2 freestar.network
53573	NWAG NW AllStar Group Lancashire, UK
27339	East Coast Hub Wilmington NC USA
M0AWS AllStarLink Node 61928 sitting on the equipment rack
Thanks to Michael, DK1MI for building and hosting the Matrix HAM Radio Space AllStarLink Node (57881) and getting us all started in the world of AllStarLink!
We hope to be having regular Matrix Net’s on the node soon for all Matrix members and visitors. We’ll organise days/times via the Digital Voice room.
More soon …
We use cookies to ensure that we give you the best experience on our website. If you continue to use this site we will assume that you are happy with it.